Supply-demand matching for vertiport location and capacity allocation optimization in urban low-altitude logistics: A case study of Nanjing

*Correspondence to:
Zhao Xu, School of Civil Engineering, Southeast University, Nanjing 211189, Jiangsu, China.
E-mail: xuzhao@seu.edu.cn
J Build Des Environ. 2026;4:202622. 10.70401/jbde.2026.0042
Received: May 13, 2026Accepted: August 06, 2026Published: August 06, 2026
Abstract
The rapid development of the low-altitude economy has positioned vertiports as critical heavy-asset hubs in urban logistics networks, where siting decisions affect both delivery access and facility utilization. Existing maximum-coverage models do not explicitly represent station throughput or allocated order volumes. This study therefore retains the original three-stage framework-demand assessment, hierarchical facility polygon intersection point set (HFPIPS) candidate generation, and capacitated location-allocation, while correcting the demand surface to use area-weighted land-use shares and clarifying that the utilization floor is an application-specific minimum-throughput rule rather than a new algebraic form. In Nanjing, 8,811 demand grids and 10,283 planning candidates produce 2,678,898 radius-feasible pairs, reduced to 374,873 pairs by demand-adaptive pruning. Under a 300 s single-thread budget, the high-coverage capacitated facility location problem (CFLP) returns a verified feasible incumbent of 195 stations delivering 156,300 orders/day (78.13%), with 66.79% average utilization, 22.50% minimum utilization, and 0.953 km average delivery distance. At the same 195-site budget, a deterministic maximal covering location problem (MCLP)-greedy baseline achieves 97.05% nominal geometric coverage but only 63.87% capacity-feasible delivery. Removing the utilization floor delivers only 29 additional orders while opening four extra sites and permitting utilization as low as 1.58%. Land-use coefficient contrast tests change delivery by less than 0.27 percentage points and preserve the selected station set. The results support capacity-aware planning, while building-level engineering data, heterogeneous fleets, temporal demand, and unresolved solver gaps remain limitations.
Keywords
Vertiport location, capacitated facility location problem, urban low-altitude logistics
1. Introduction
The low-altitude economy-encompassing unmanned aerial vehicle (UAV) delivery, urban air mobility, and associated infrastructure, has emerged as a strategically important sector in numerous national development agendas. China’s 2024 Government Work Report identified the low-altitude economy as a new growth engine. Comparable policy and regulatory-development initiatives include the Federal Aviation Administration (FAA)’s Innovate 28 implementation plan, the European Commission’s Drone Strategy 2.0, Civil Aviation Authority of Singapore (CAAS)-led reference materials for advanced air mobility (AAM) regulation in the Asia-Pacific region, and Korea’s Korea urban air mobility (K-UAM) Grand Challenge[1-5]. Against this backdrop, the rational planning of vertiport networks has become a pressing practical and academic challenge.
Vertiports serve as the heavy-asset operational hubs of low-altitude logistics networks, enabling centralized drone parking, automated dispatching, battery swapping, and cargo loading. Unlike lightweight last-mile drop points, vertiports require aircraft-specific landing-area dimensions, adequate load-bearing surfaces, and obstacle-free take-off and landing environments; they may be located at ground level or on elevated structures when applicable design and safety criteria are satisfied[6,7]. These requirements make vertiport investments capital-intensive and location-sensitive: a well-placed network maximizes service coverage under constrained resources, while poor siting creates dual waste, capacity bottlenecks in high-demand urban cores and asset idleness in low-demand peripheries[8,9].
The academic literature on vertiport and UAV hub siting can be organized along three dimensions: coverage modeling, capacity modeling, and computational scalability. The dominant paradigm remains the maximum coverage location problem (MCLP), originally formulated by Church and ReVelle[10], which seeks to cover as many demand points as possible with a limited number of facilities. MCLP has been widely applied to emergency services, logistics hubs, and public infrastructure and has also informed recent vertiport-siting research. Xue et al.[11] proposed a hierarchical UAV landing-site selection model using MCLP for low-altitude logistics; Yang and Li[12] extended MCLP with spatially continuous demand surfaces; Kim et al.[13] instead formulated a quadratic programming model with decision-dependent probabilistic demand for air-taxi vertiports in Seoul. Although their formulations differ, these studies focus primarily on coverage or demand capture and do not model continuous order allocation under explicit physical throughput constraints at each facility. More recent work also considers learning-based siting[14], hierarchical capacity[15], UAV traffic allocation[16], and integrated location-route planning[17].
This capacity-blind assumption becomes untenable in metropolitan low-altitude logistics networks. A single high-density commercial grid may generate hundreds of daily delivery orders, yet MCLP treats it identically to a low-demand suburban grid as long as both fall within a station’s coverage radius. Consequently, MCLP cannot capture single-station capacity bottlenecks in high-demand areas, nor can it prevent opening stations in low-demand zones that would never reach economically viable throughput[10,18]. Kitthamkesorn and Chen[18] recognized this limitation and proposed a maximum capture formulation for UAM network design, but their model still lacks explicit per-facility capacity constraints and demand allocation mechanisms. Meanwhile, studies that do consider capacity, such as Zhang et al.[9], who addressed layout planning for logistics UAV landing sites, and Liu et al.[14], who used deep reinforcement learning for facility siting, have been limited to small-scale synthetic instances or single-objective formulations that do not jointly optimize location and allocation decisions.
The capacitated facility location problem (CFLP) overcomes these limitations by introducing throughput ceilings and allocation variables, enabling simultaneous optimization of site selection and demand-to-station assignment. CFLP has a long history in operations research. Representative capacitated facility-location variants have been applied to production-warehouse distribution network design, hierarchical healthcare planning, and last-mile telecommunications network design[19-21]. However, its application to vertiport siting remains largely unexplored. For capital-intensive vertiports, a complementary planning requirement is an explicit utilization floor: while throughput ceilings prevent overloading, no mechanism prevents the model from opening stations with negligibly low utilization, a particularly wasteful outcome for capital-intensive vertiport facilities. Furthermore, when applied to metropolitan-scale networks, CFLP faces a severe computational challenge: the feasible service pair set |ε| can reach hundreds of thousands, causing variable space to grow at O(|I||J|) and rendering direct mixed-integer linear programming (MILP) formulation intractable within practical time limits[9,14,15]. Prior dimensionality reduction approaches, such as uniform K-nearest neighbor truncation or random sampling, do not account for the spatial heterogeneity of demand, leading to suboptimal compression in high-demand zones where candidate diversity is critical.
Recent studies have broadened the field toward multi-objective cargo vertiports with land, safety, noise, and capacity criteria[22], joint landing-site and route planning[23], multimodal siting[13], and obstacle-aware real-path layouts[24]. The remaining gap addressed here is narrower: metropolitan parcel demand is linked to explicit station throughput, continuous allocation, a minimum viable-use rule, and reproducible demand-adaptive pruning.
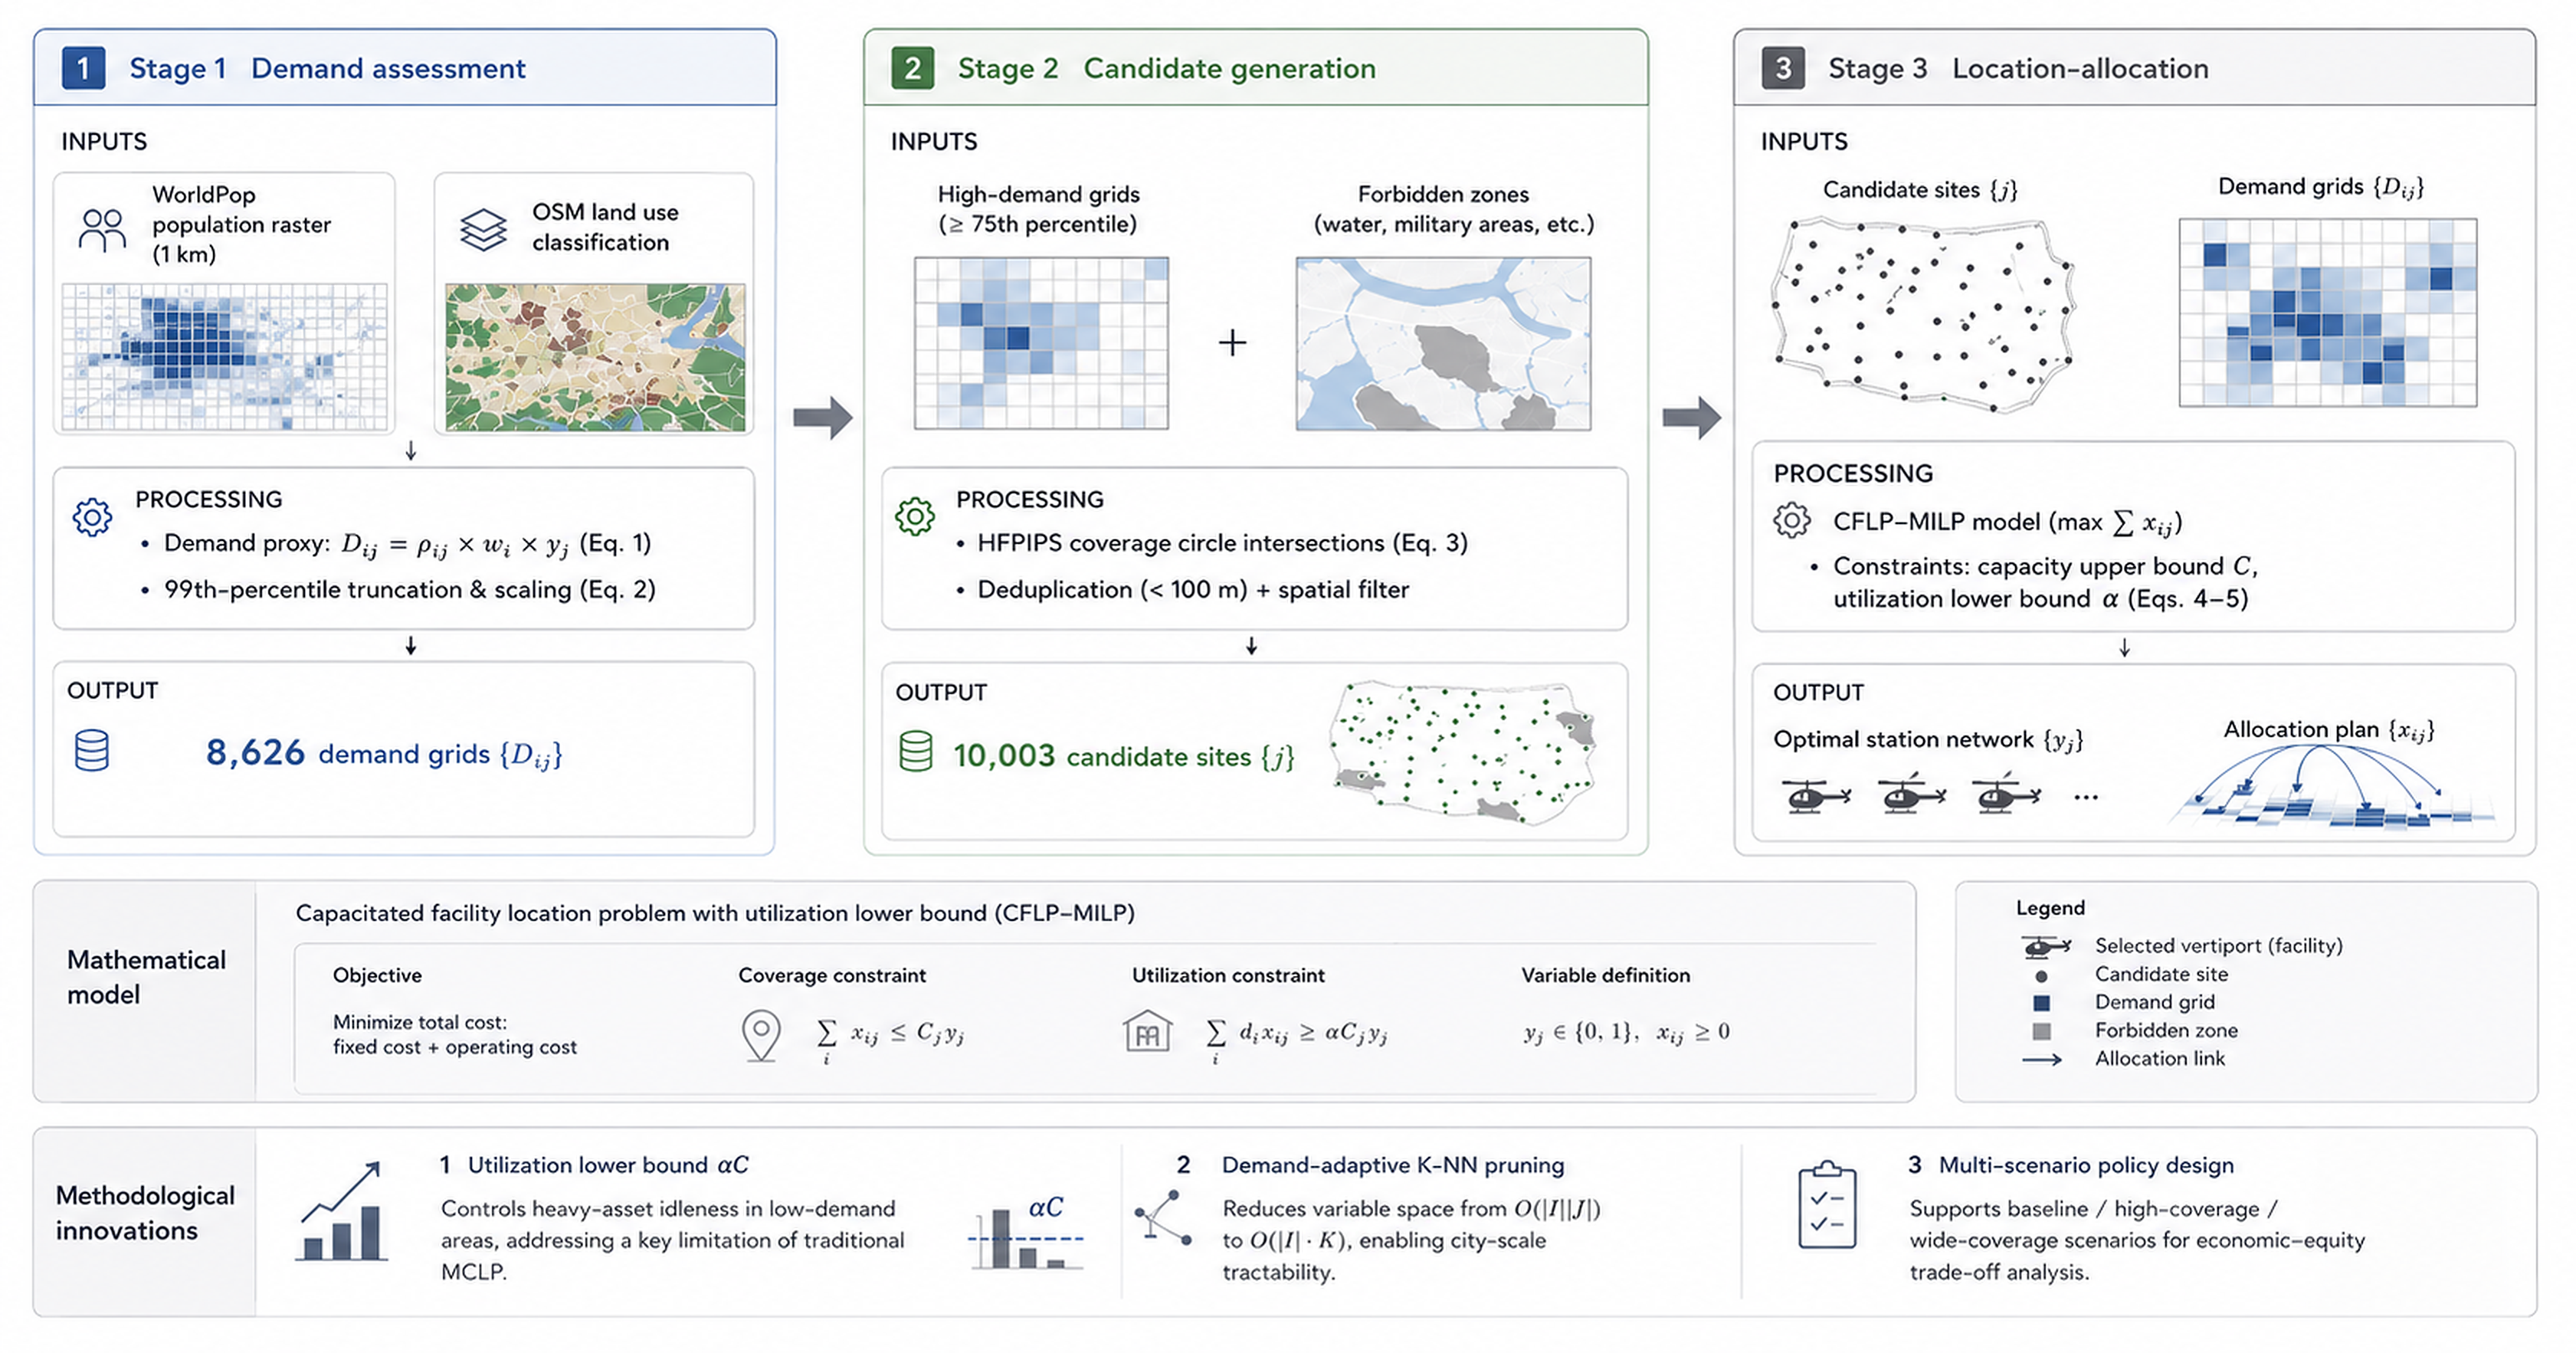
To address these twin challenges, this study makes three principal contributions. First, a complete three-stage collaborative optimization framework is proposed (Figure 1): (1) a multi-source spatial data fusion method that discretizes demand into 1 km × 1 km grids; (2) the hierarchical facility polygon intersection point set (HFPIPS) candidate generation method; and (3) a CFLP-MILP model incorporating both throughput ceilings and utilization floor constraints, used here as an application-specific minimum-throughput rule. Second, a deterministic demand-adaptive spatial reduction heuristic is developed, differentiating the neighbor truncation threshold by local demand intensity to compress variable space from O(|I||J|) to O(|I|·K), enabling city-scale tractability. Third, an empirical study using Nanjing compares multiple policy scenarios to illuminate the quantitative trade-off between corporate economic efficiency and governmental spatial equity in low-altitude logistics infrastructure planning.
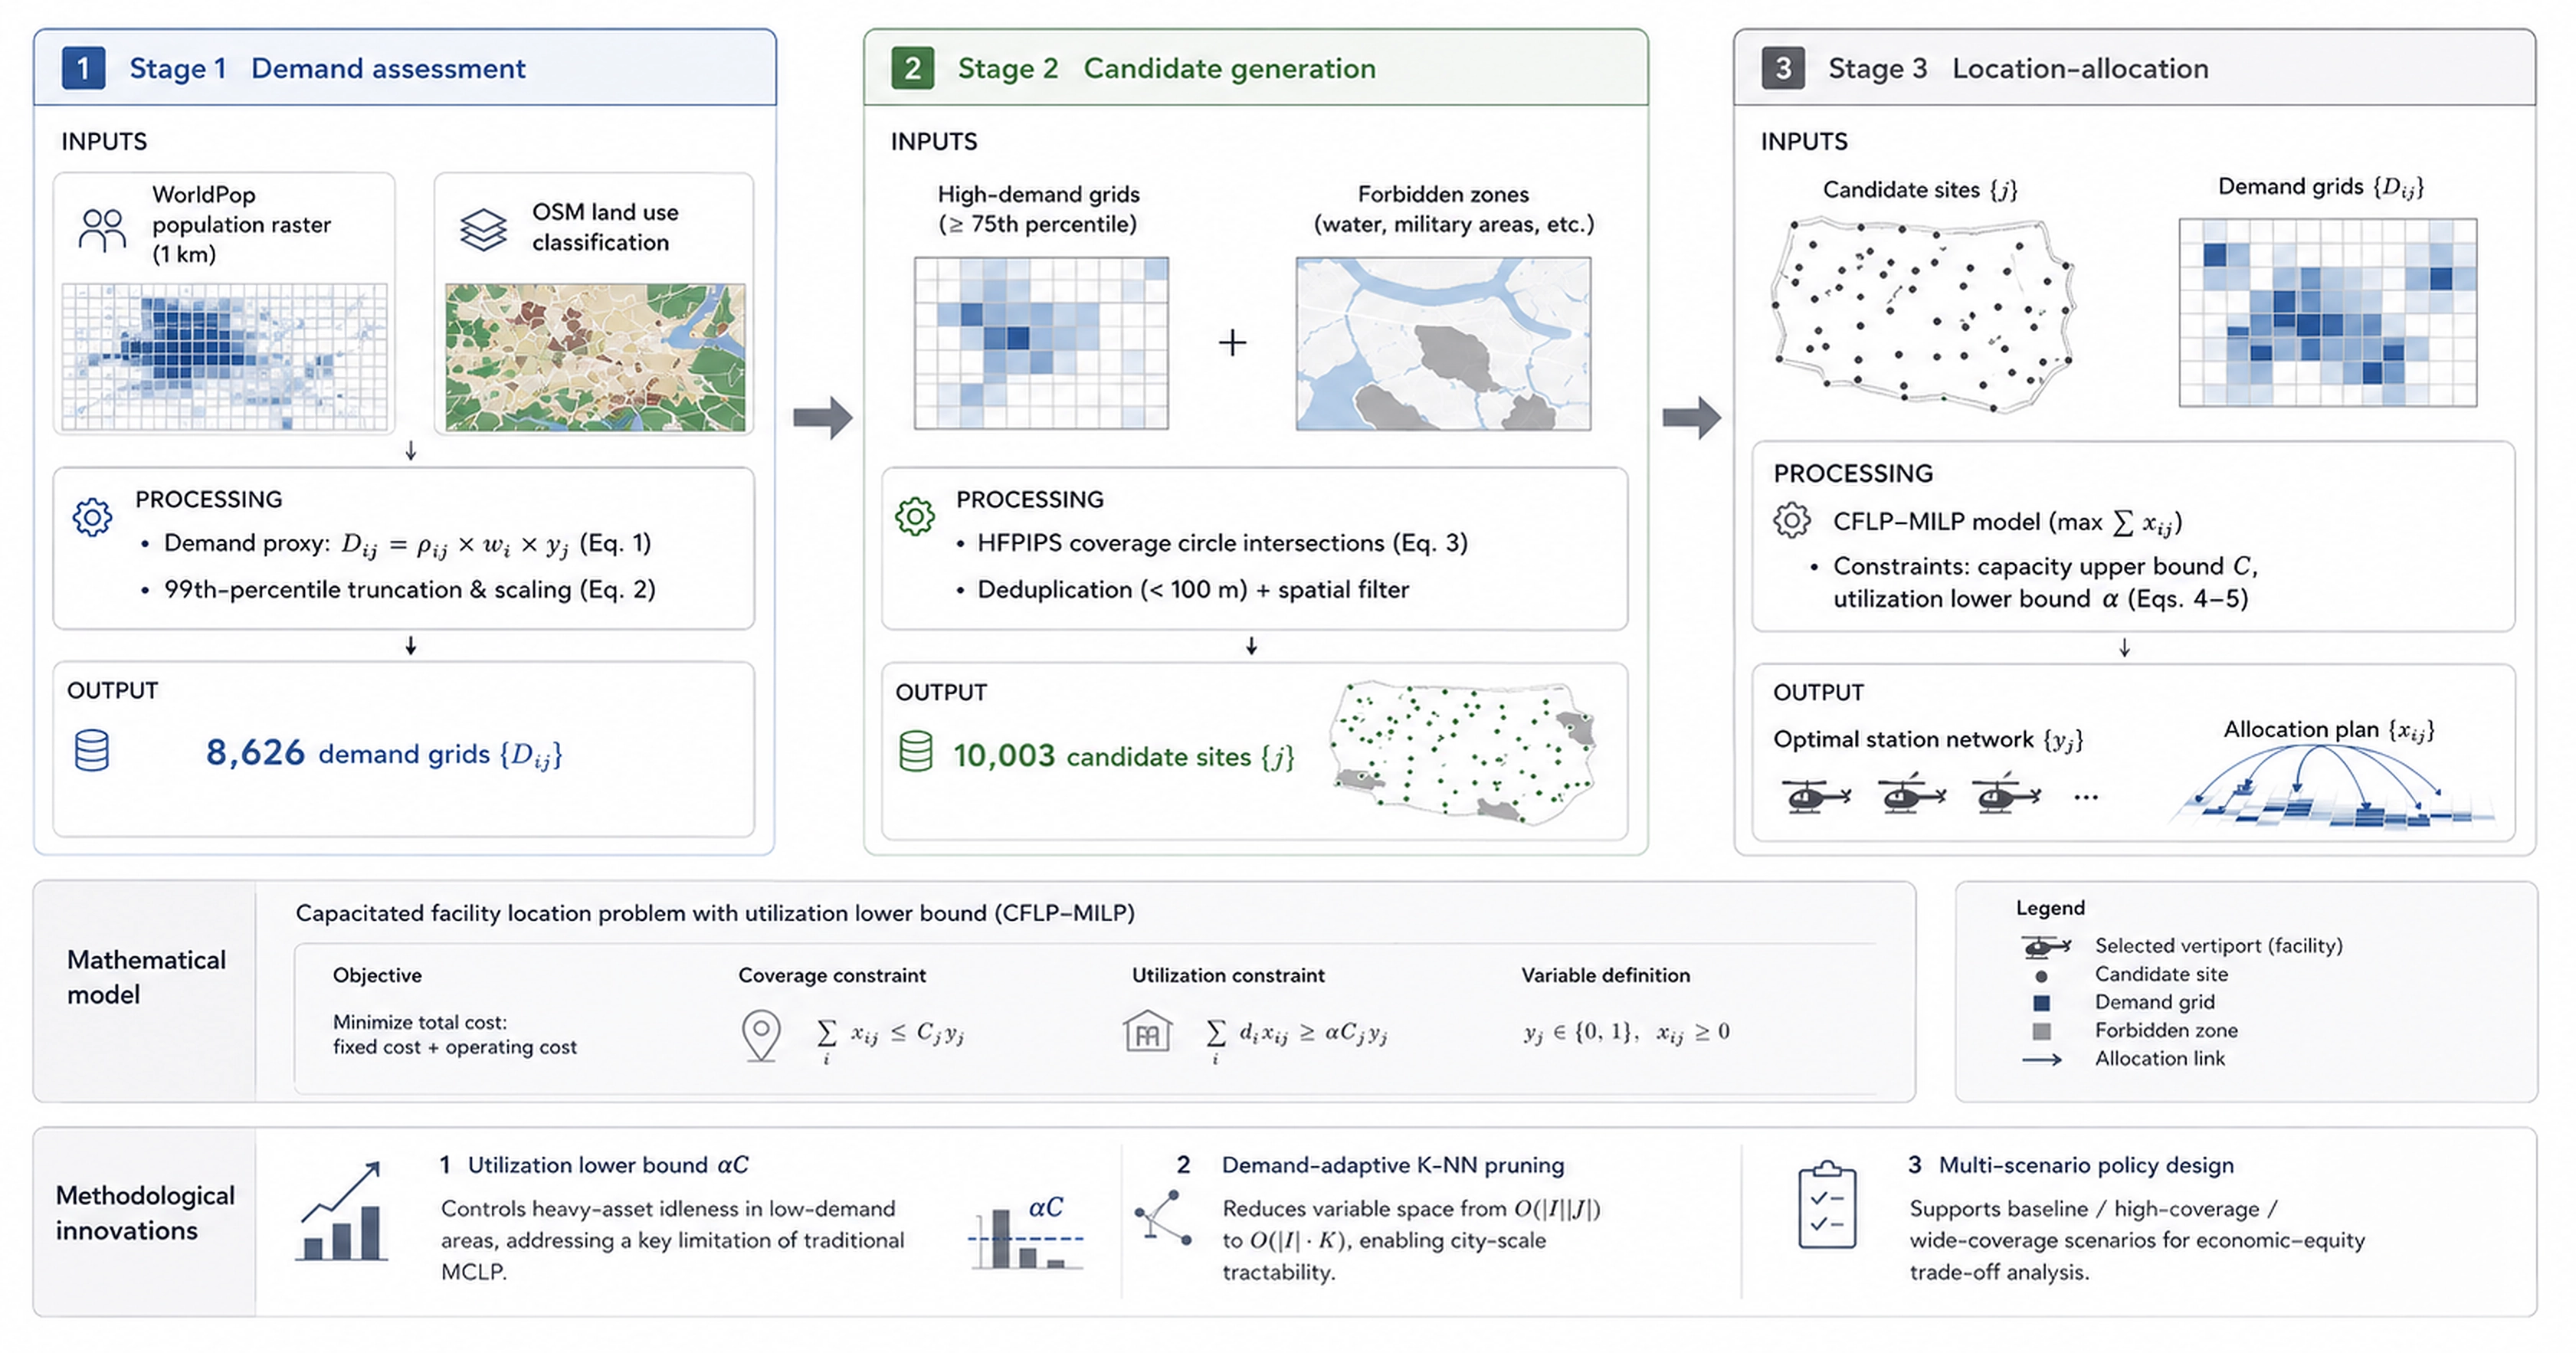
Figure 1. Three-stage collaborative optimization framework for urban low-altitude logistics vertiport siting. OSM: OpenStreetMap; HFPIPS: hierarchical facility polygon intersection point set; CFLP: capacitated facility location problem; MILP: mixed-integer linear programming; MCLP: maximum coverage location problem; K-NN: K-nearest neighbor.
2. Methods
2.1 Spatial demand assessment using multi-source data fusion
2.1.1 Demand proxy model
Low-altitude logistics demand is strongly correlated with population distribution and land use patterns, yet it is difficult to observe directly at the pre-commercial stage. This study employs a spatial discretization method based on multi-source data fusion, converting demand into quantifiable indicators at a 1 km × 1 km grid resolution. The underlying assumptions are: (a) demand is proportional to population density; (b) different land use types exert different demand intensities, commercial and residential zones are high-demand, greenspace and farmland low-demand, and water bodies and military zones generate negligible demand; (c) at the grid scale, population density and land use coefficients can be approximated as multiplicative. The demand proxy formula is:
where Dij is the low-altitude logistics demand for grid (i, j), ρij is WorldPop population density, gamma is the common conversion factor, and the grid land-use coefficient is the mean of a 10 × 10 subcell raster. Each subcell is assigned its overlap-resolved land-use coefficient, and the 100 coefficients are averaged. Unmapped subcells retain the neutral value 1.0. This area-weighted rule replaces the former grid-level maximum and allows water, green space, farmland, and other low-intensity uses to reduce demand in proportion to their occupied area.
2.1.2 Land use demand coefficients
The coefficient ωl represents an ordinal planning prior for each land-use type rather than an empirically estimated elasticity (Table 1). Administrative boundaries and land-use polygons are obtained from OpenStreetMap through Overpass/OpenStreetMap NetworkX (OSMnx), and population density is obtained from WorldPop. Land-use polygons are rasterized to 10 × 10 subcells inside each 1 km grid before area averaging. Because observed Nanjing UAV order data are not available, Section 3.6 reports structured coefficient-contrast tests instead of claiming unique statistical calibration.
Table 1. Land use demand coefficients.
| Land Use Type | Coefficient | Rationale |
| Commercial | 1.4 | Dense retail, F & B, and office |
| Residential | 1.2 | Primary destination for home delivery |
| Industrial | 0.9 | Predominantly B2B, some last-mile |
| Road/Transport | 0.8 | Roadside commerce and transport nodes |
| Green/Park | 0.5-0.6 | Low recreational delivery demand |
| Farmland/Forest | 0.35-0.4 | Sparse population, weak demand |
| Water/Reservoir | 0 | No delivery scenario |
| Military | 0.2 | Restricted zone, minimal demand |
B2B: business-to-business.
2.1.3 Robust demand processing and scaling
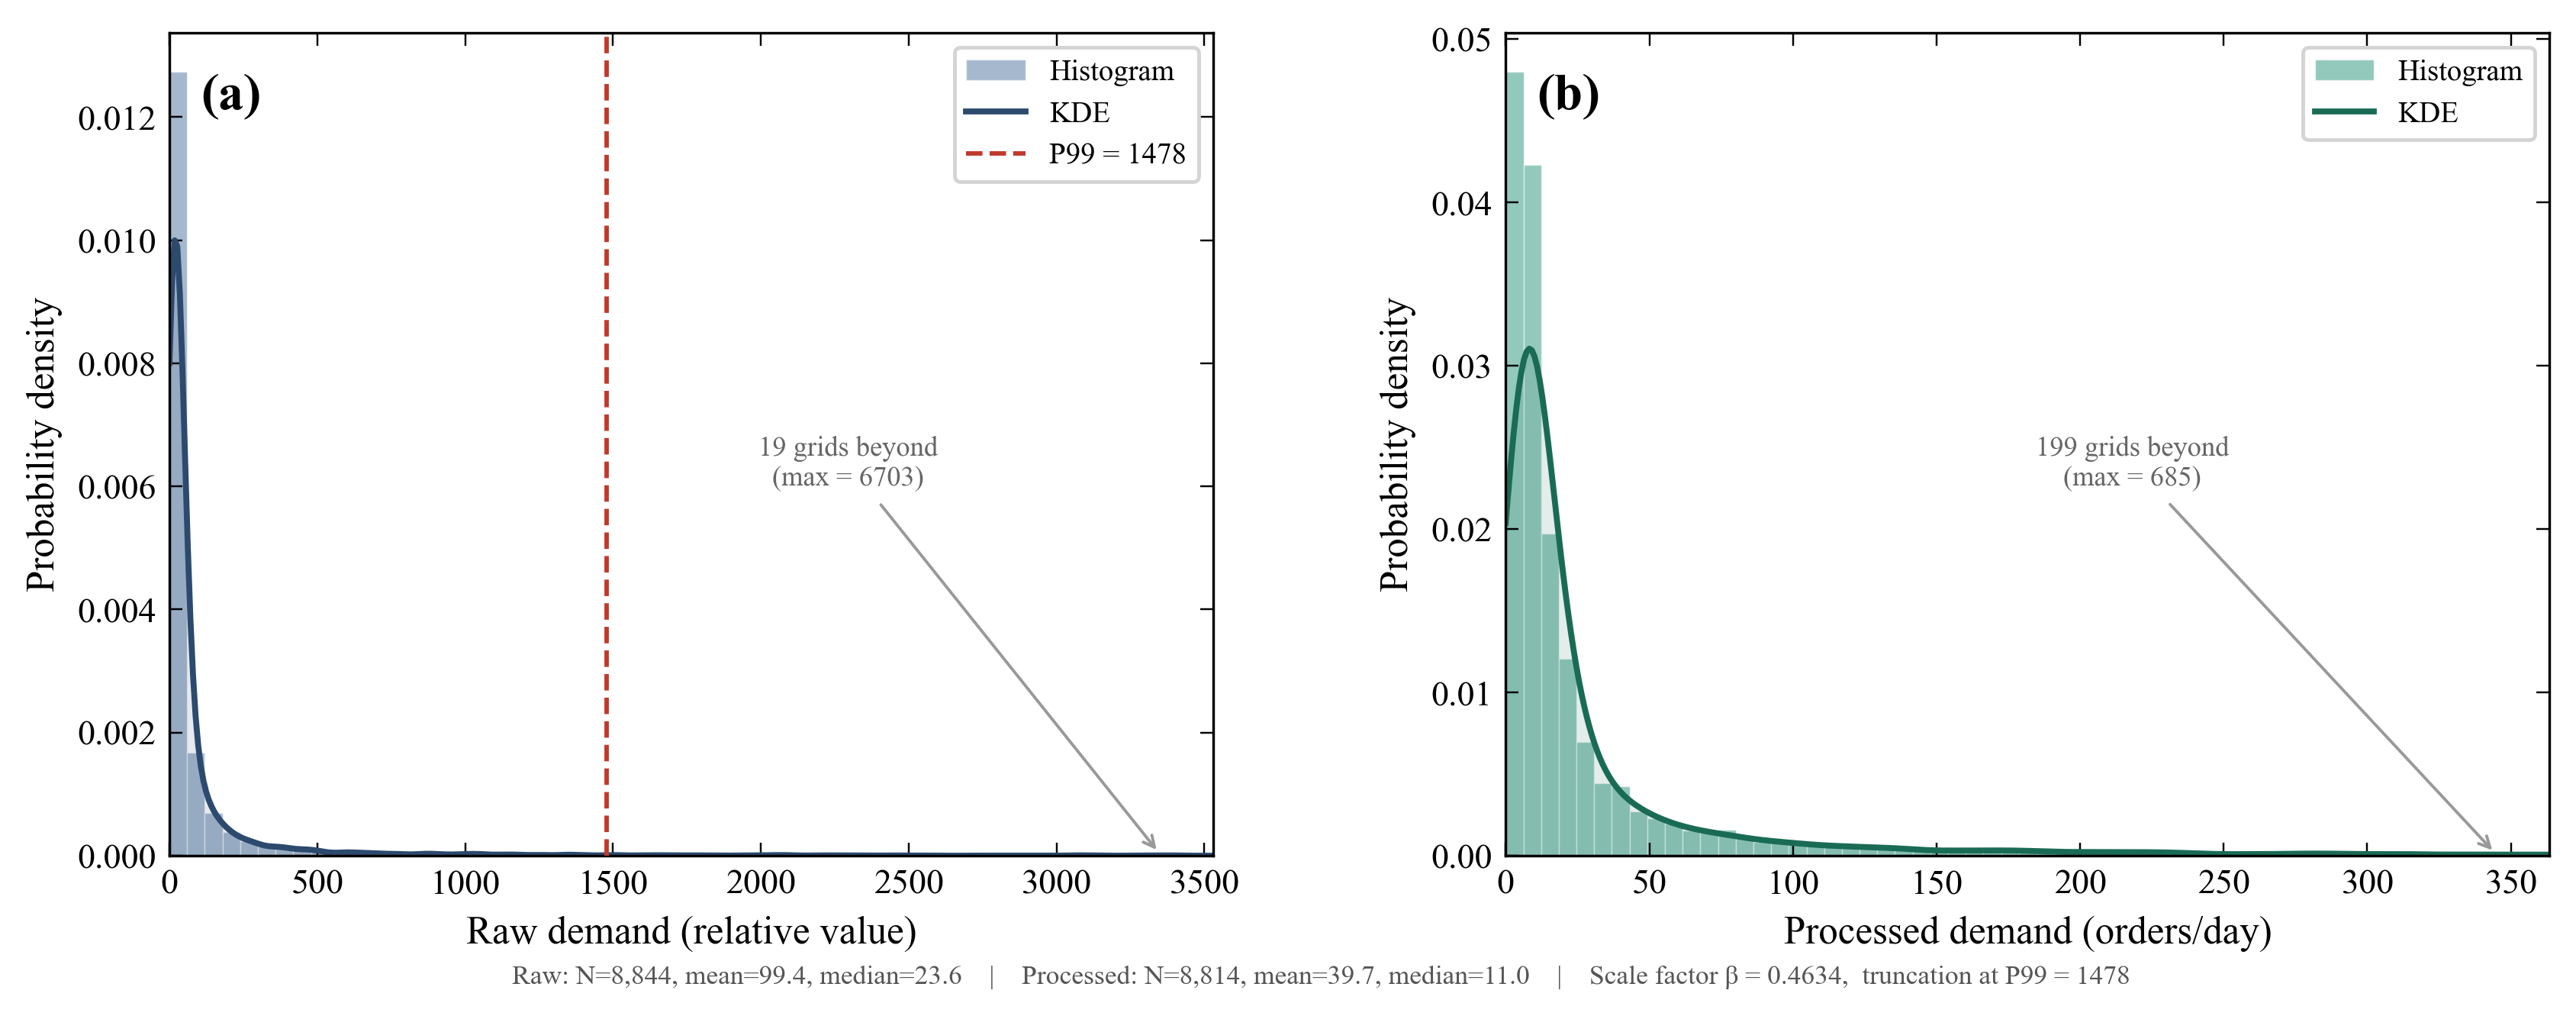
Raw demand values exhibit a right-skewed distribution: a small number of high-density commercial grids carry disproportionately large values. Direct linear scaling to a target aggregate would concentrate limited capacity excessively in a handful of grids. A 99th-percentile truncation procedure is therefore applied before scaling:
where β is the scaling factor. This procedure preserves the spatial distribution structure while adjusting only the aggregate magnitude, suppressing the Matthew effect of extreme values. Figure 2 illustrates the distributional shift before and after processing.
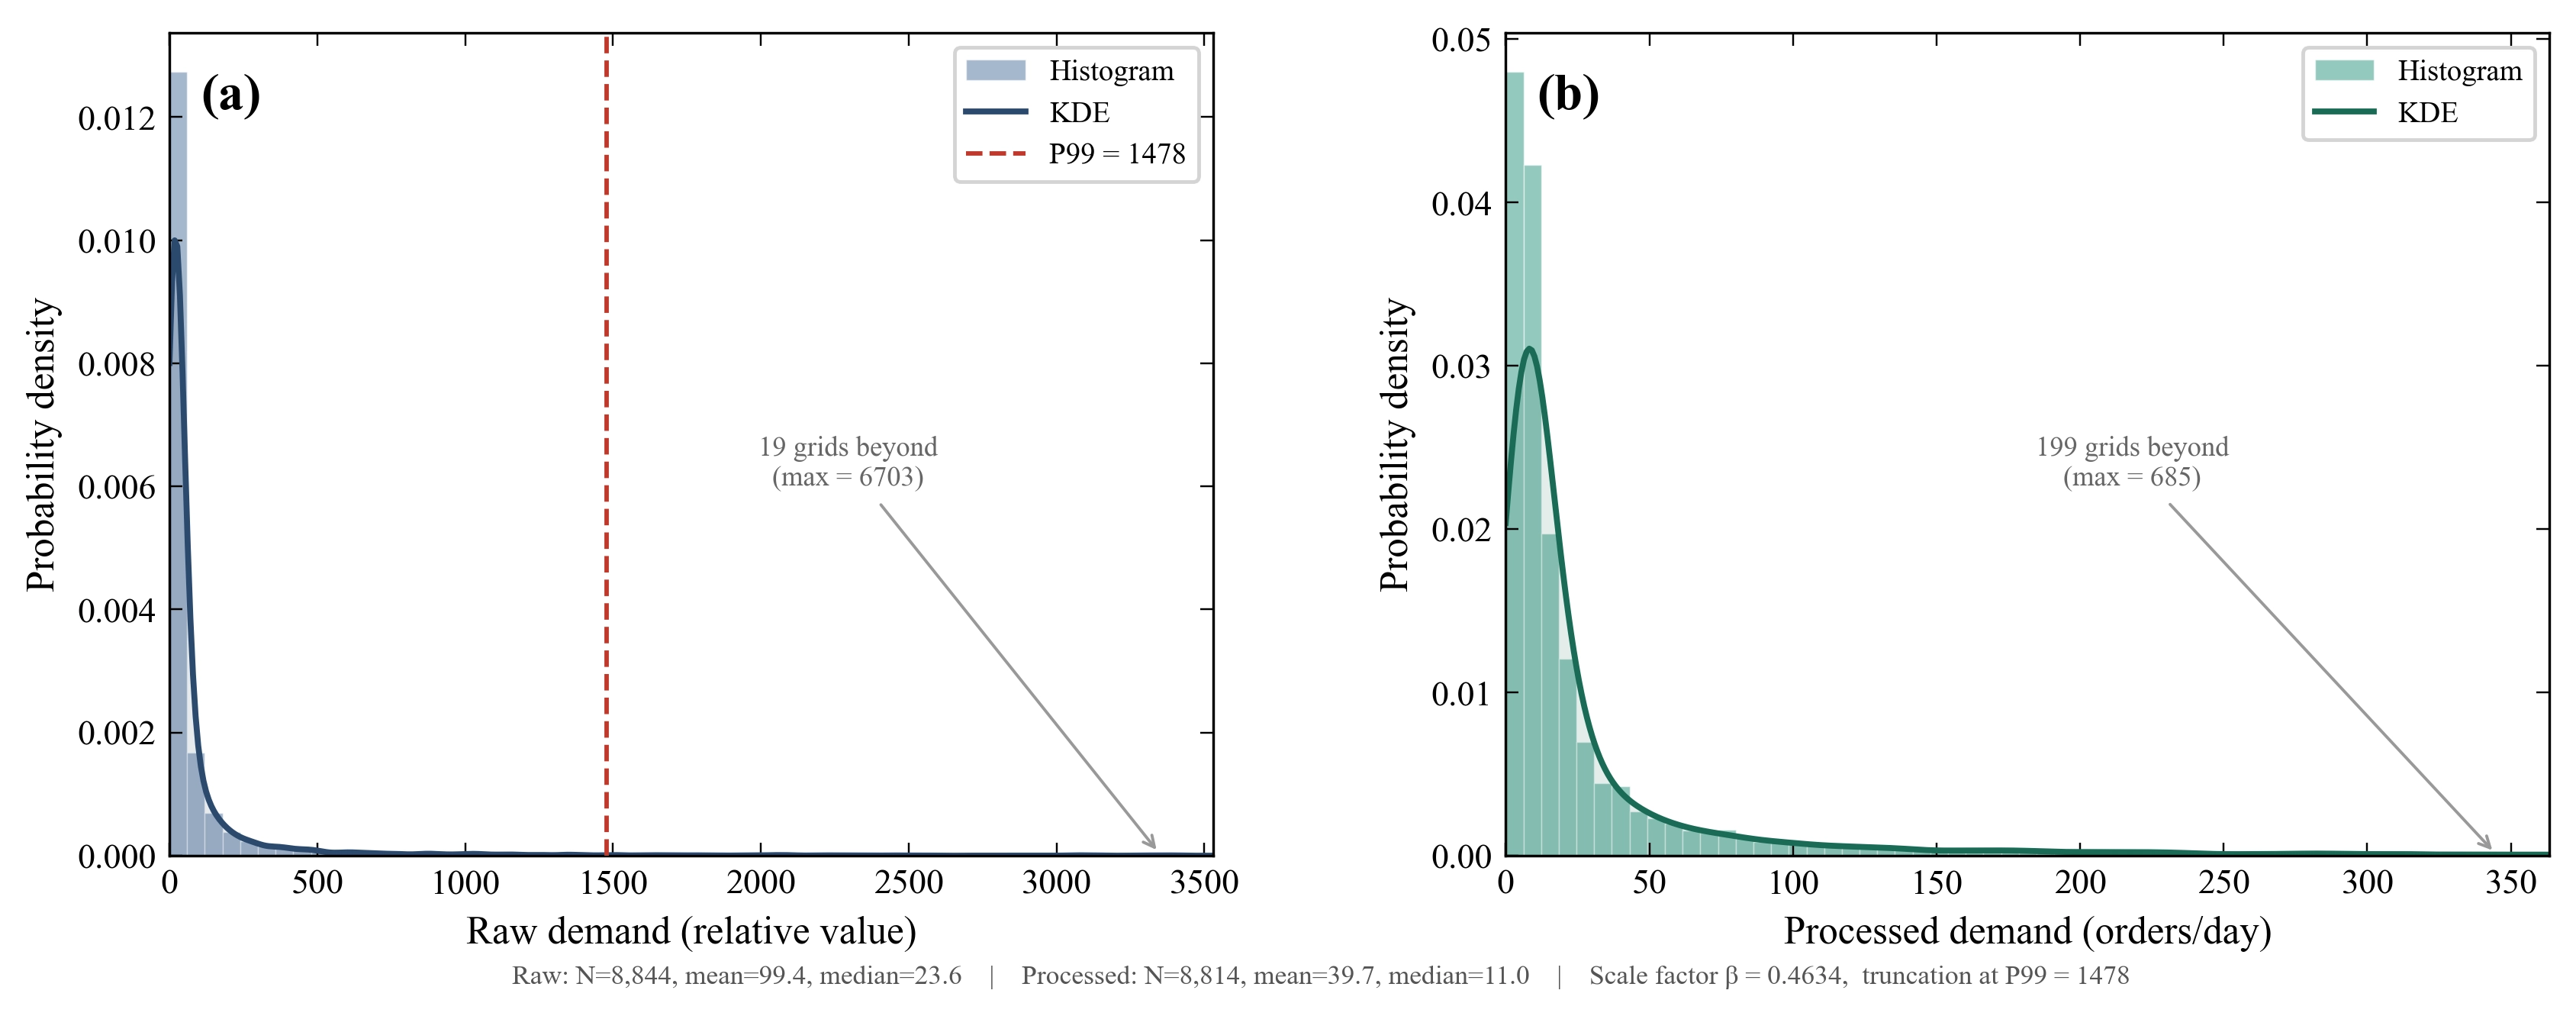
Figure 2. Demand distribution before and after robust processing and scaling. KDE: kernel density estimation.
2.2 Candidate site generation using the HFPIPS method
2.2.1 Geometric rationale
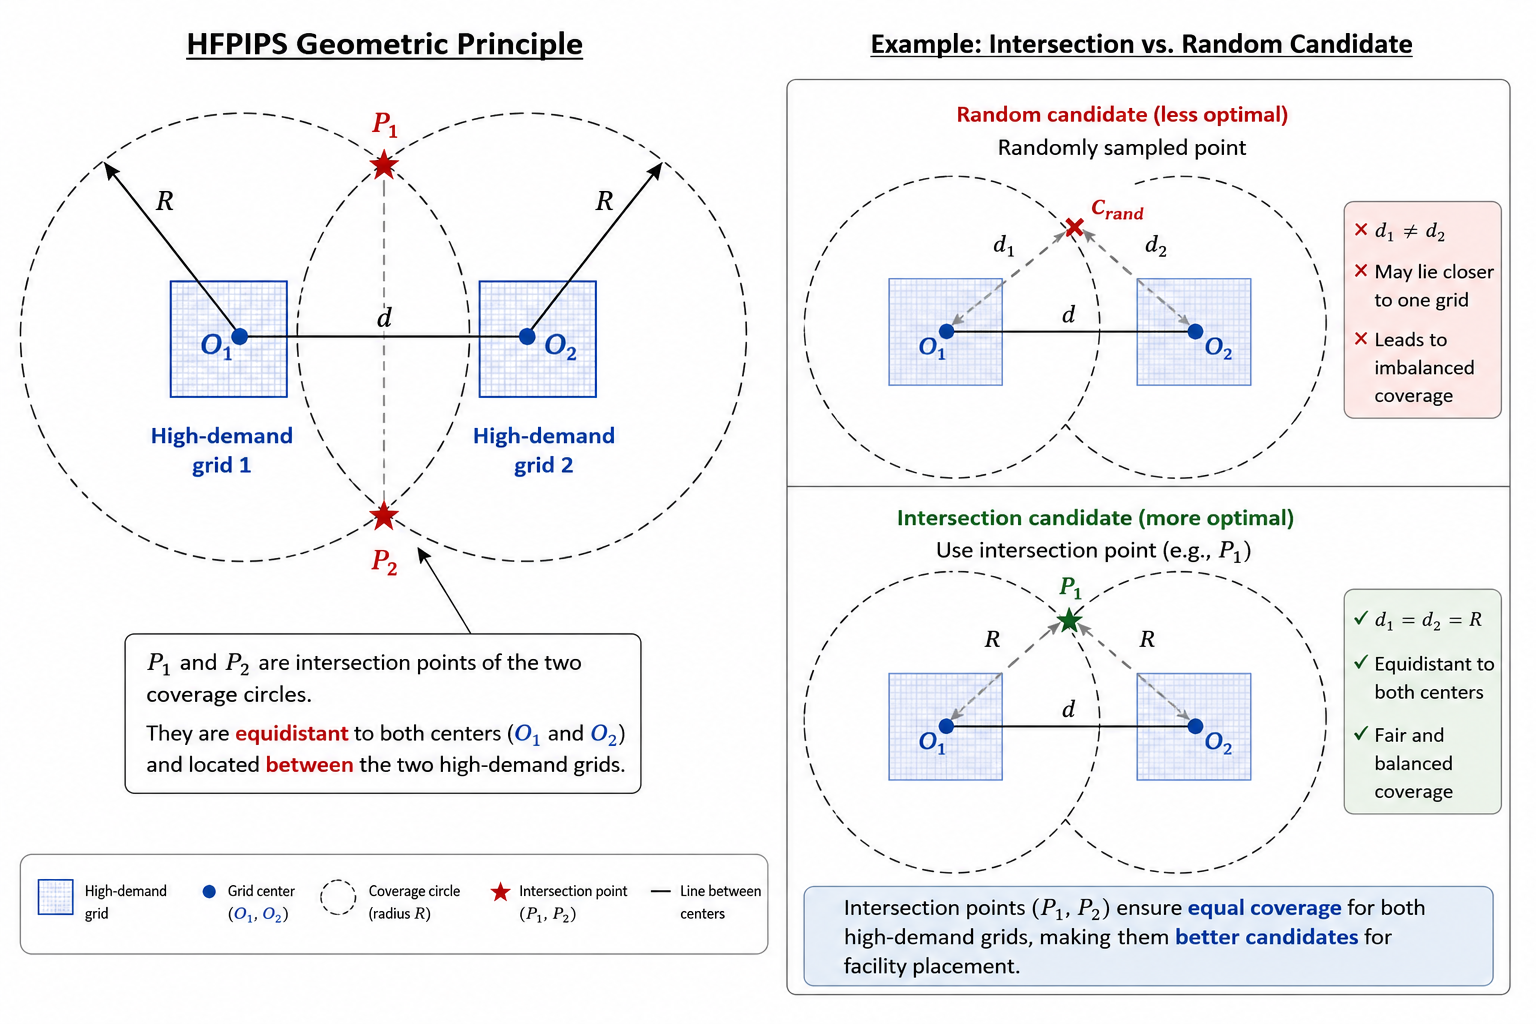
Vertiports must satisfy aircraft- and site-specific physical requirements, including adequate landing-area geometry, load-bearing capacity, and operational clearances[6,7]. While regular grid sampling, population-weighted centroid methods, and Voronoi tessellation-based approaches exist for candidate generation, these methods are not geometrically positioned to maximize joint coverage of adjacent demand concentrations. This study adopts the HFPIPS method proposed by Xue et al.[11], which exploits the geometry of coverage circles to generate candidates equidistant from pairs of adjacent high-demand grids, naturally positioned between two demand concentrations to simultaneously maximize their joint coverage.
Given two circle centers O1(x1, y1) and O2(x2, y2) with equal radius r, when the inter-center distance d ∈ (0, 2r), the intersection coordinates are:
where n is the unit normal to O1O2. All computations are performed under universal transverse mercator (UTM) projection (EPSG:32650 near Nanjing) to ensure Euclidean distances correspond to actual ground distances. Figure 3 illustrates the geometric principle of HFPIPS, showing how the intersection points P1 and P2 of two coverage circles are equidistant from both grid centers O1 and O2 and thus represent geometrically efficient candidate locations.
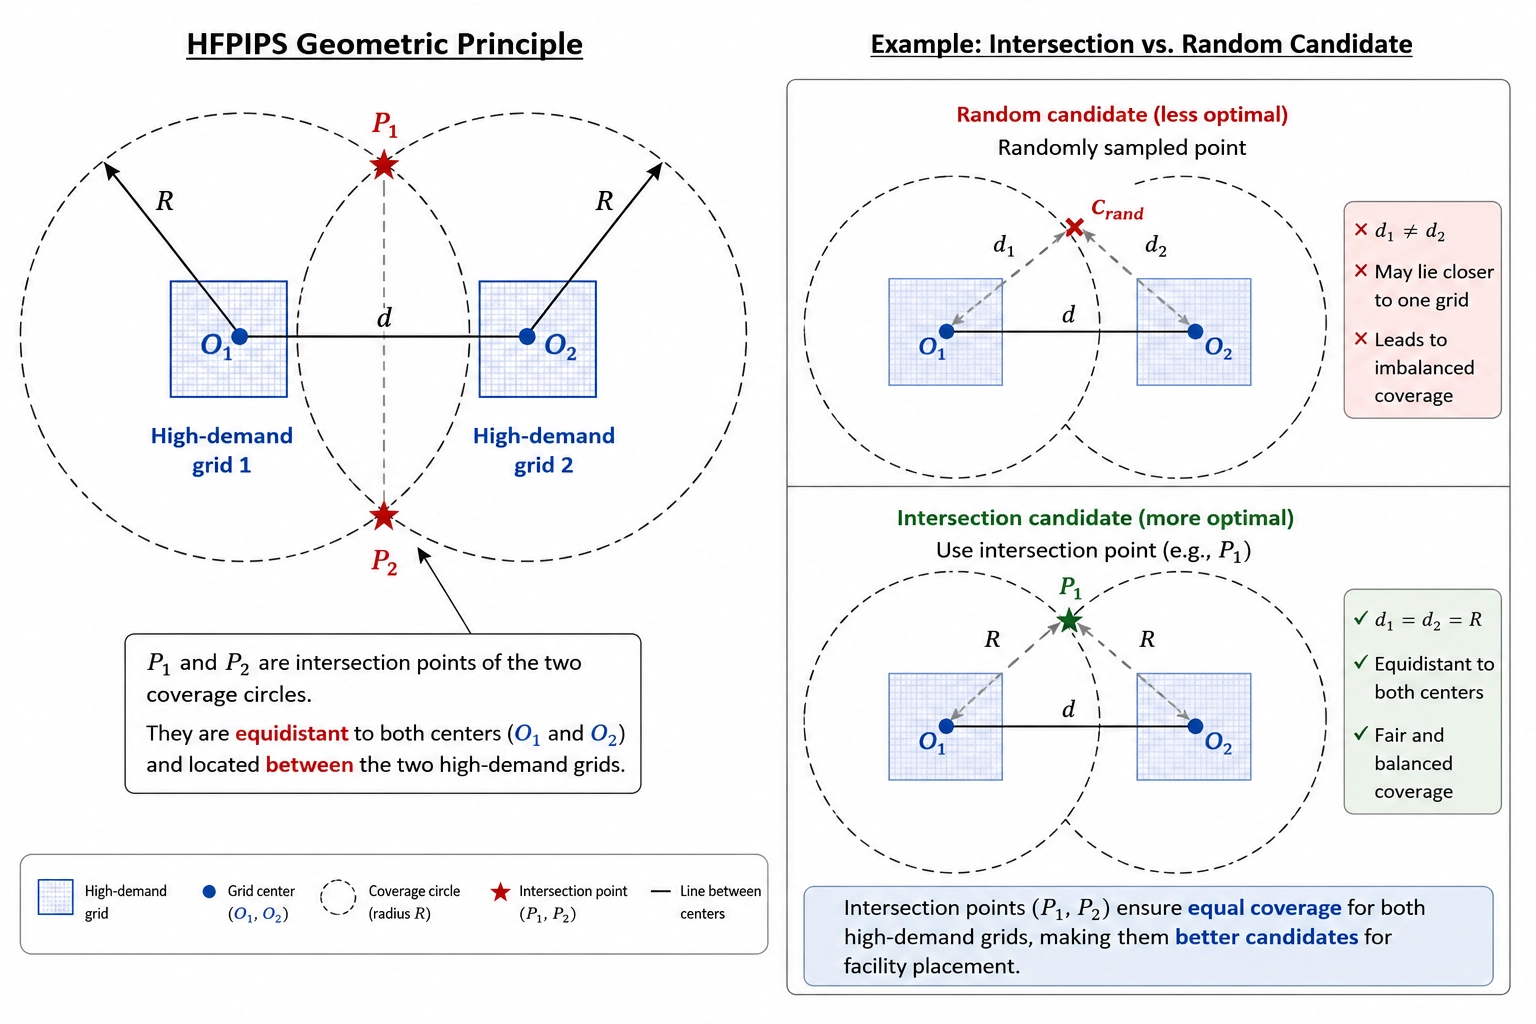
Figure 3. HFPIPS geometric principle: coverage circle intersection. HFPIPS: hierarchical facility polygon intersection point set.
2.2.2 High-demand filtering and eight-neighbor constraint
Grids with demand at or above the 75th percentile are designated as “high-demand grids”. This threshold balances coverage adequacy against candidate set size: a lower threshold generates excessive candidates, inflating computational burden; a higher threshold yields a sparser high-demand grid set, reducing intersection density. Intersection points are computed only for pairs of high-demand grids that are 8-neighbors (sharing an edge or corner), capturing diagonal adjacency while avoiding meaningless remote candidates.
2.2.3 Deduplication and forbidden zone filtering
Candidate points separated by less than 100 m are treated as duplicates; a grid-acceleration data structure reduces deduplication complexity from O(n2) to approximately O(n). Points inside water, military, and other prohibited polygons are removed. The resulting set is a planning-level candidate inventory and is not equivalent to building or construction approval.
2.2.4 Building and infrastructure screening
An optional engineering screen has been added to the reproducible pipeline. When building information modeling (BIM), city information modeling (CIM), or building-survey data are available, candidates can be filtered by usable roof area, structural load, building height, and takeoff/landing clearance. The Nanjing OSM inventory contains 53,435 building footprints but lacks these engineering attributes. Accordingly, the reported 10,283 candidates have planning status only and require structural, corridor, noise, and regulatory approval before deployment.
2.3 Capacitated facility location model (CFLP-MILP)
2.3.1 Problem definition and notation
Let I denote the set of demand grids and J the set of candidate sites; Di is the scaled demand (orders/day) of grid i; dij is the Euclidean distance (km); ε = {(i, j): dij ≤ R} is the feasible service pair set (R = 8 km); C is the per-station throughput ceiling; and α ∈ (0, 1) is the utilization floor. Decision variables: yj ∈ {0, 1} indicates whether a vertiport is established at candidate j; xij ≥ 0 represents the order volume allocated from station j to grid i, defined only for (i, j) ∈ ε.
2.3.2 Objective function
The three terms represent: (1) total delivery volume (revenue proxy); (2) a station establishment penalty proxying daily amortized fixed costs; and (3) a distance-weighted delivery penalty proxying variable operating costs. The establishment penalty αs equals the ratio of daily fixed costs to per-order net revenue, setting the break-even threshold for opening a new station. The distance penalty αd maps variable drone flight costs per km·order, encoding a preference for proximate delivery.
The economic interpretation of this objective function merits elaboration. The first term captures the operator’s core revenue stream: more deliveries generate more revenue. The second term internalizes the capital expenditure decision, each opened station incurs a daily amortized cost comprising land lease, construction depreciation, equipment maintenance, and staffing. When αs is large, the model demands that each station generate substantial delivery volume to justify its fixed cost, producing a network with fewer, higher-throughput stations. The third term penalizes long-distance delivery, reflecting the real-world cost structure where drone battery consumption, flight time, and airspace occupancy all increase with distance. The interplay among these three terms naturally produces an economically rational network: stations are opened where marginal delivery revenue exceeds marginal fixed and variable costs, and demand is allocated to the nearest feasible station to minimize distance penalties. This formulation subsumes both the location decision (which stations to open) and the allocation decision (how to route demand) within a single optimization, avoiding the sequential decomposition bias inherent in two-stage approaches.
2.3.3 Constraints
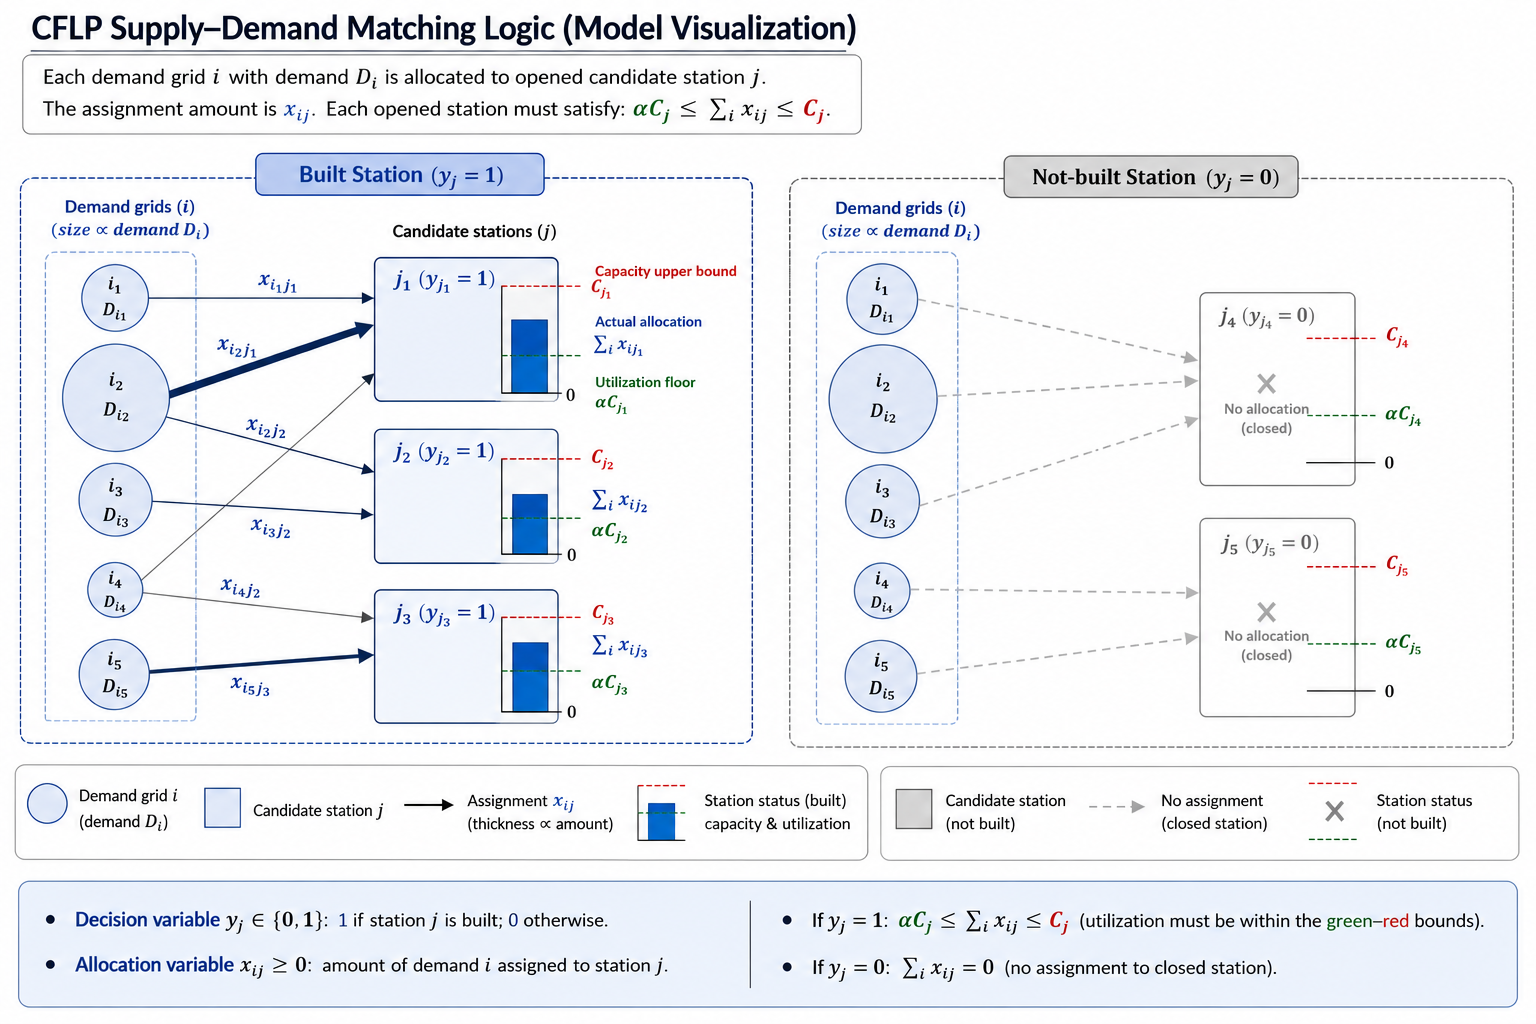
Figure 4 provides a conceptual illustration of the CFLP model logic, showing how demand grids of varying sizes allocate order flows to an opened station, subject to the throughput ceiling C and utilization floor αC. The formal constraint set is summarized in Table 2.
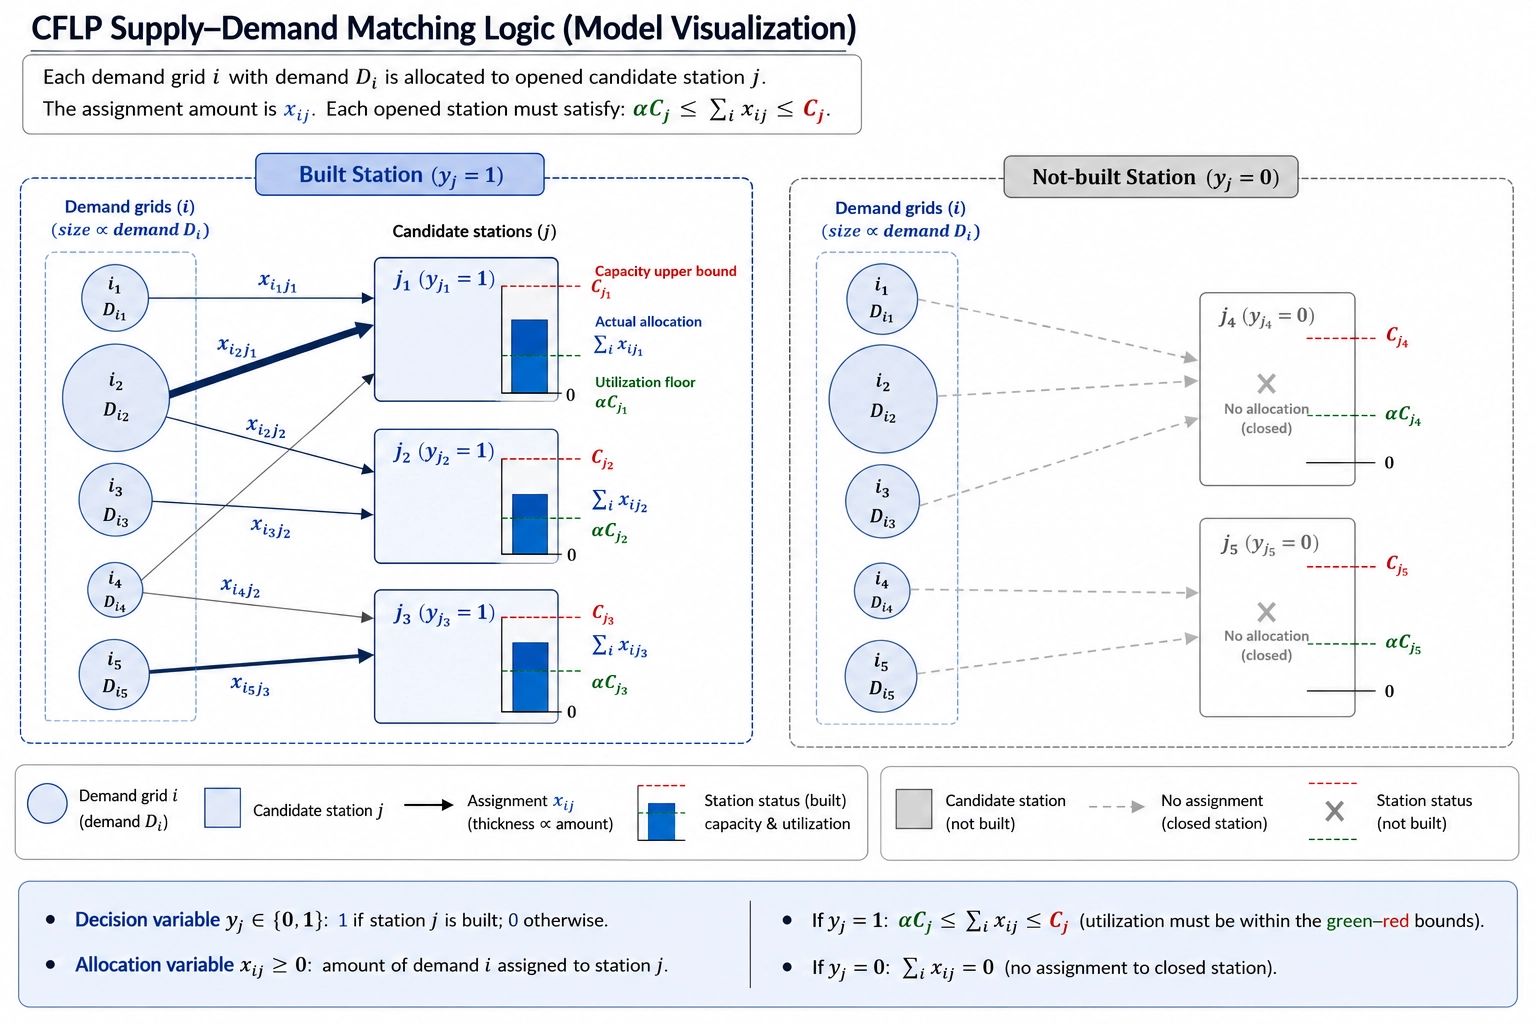
Figure 4. CFLP supply-demand matching logic: capacity ceiling and utilization floor. CFLP: capacitated facility location problem.
Table 2. CFLP model constraints.
| Constraint | Mathematical Form | Meaning |
| Demand non-exceedance | Allocated volume does not exceed grid demand | |
| Throughput ceiling | If built, total delivery ≤ C | |
| Utilization floor | If built, total delivery ≥ αC | |
| Binary and non-negativity | Station opening is binary; allocation is non-negative |
CFLP: capacitated facility location problem.
The utilization floor is a standard linear linking constraint used here to express the minimum viable throughput of a capital-intensive vertiport. The contribution is not a claim of a new algebraic form, but its explicit integration with station capacity, continuous order allocation, and the metropolitan candidate-reduction workflow. Section 3.6 isolates its effect through a no-floor CFLP comparison.
2.3.4 Service coverage mode
This study adopts a selective service mode: if idle capacity exists, it is used; demand within the service radius is not forced to be fully satisfied. Combined with the utilization floor, this ensures every opened station maintains minimum throughput while allowing the optimization to focus capacity on the highest-value service opportunities.
2.3.5 Heterogeneous fleet and time-varying demand extension
The present experiment uses a homogeneous fleet and deterministic daily demand. A heterogeneous extension would index allocation xijh and station fleet njh by aircraft type h, with type-specific payload qh, range Rh, operating cost, acquisition cost, and available fleet Nh; capacity and range constraints would then be enforced by type. A multi-period or scenario extension would retain site decisions yj in the first stage and index allocation by time and demand scenario in recourse. No numerical extension is reported because defensible type-specific fleet and order-history data are unavailable.
2.4 Adaptive spatial dimensionality reduction algorithm
At metropolitan scale, the total feasible service set |ε| can reach millions after applying the service radius filter, causing a variable space of O(|I||J|) that renders direct MILP construction intractable. This study proposes an adaptive heuristic dimensionality reduction algorithm: for each grid i, only the K nearest candidate sites are retained, reducing the variable space from O(|I||J|) to O(|I|·K).
The K threshold is set adaptively by local capacity competition intensity: high-demand grids (Di ≥ median(D)) are assigned Khigh = 55, providing sufficient candidate diversity for multi-station load distribution when the nearest station is at capacity; regular grids are assigned Kbase = 35, substantially compressing variable space where a single nearby station suffices.
The theoretical rationale for demand-adaptive thresholds rests on the observation that capacity competition is spatially heterogeneous. In high-demand zones, the nearest candidate station is likely to reach its throughput ceiling, forcing the solver to consider alternative stations further away. If the candidate pool is artificially truncated to a small K, the model may be unable to find feasible allocations for excess demand, leading to suboptimal solutions or infeasibility. In contrast, low-demand grids rarely exhaust the capacity of their nearest station, making a larger candidate pool redundant, it merely inflates the constraint matrix without improving solution quality. By aligning pool size with local competitive pressure, the algorithm preserves solution quality where it matters most while aggressively compressing dimensionality elsewhere.
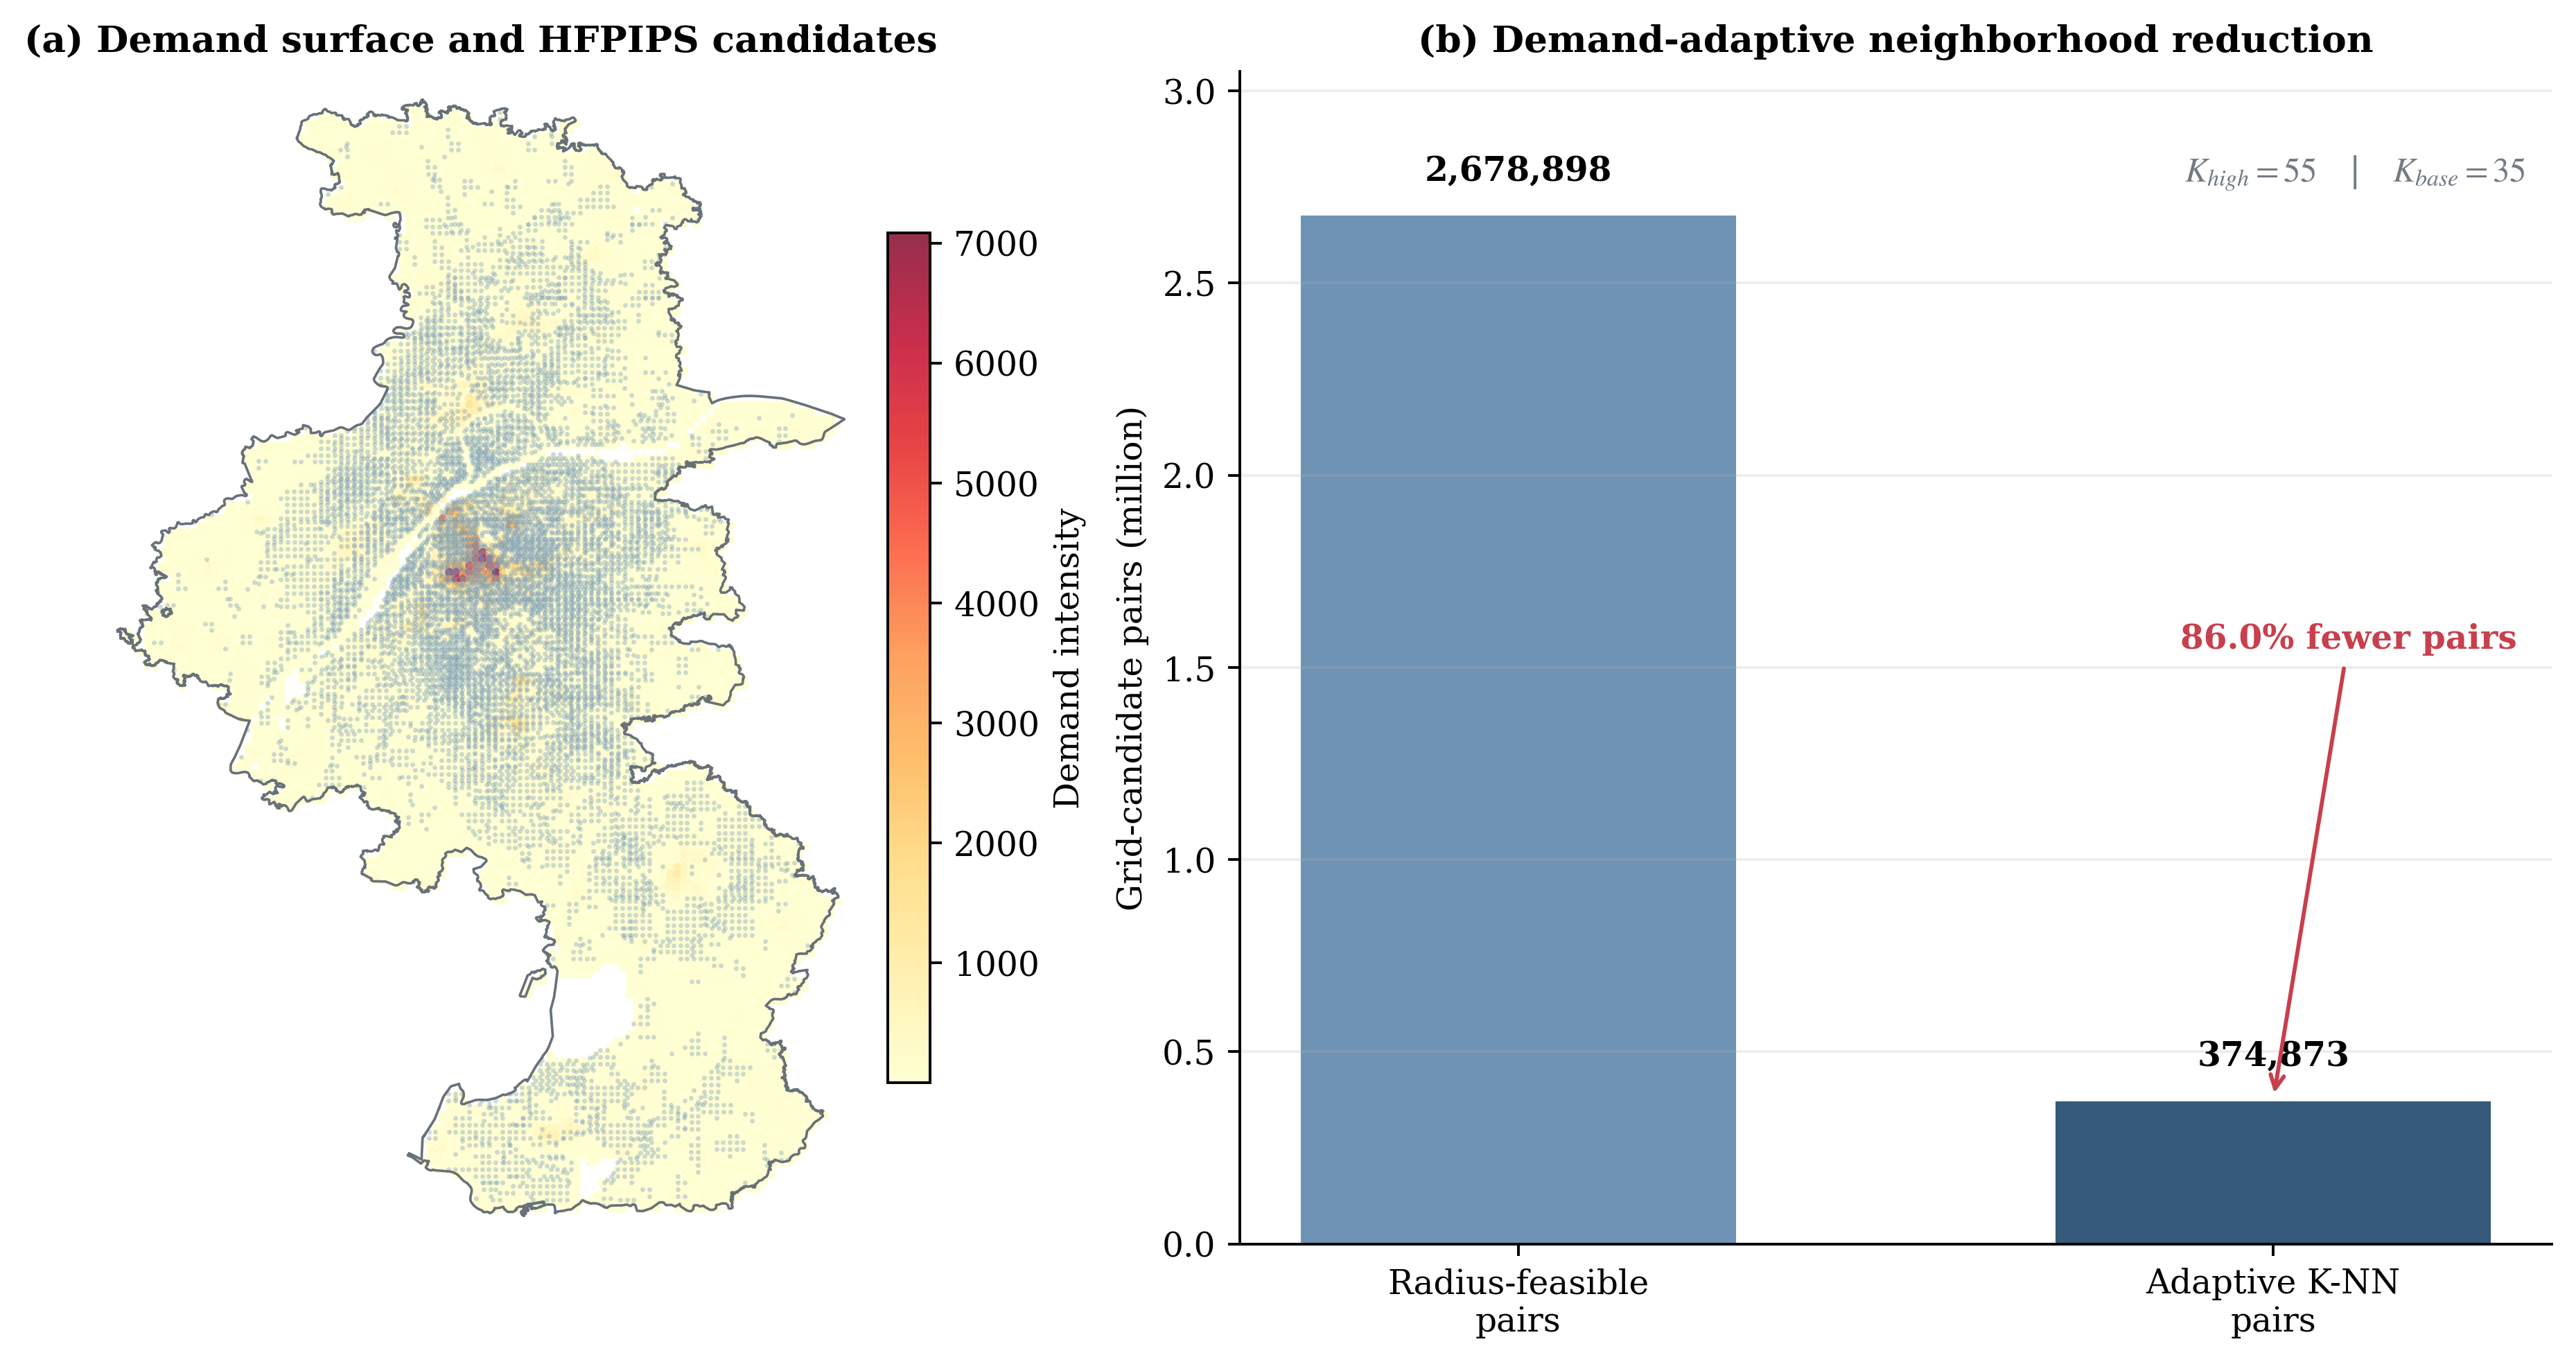
For the unified Nanjing inputs, the 8 km radius creates 2,678,898 feasible grid-candidate pairs. The Khigh = 55 and Kbase = 35 rule retains 374,873 pairs. This is a deterministic heuristic reduction, not an exact decomposition; the reported result therefore documents the retained instance and does not claim that pruning preserves the global optimum.
2.5 Solver configuration
The model is implemented in Python 3.14.2 with PuLP 3.3.0 and COIN-OR Branch and Cut (CBC) 2.10.3 on Windows 11 (AMD64 Family 25 Model 97, 32 logical processors, 15.22 GB random access memory (RAM)).The reported CFLP runs use one solver thread, random seed 1, and a 300 s time limit. CBC returns verified feasible incumbents but does not close the metropolitan gaps within this budget; log-derived gaps are approximately 50.0% for baseline, 21.9% for high coverage, and 23.8% for no-floor CFLP. Accordingly, the results are not presented as certified global optima.
3. Results
3.1 Study area, data, and parameter configuration
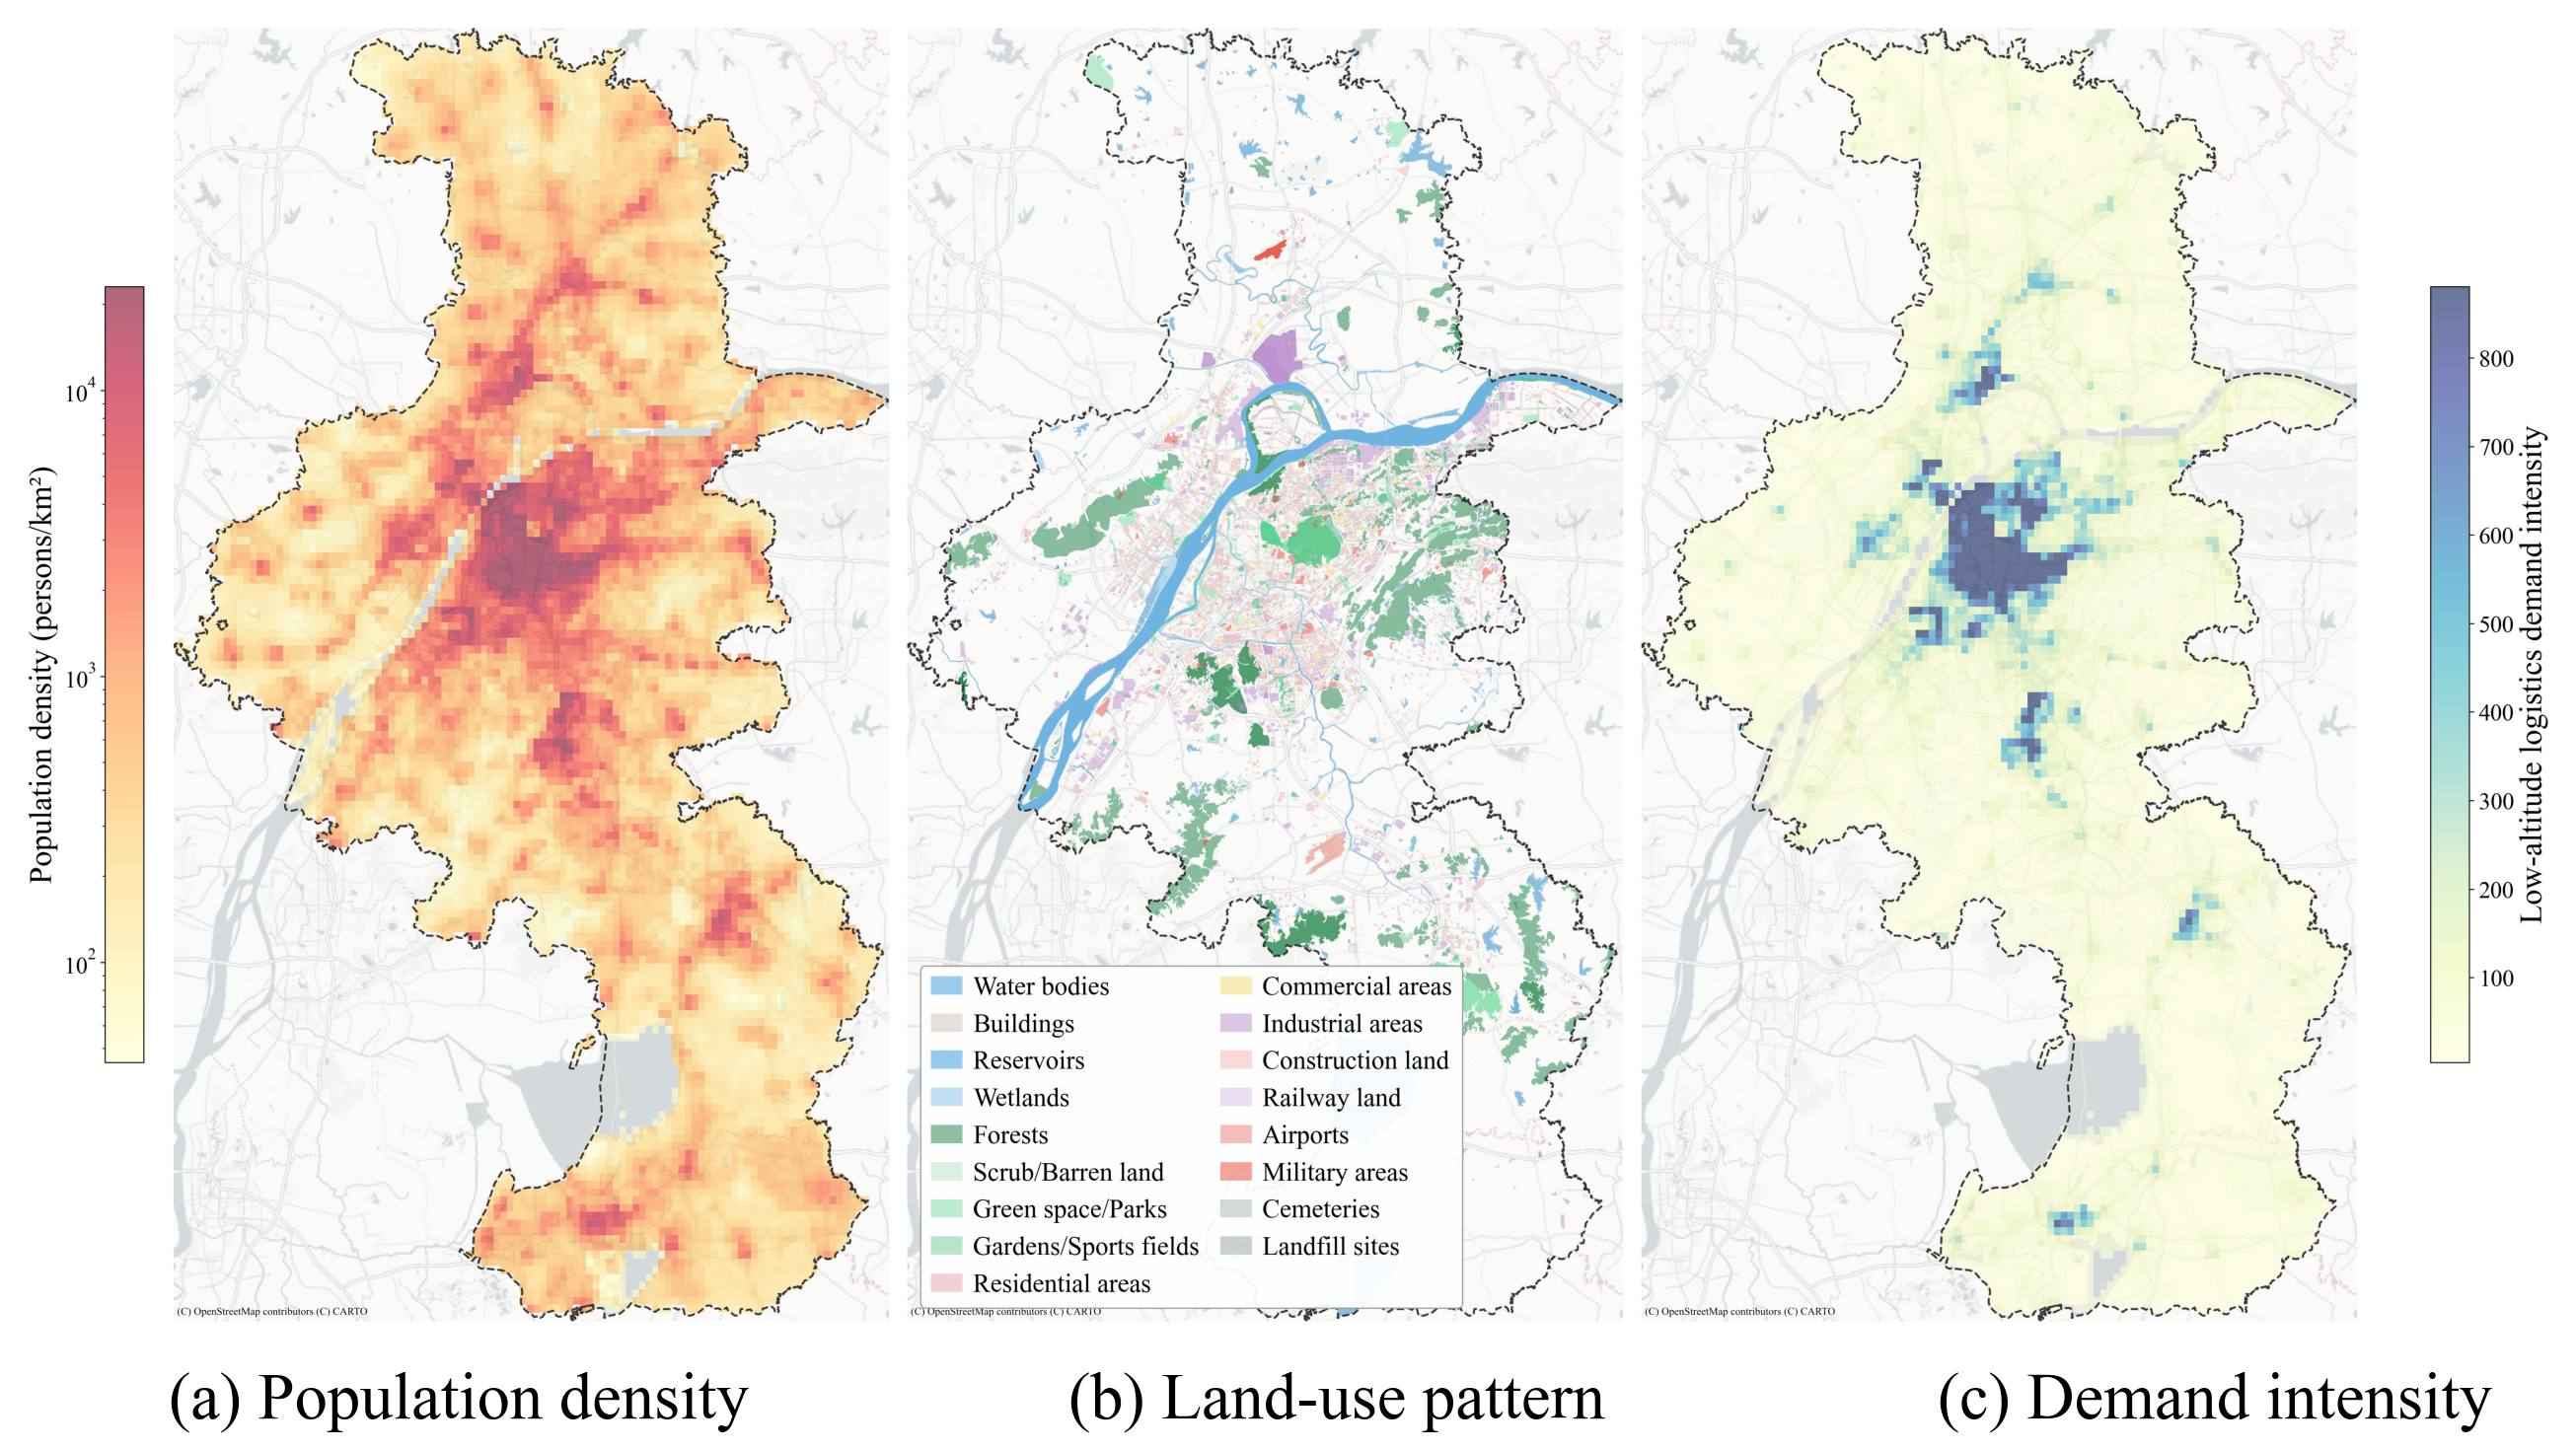
Nanjing, the capital of Jiangsu Province, covers approximately 6,587 km2 with a resident population of approximately 9.5 million. The city’s polycentric structure, comprising a dense urban core (Gulou, Xuanwu, Qinhuai, Jianye), several sub-centers (Jiangning, Pukou, Qixia), and extensive outer suburban areas (Luhe, Gaochun, Lishui), creates steep demand gradients that make it an ideal test case for the supply-demand matching framework. The corrected unified dataset comprises 8,811 positive-demand 1 km × 1 km grids; the planning candidate set contains 10,283 locations. Figure 5 presents the spatial distribution of population density, land use patterns, and derived demand intensity across Nanjing’s grid system, confirming a clear core-periphery structure with peak demand in the Xinjiekou, Hexi, and Fuzimiao commercial areas. The available OSM inventory contains 53,435 building footprints but lacks the height, roof-load, and clearance attributes required for engineering approval.
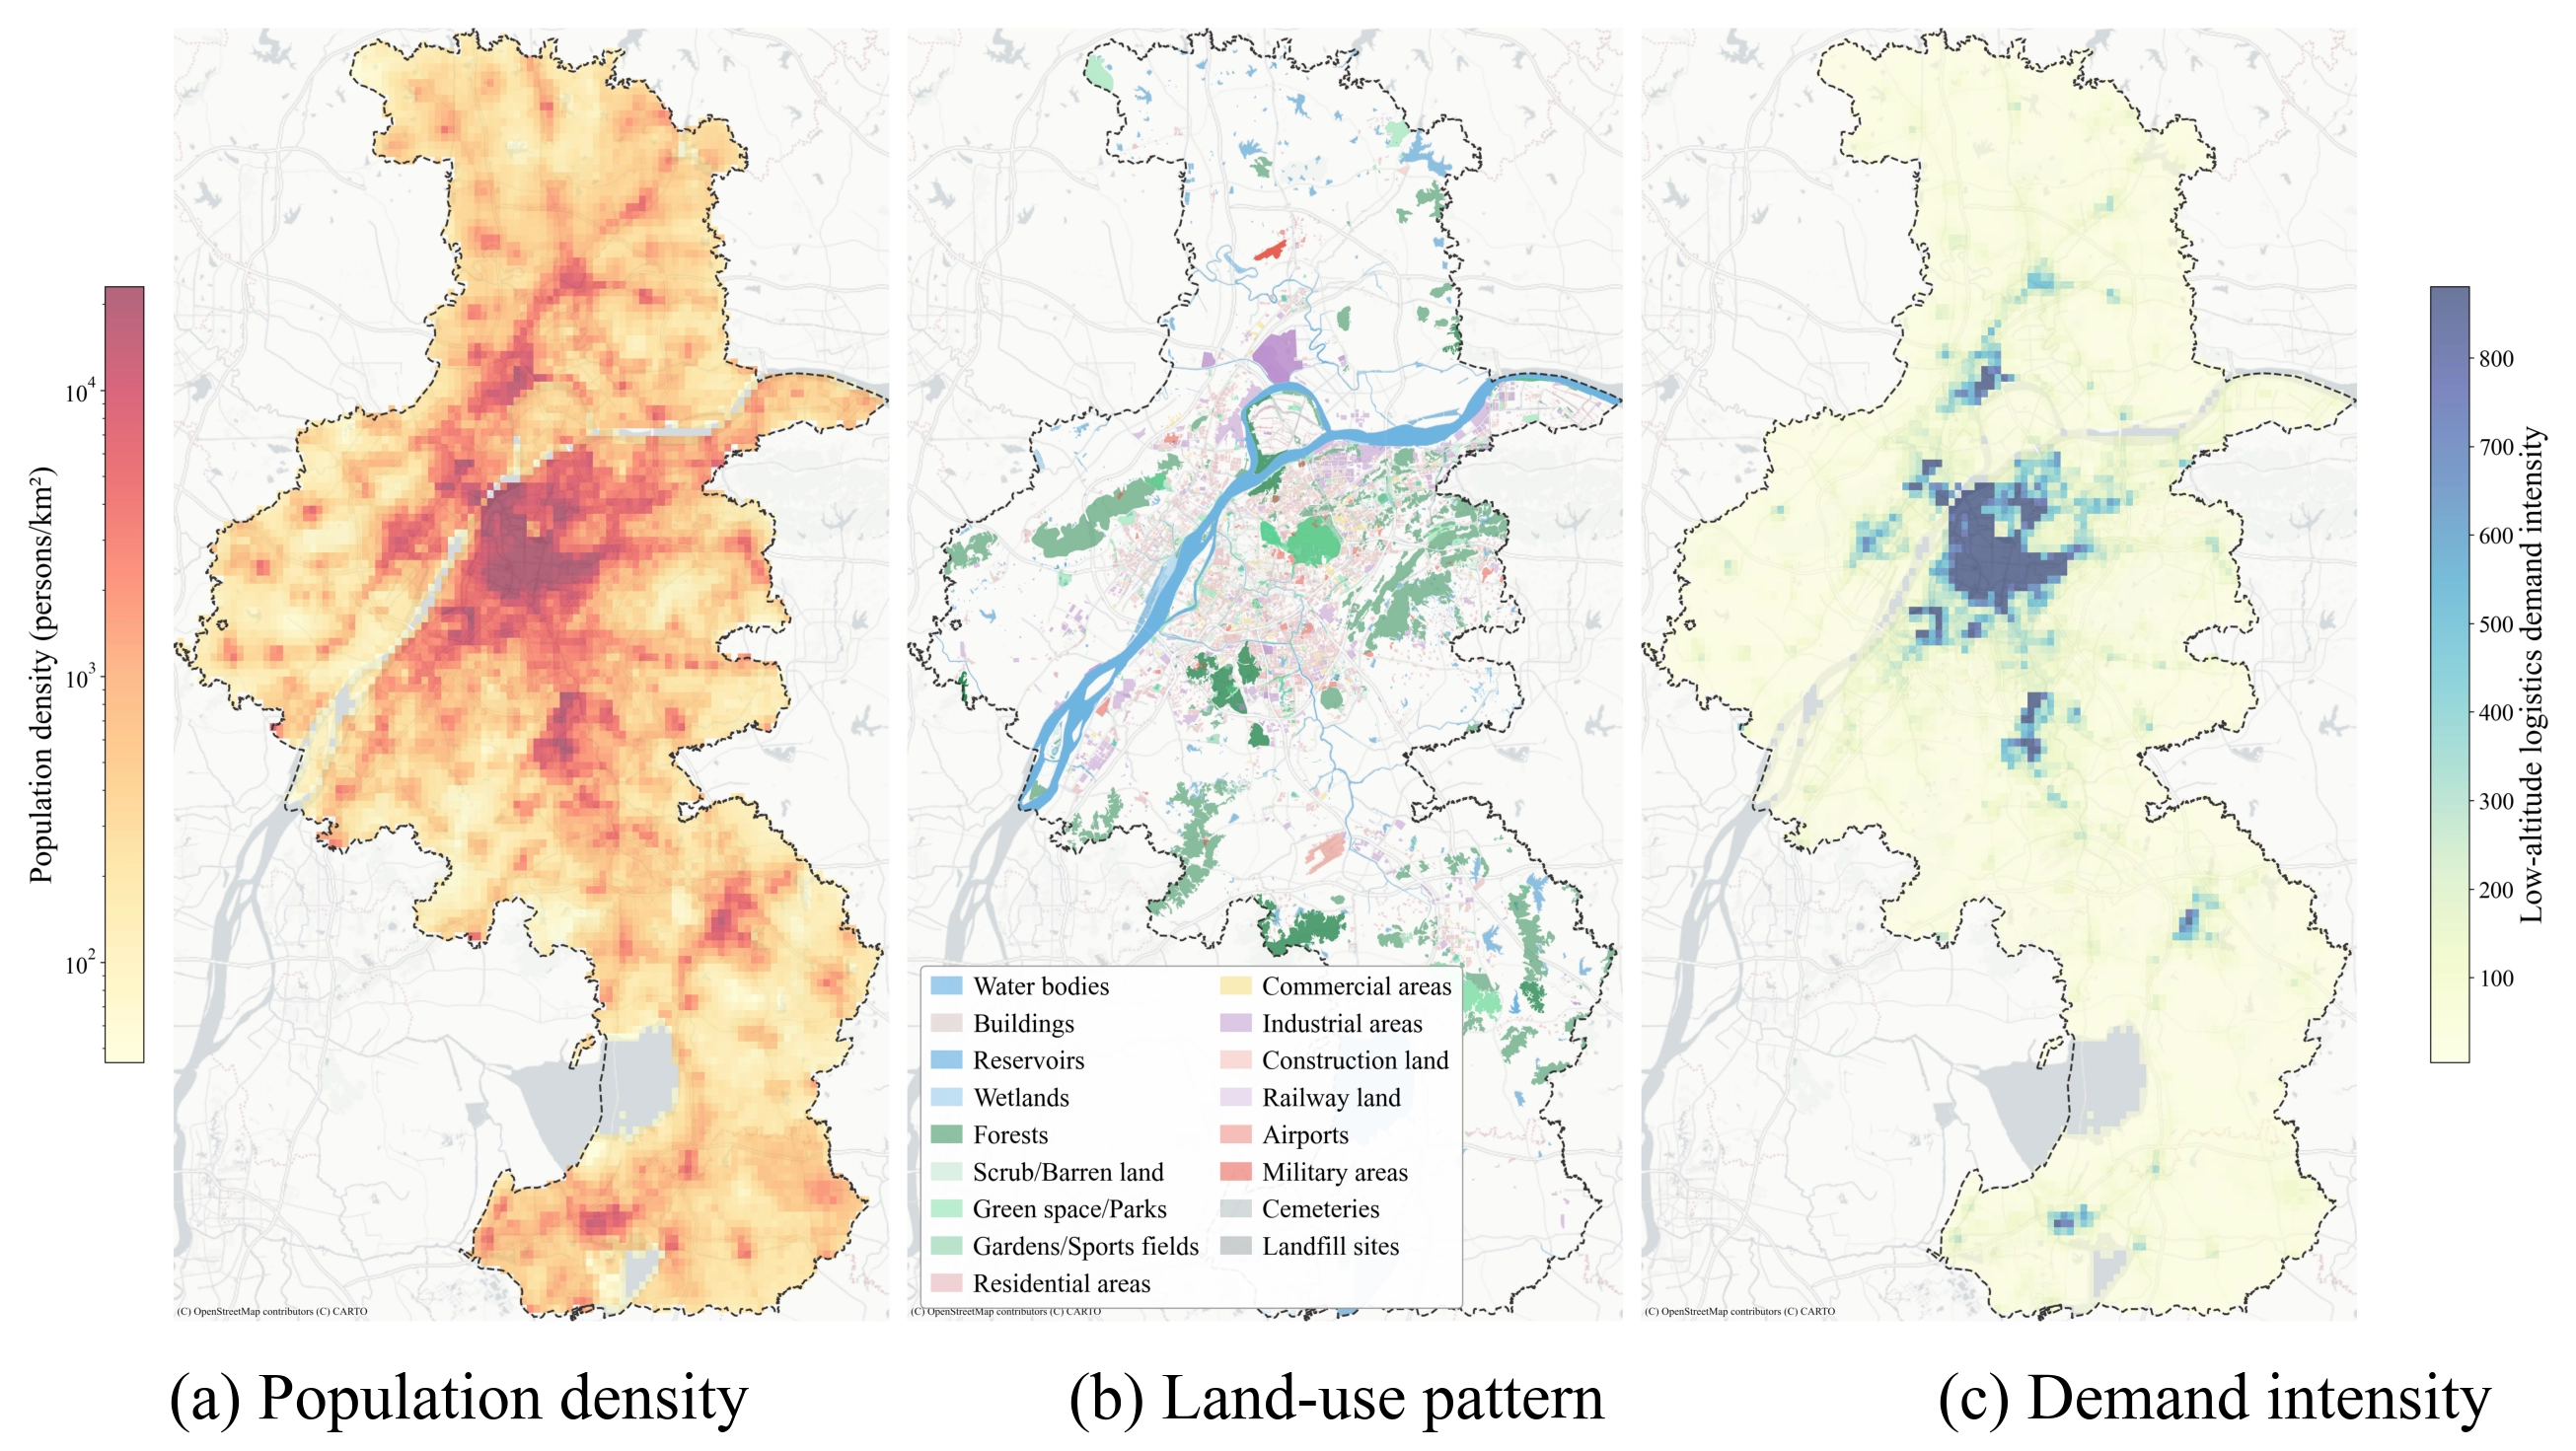
Figure 5. Spatial distribution of low-altitude logistics demand in Nanjing (1 km grid). OSMnx: OpenStreetMap NetworkX.
The planning target remains approximately 200,000 orders/day; integer grid scaling produces 200,048 orders/day in the exported dataset. Population density is from WorldPop, while land use, building footprints, map layers, and administrative boundaries are from OpenStreetMap contributors through Overpass/OSMnx. Key parameters are summarized in Table 3.
Table 3. Key parameter summary.
| Parameter | Default Value | Derivation Basis |
| Dtarget | 200,048 orders/day | Integer-scaled unified demand total |
| C | 1,200 orders/day | 10 pads × 10 hr/day × 12 sorties/hr |
| R | 8 km | Drone battery endurance and safety margin |
| αs | 500/200/100 (baseline/high/wide) | Daily fixed cost ÷ per-order net margin |
| αd | 0.3 | Variable flight cost ÷ per-order net margin |
| α | 0.15/0.10/0.05 (baseline/high/wide) | Minimum heavy-asset utilization threshold |
| Khigh/Kbase | 55/35 | Demand-adaptive heuristic; 374,873 retained pairs |
3.2 Spatial pruning and candidate coverage analysis
The HFPIPS method generates 10,283 planning candidate sites from 8-neighbor high-demand grid pair intersections, after forbidden zone filtering. Figure 6 presents the spatial distribution of demand alongside candidate sites (left panel), and the K-nearest neighbor pruning statistics including a sensitivity curve for the K parameter (right panel). Candidate sites are densely concentrated in the high-demand urban core belt, closely matching the demand heatmap and validating the HFPIPS geometric rationale. The adaptive pruning reduces feasible service pairs to 374,873, from 2,678,898 radius-feasible pairs. This deterministic pruning is a heuristic restriction and is not claimed to preserve the global optimum.
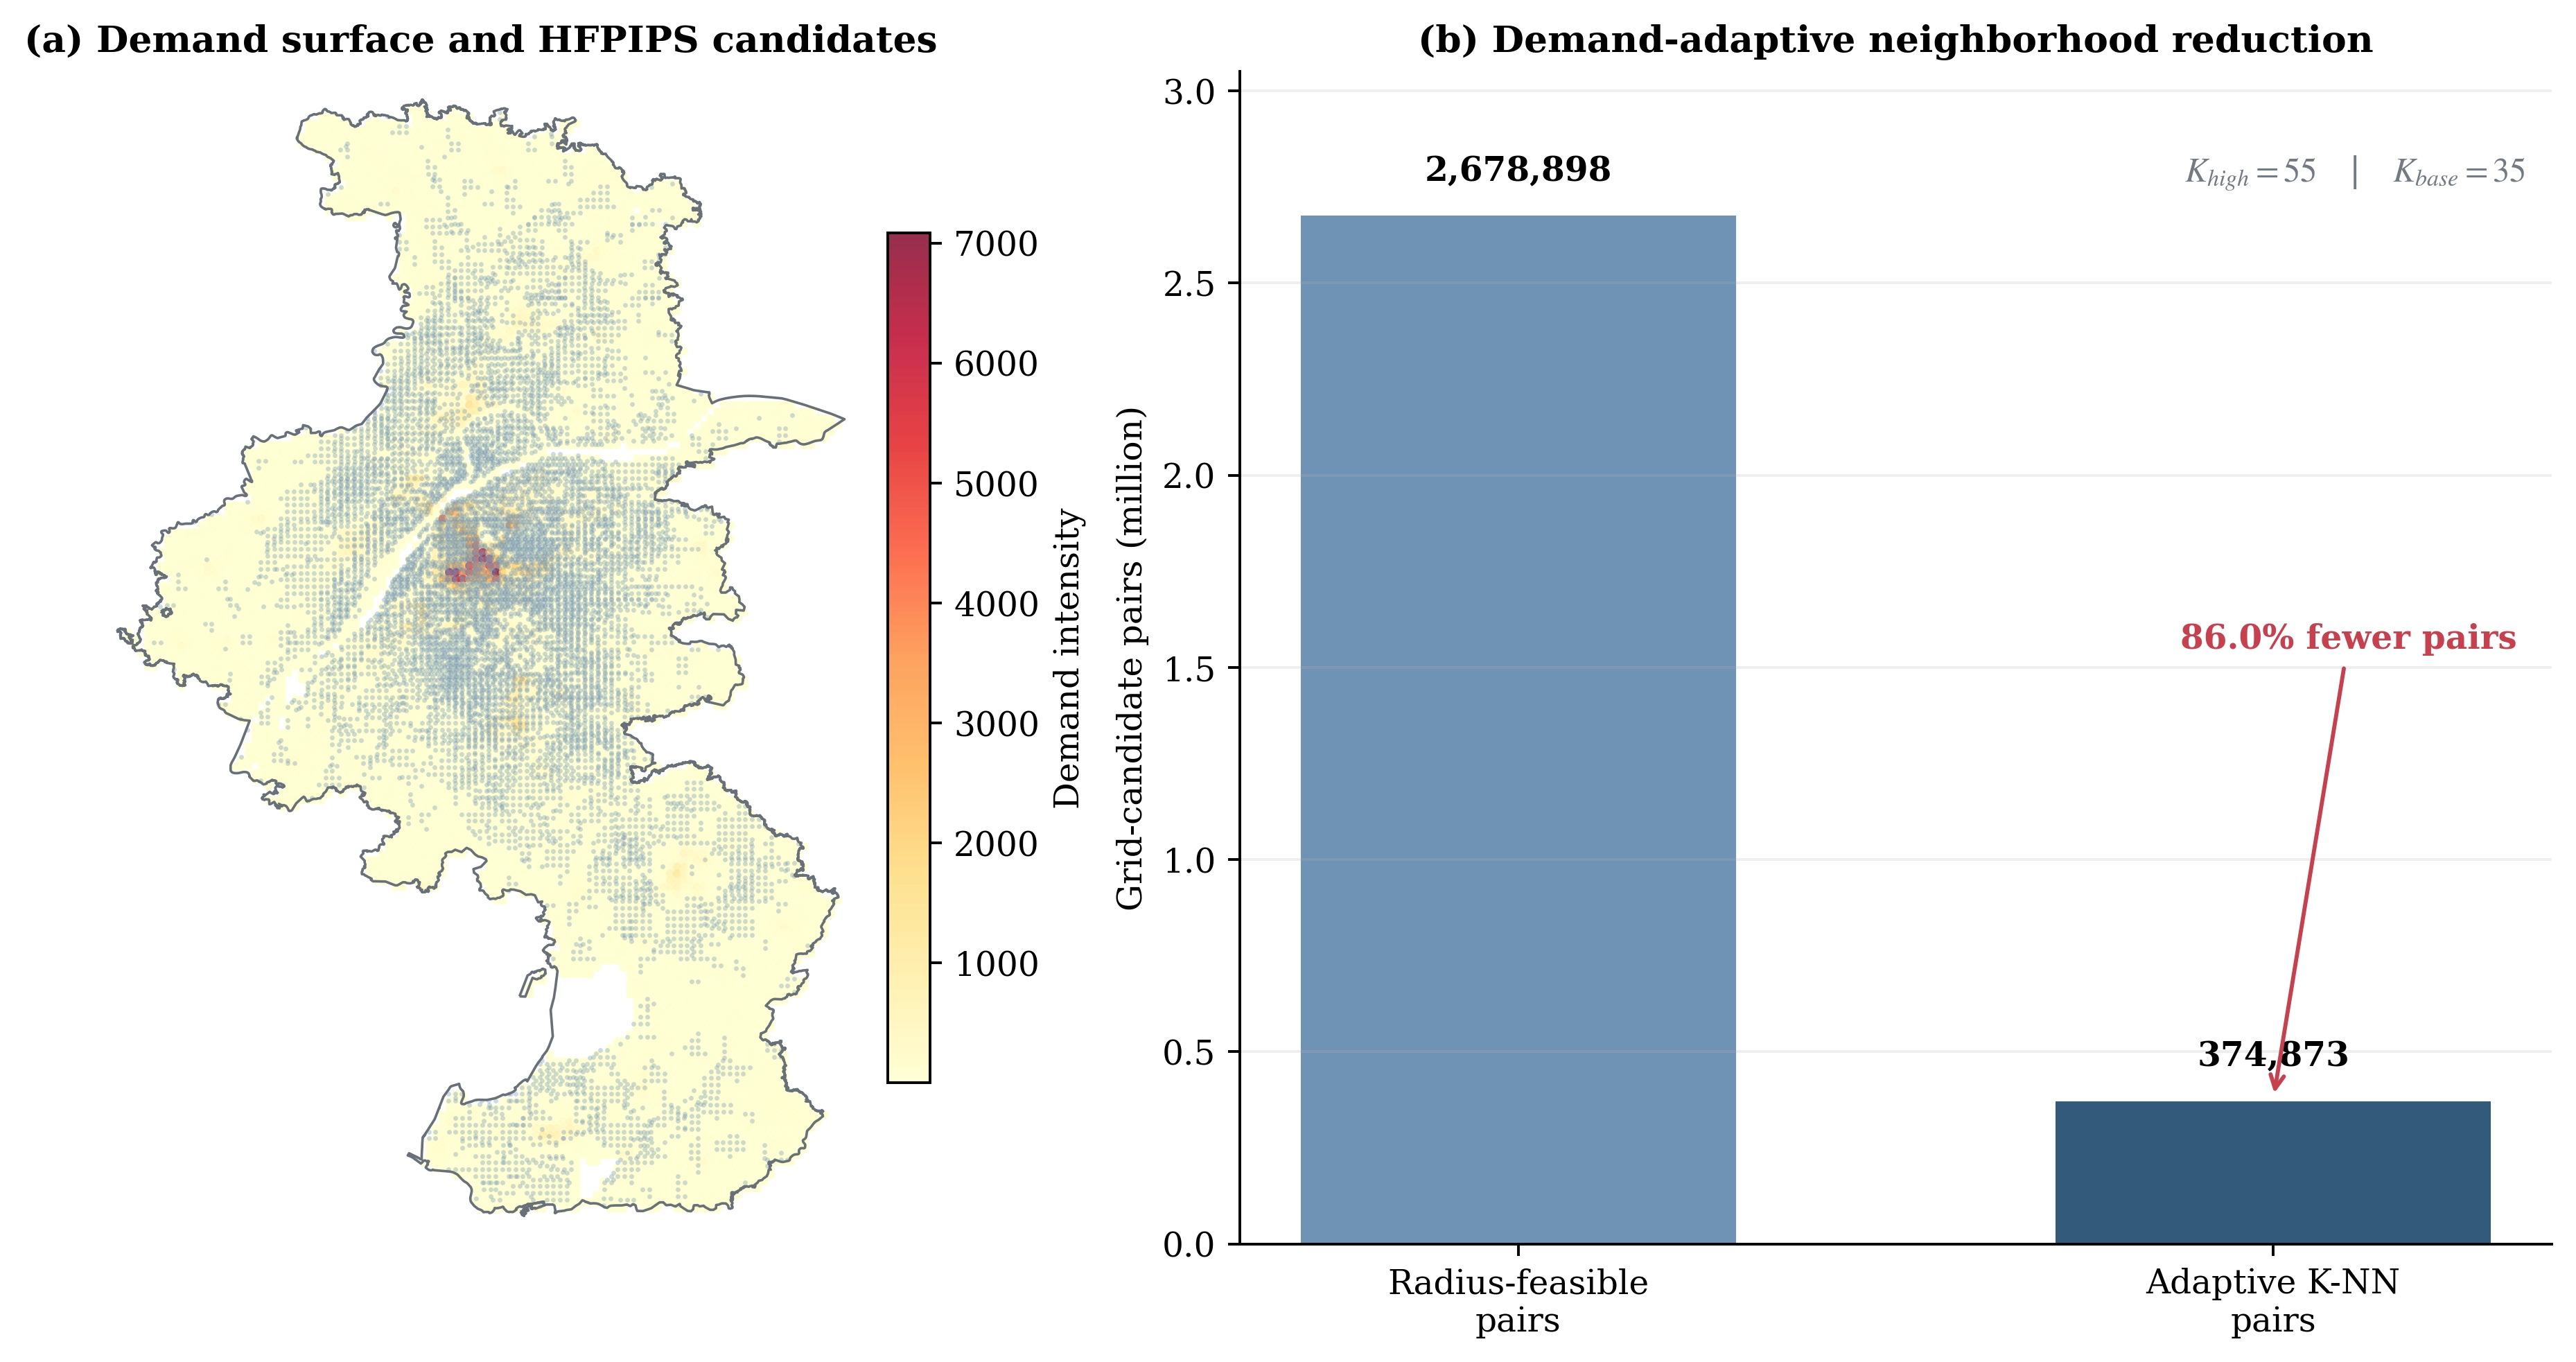
Figure 6. Candidate site spatial distribution and adaptive K-NN pruning analysis. K-NN: K-nearest neighbor.
3.3 Location and allocation spatial pattern analysis
3.3.1 Facility utilization distribution
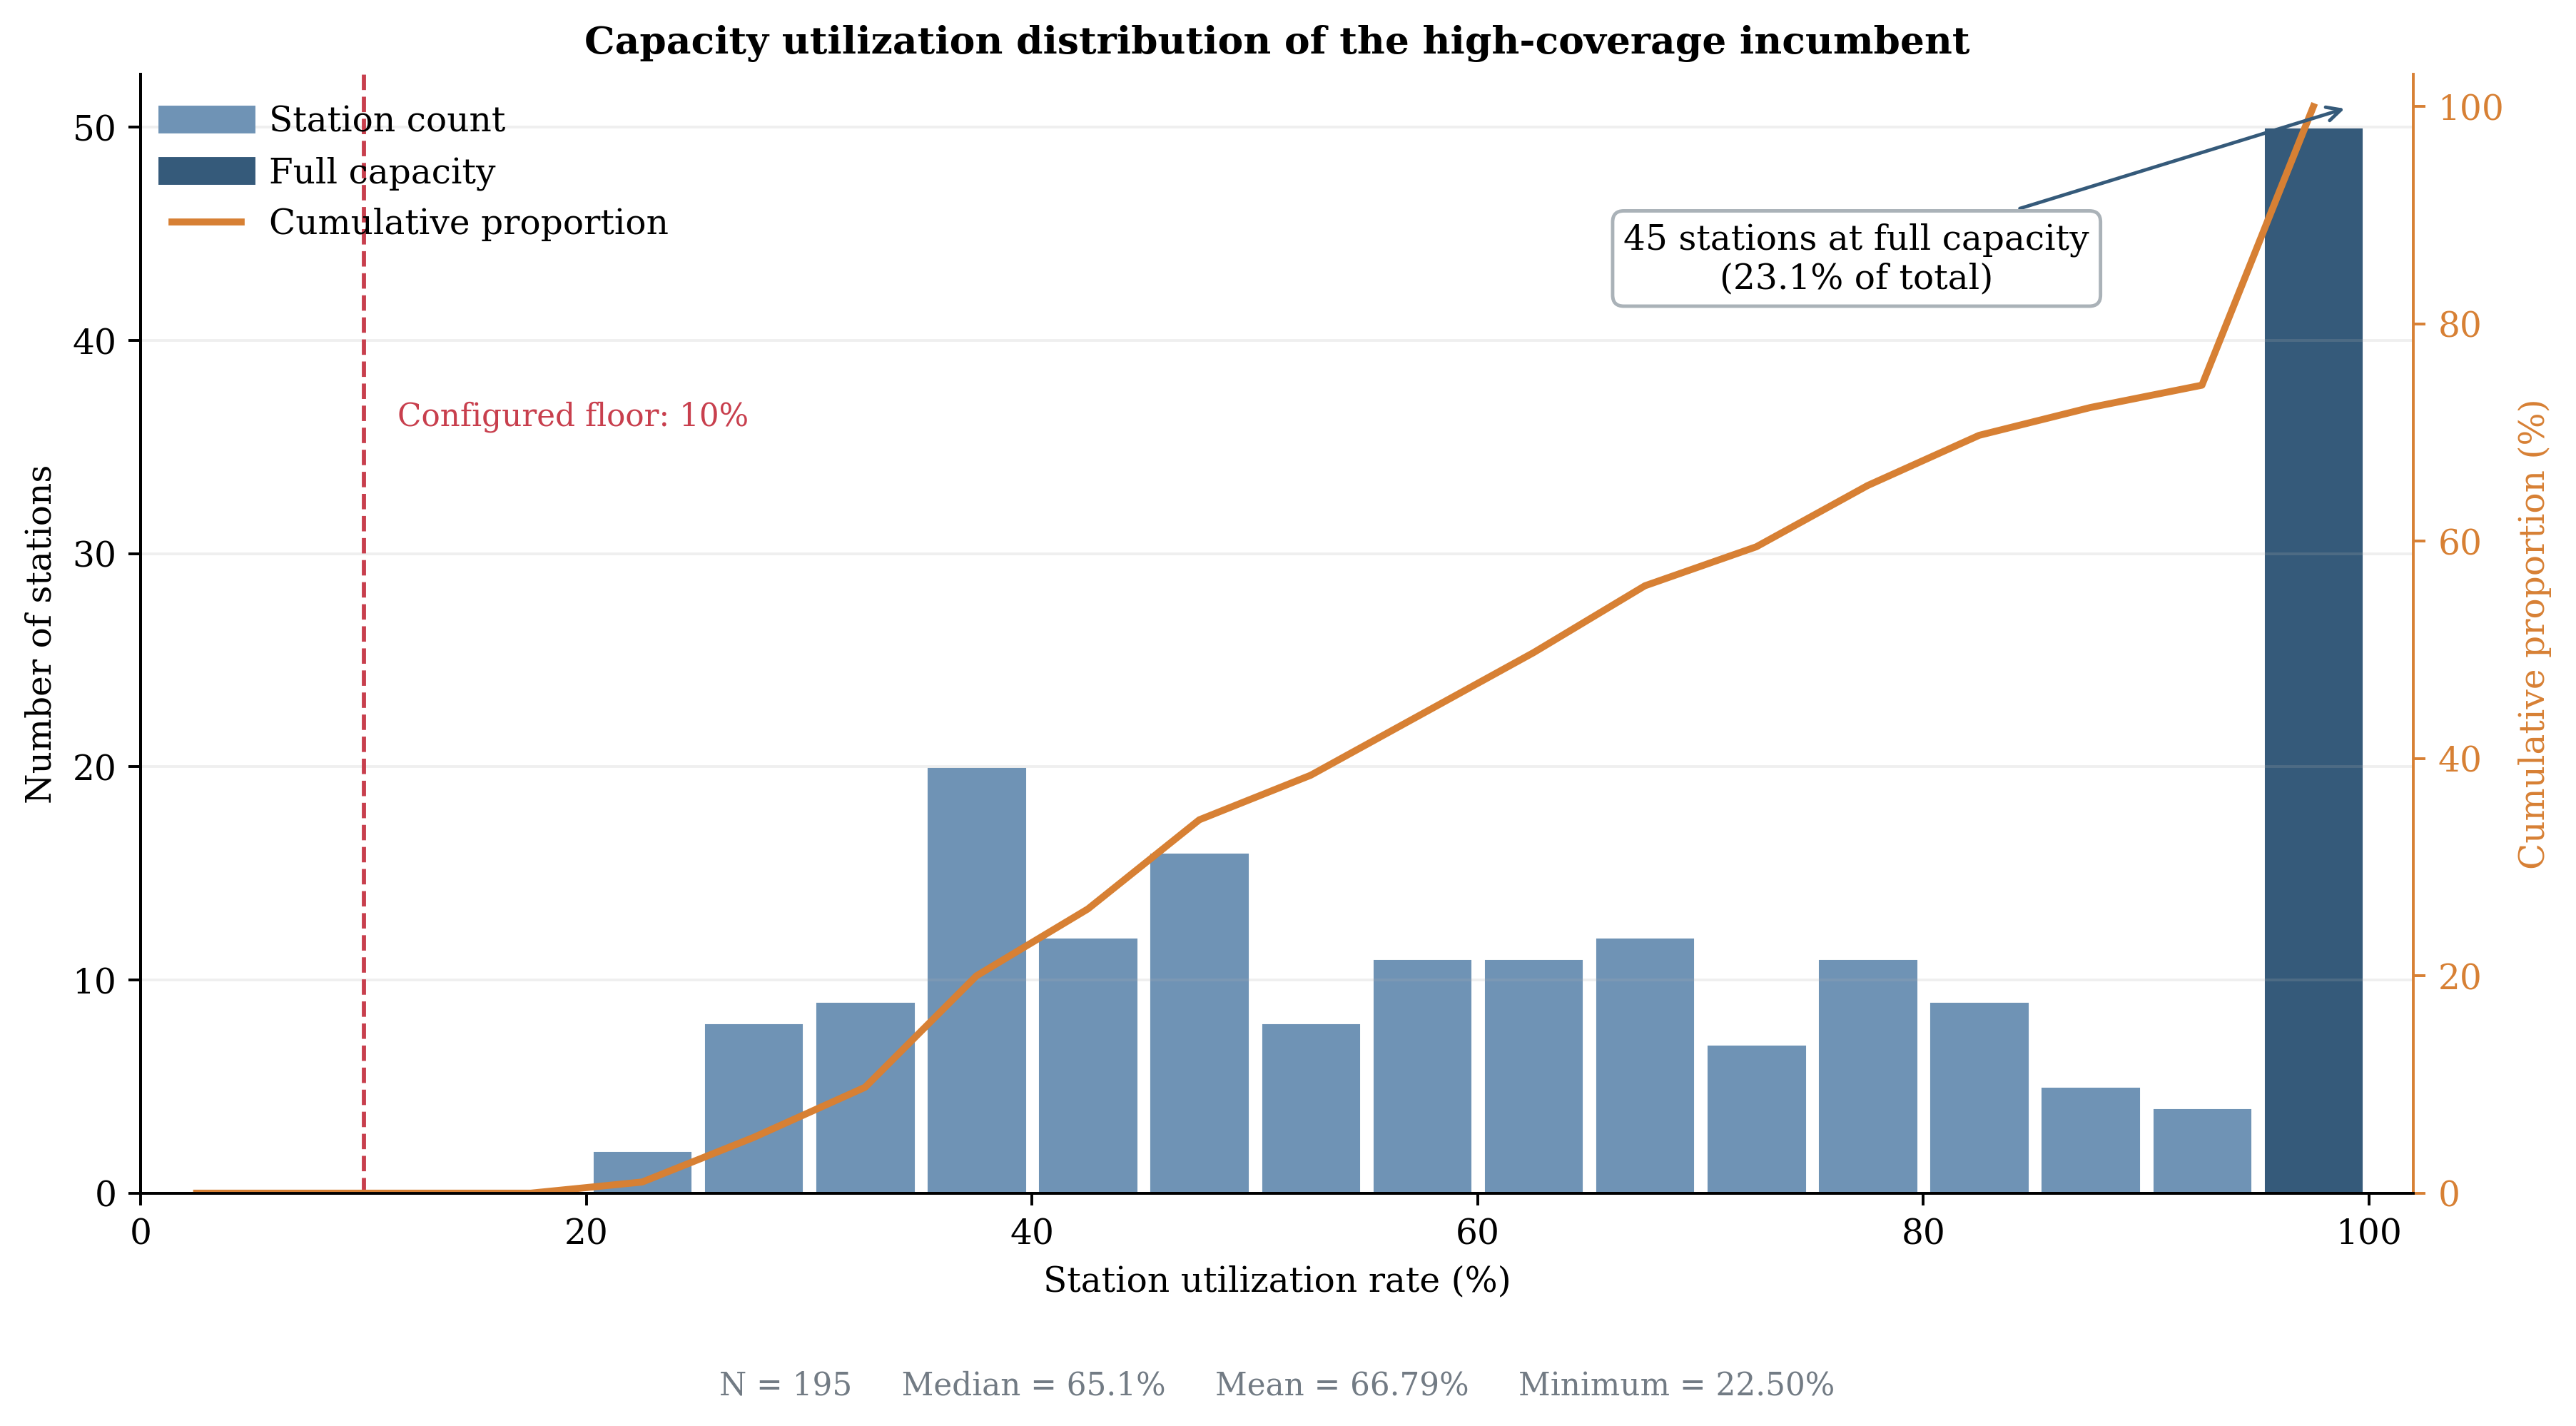
Figure 7 presents the capacity utilization rate distribution across all opened stations under the high-coverage scenario. All stations satisfy the utilization floor constraint, confirming that the model effectively prevents asset idleness. Forty-five of the 195 opened stations operate at full throughput capacity (23.1%), reflecting genuine binding capacity constraints in the urban core. Average utilization is 66.79%, minimum utilization is 22.50%, and all stations remain above the configured 10% floor. The bimodal character of the distribution, many stations at or near full capacity, fewer at intermediate levels, and a small cluster near the floor, is structurally consistent with the city’s demand heterogeneity.
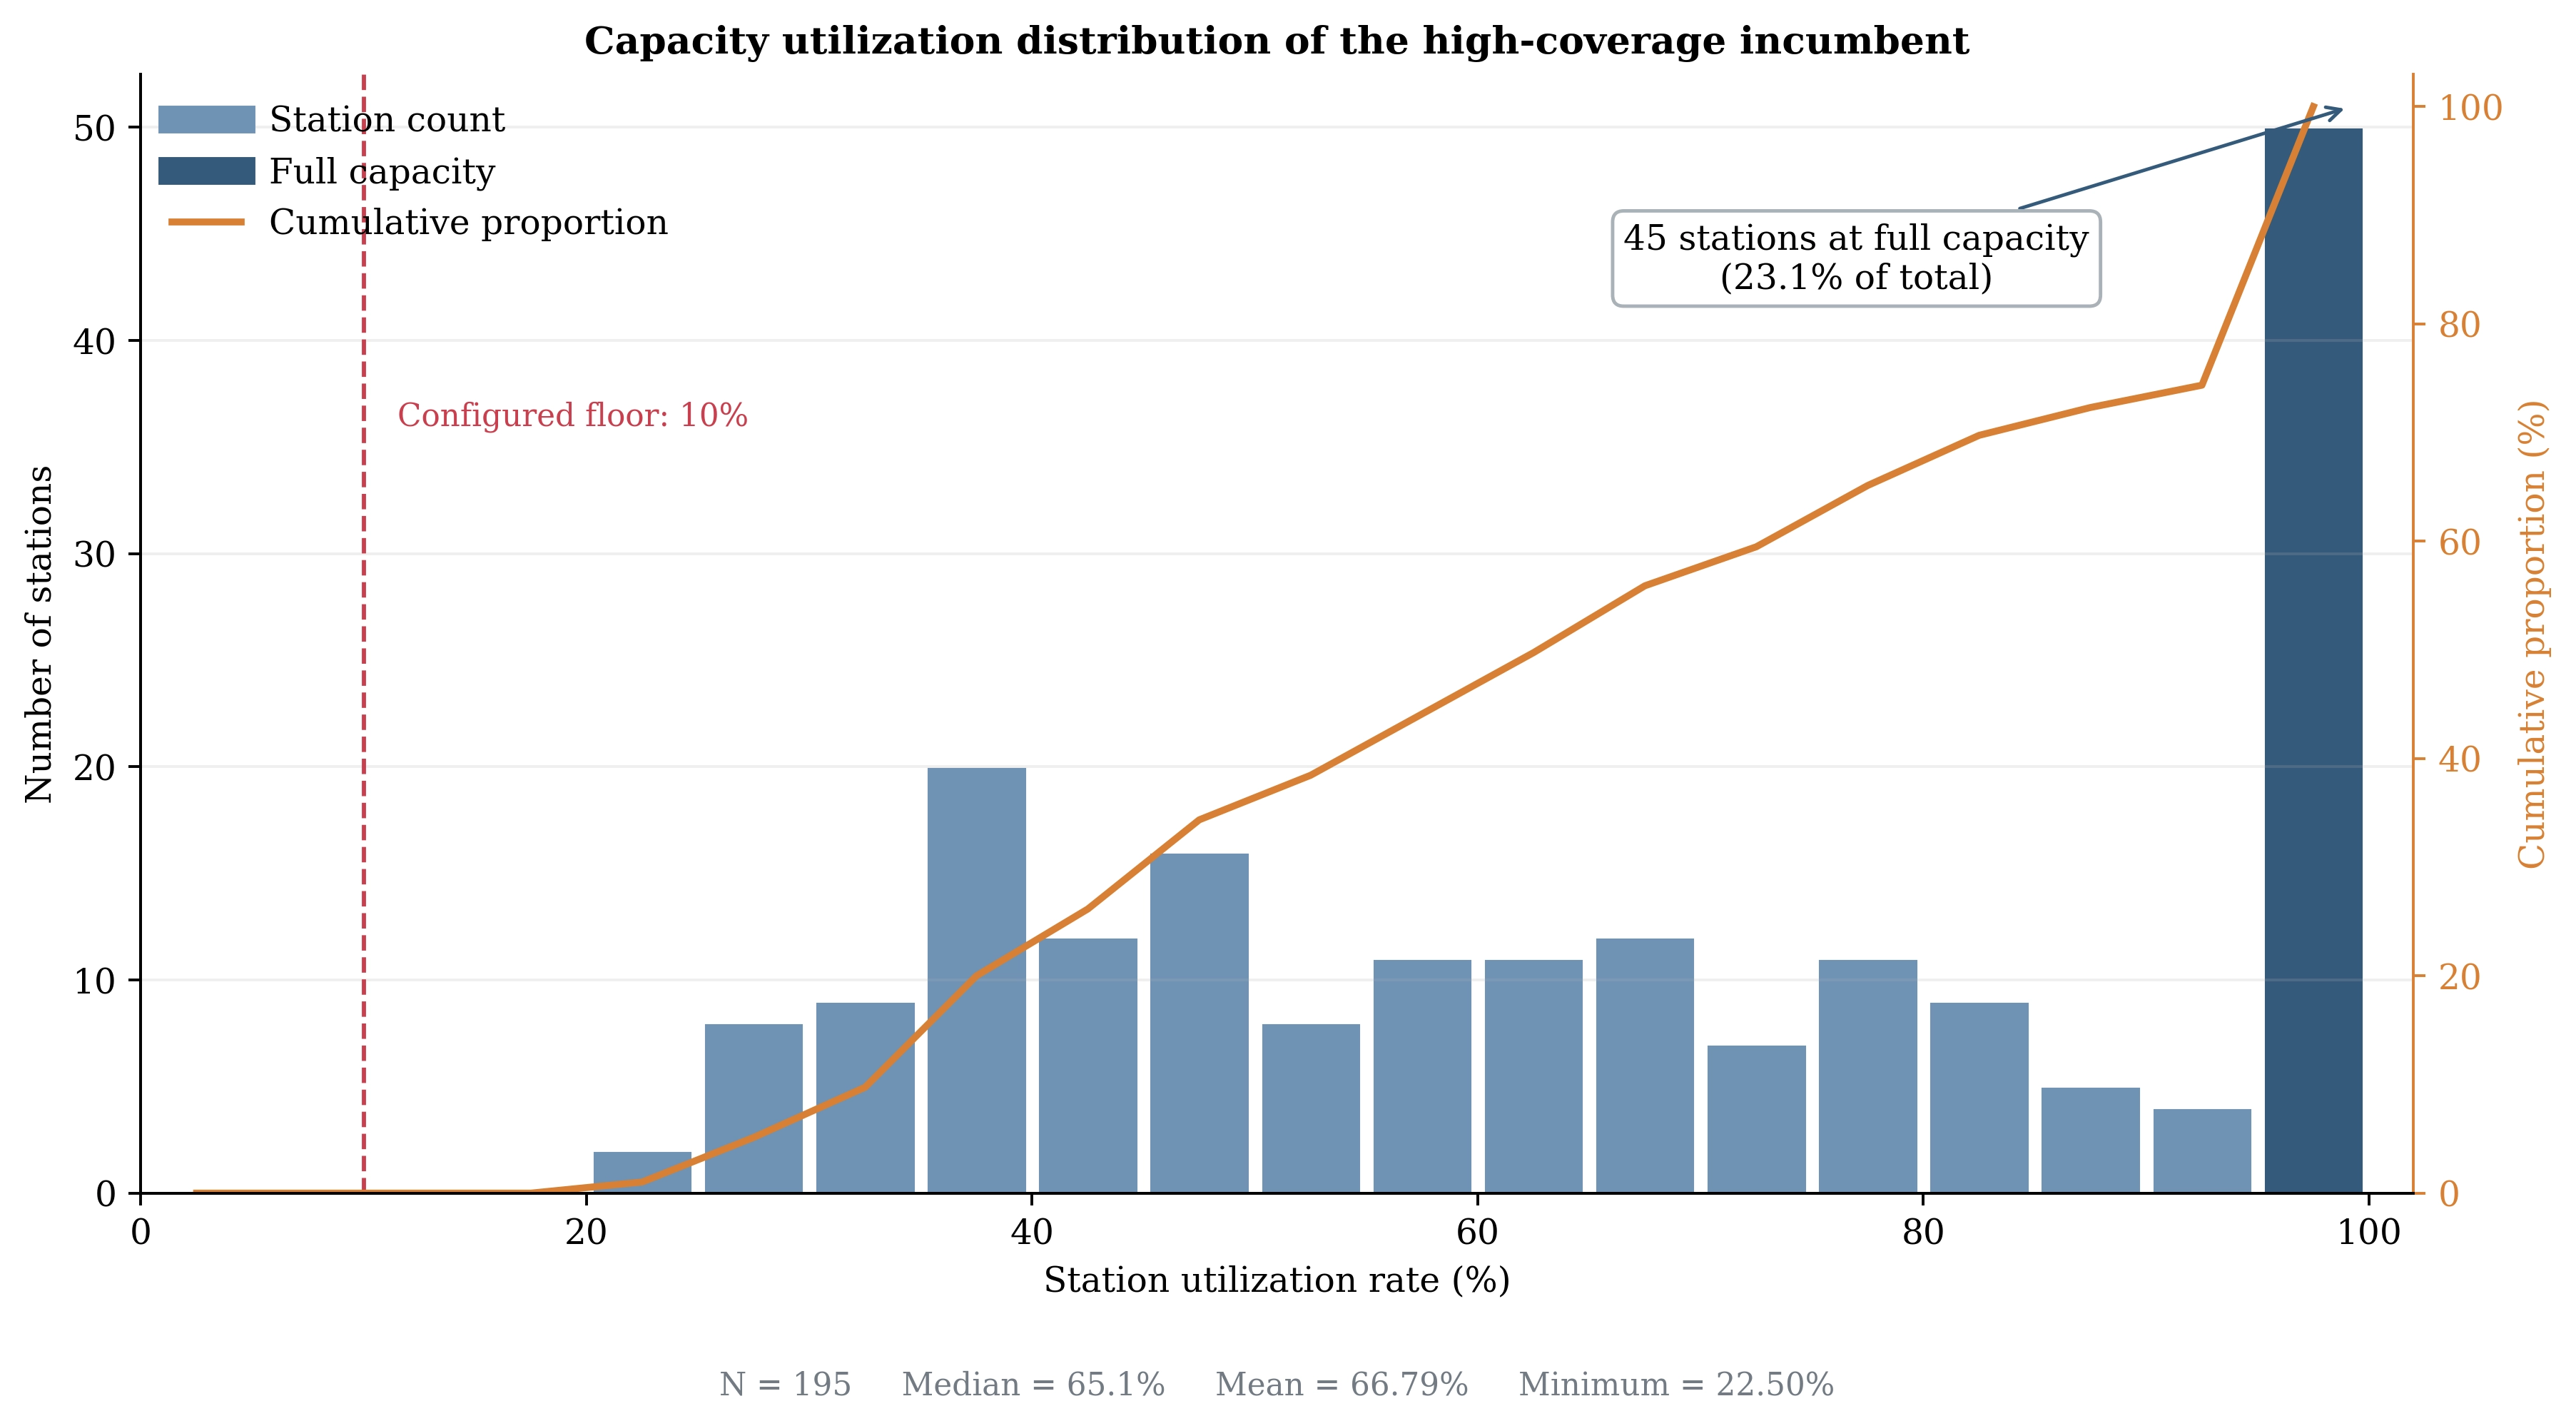
Figure 7. Capacity utilization rate distribution across all opened stations (high-coverage scenario).
3.3.2 Station selection pattern and spatial annotation
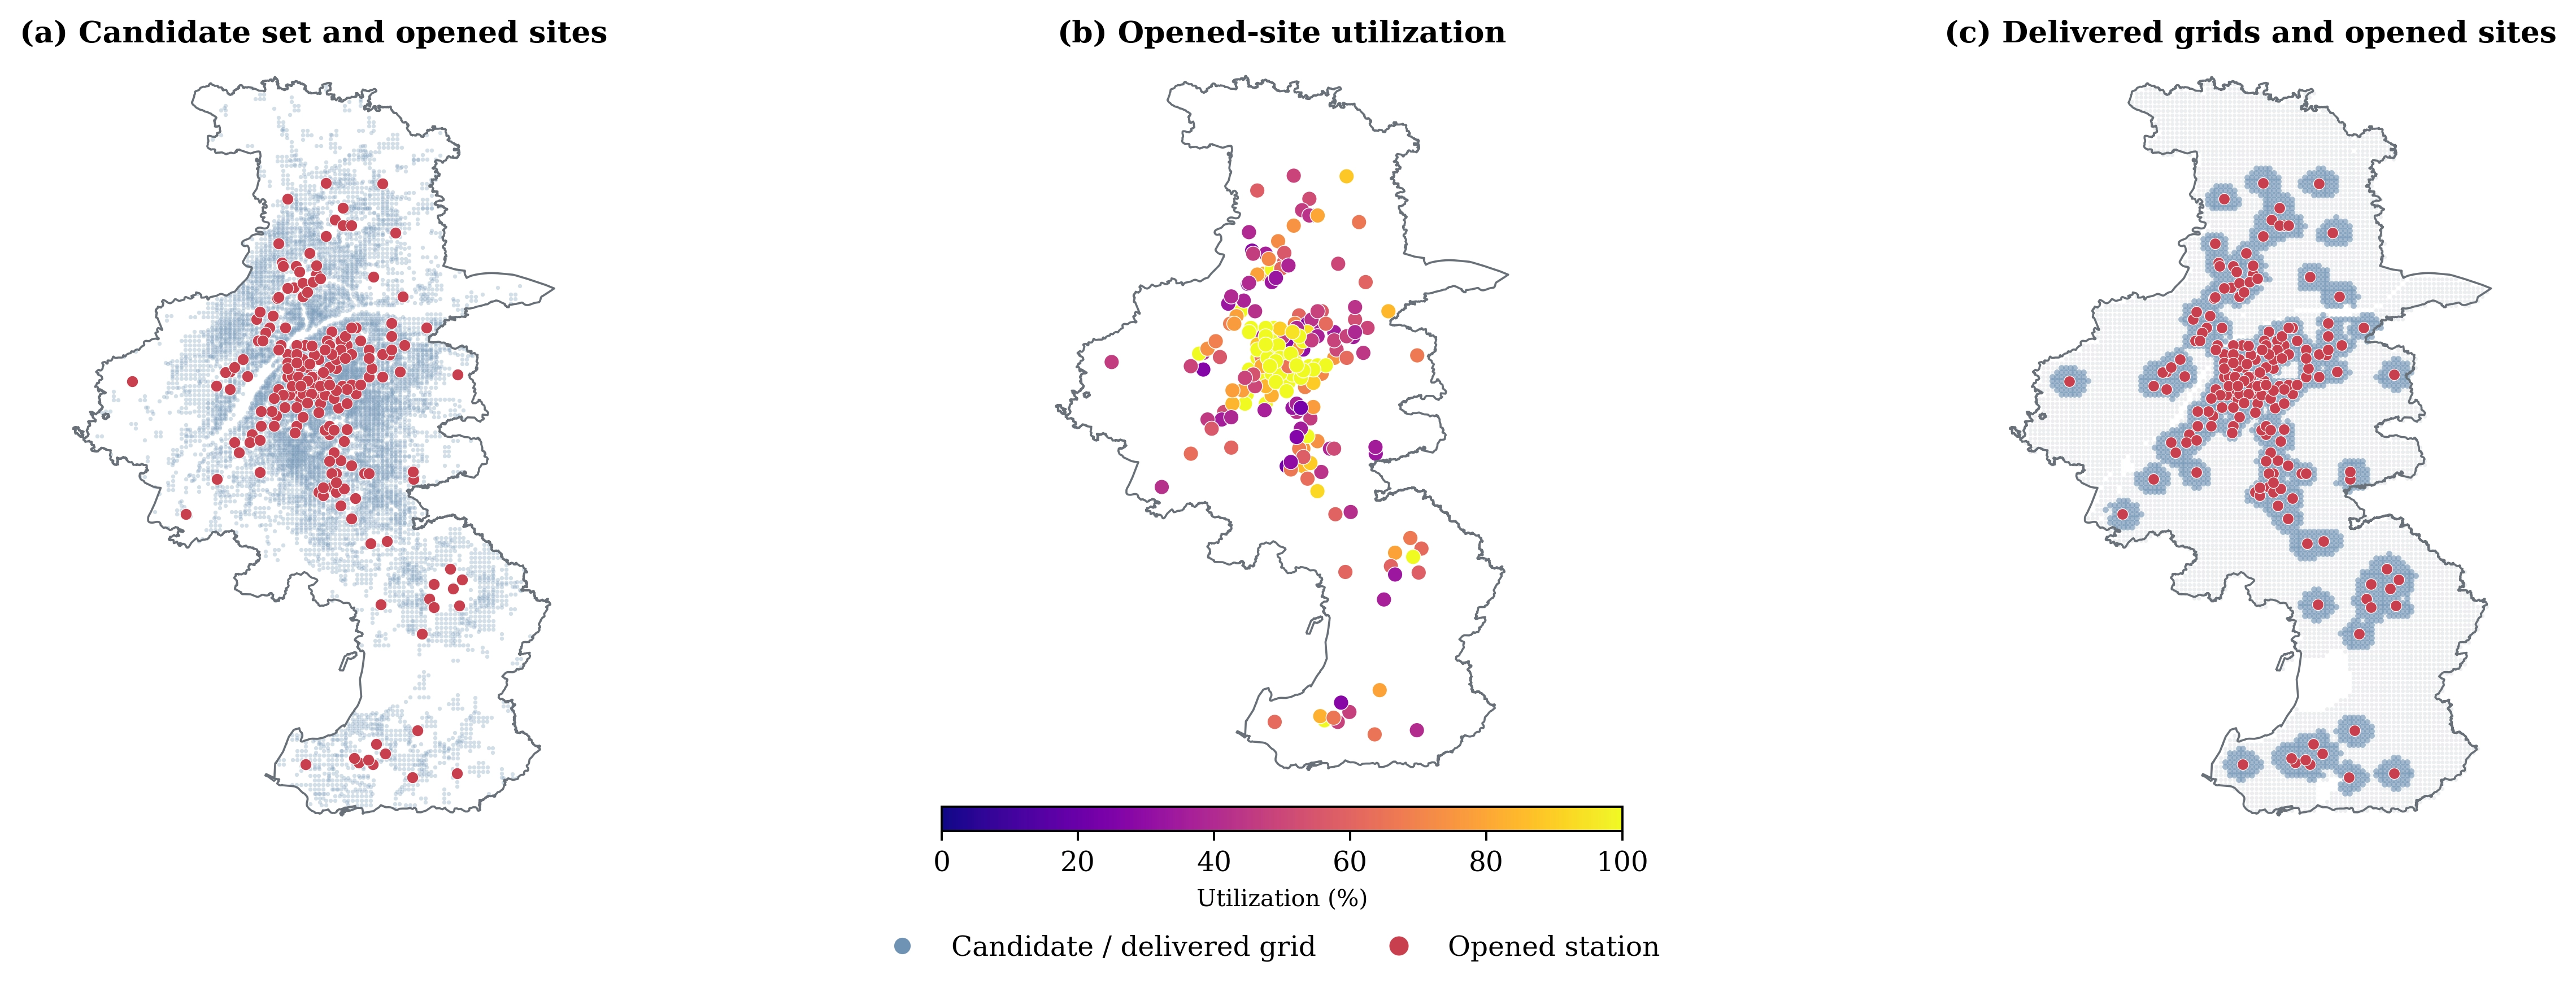
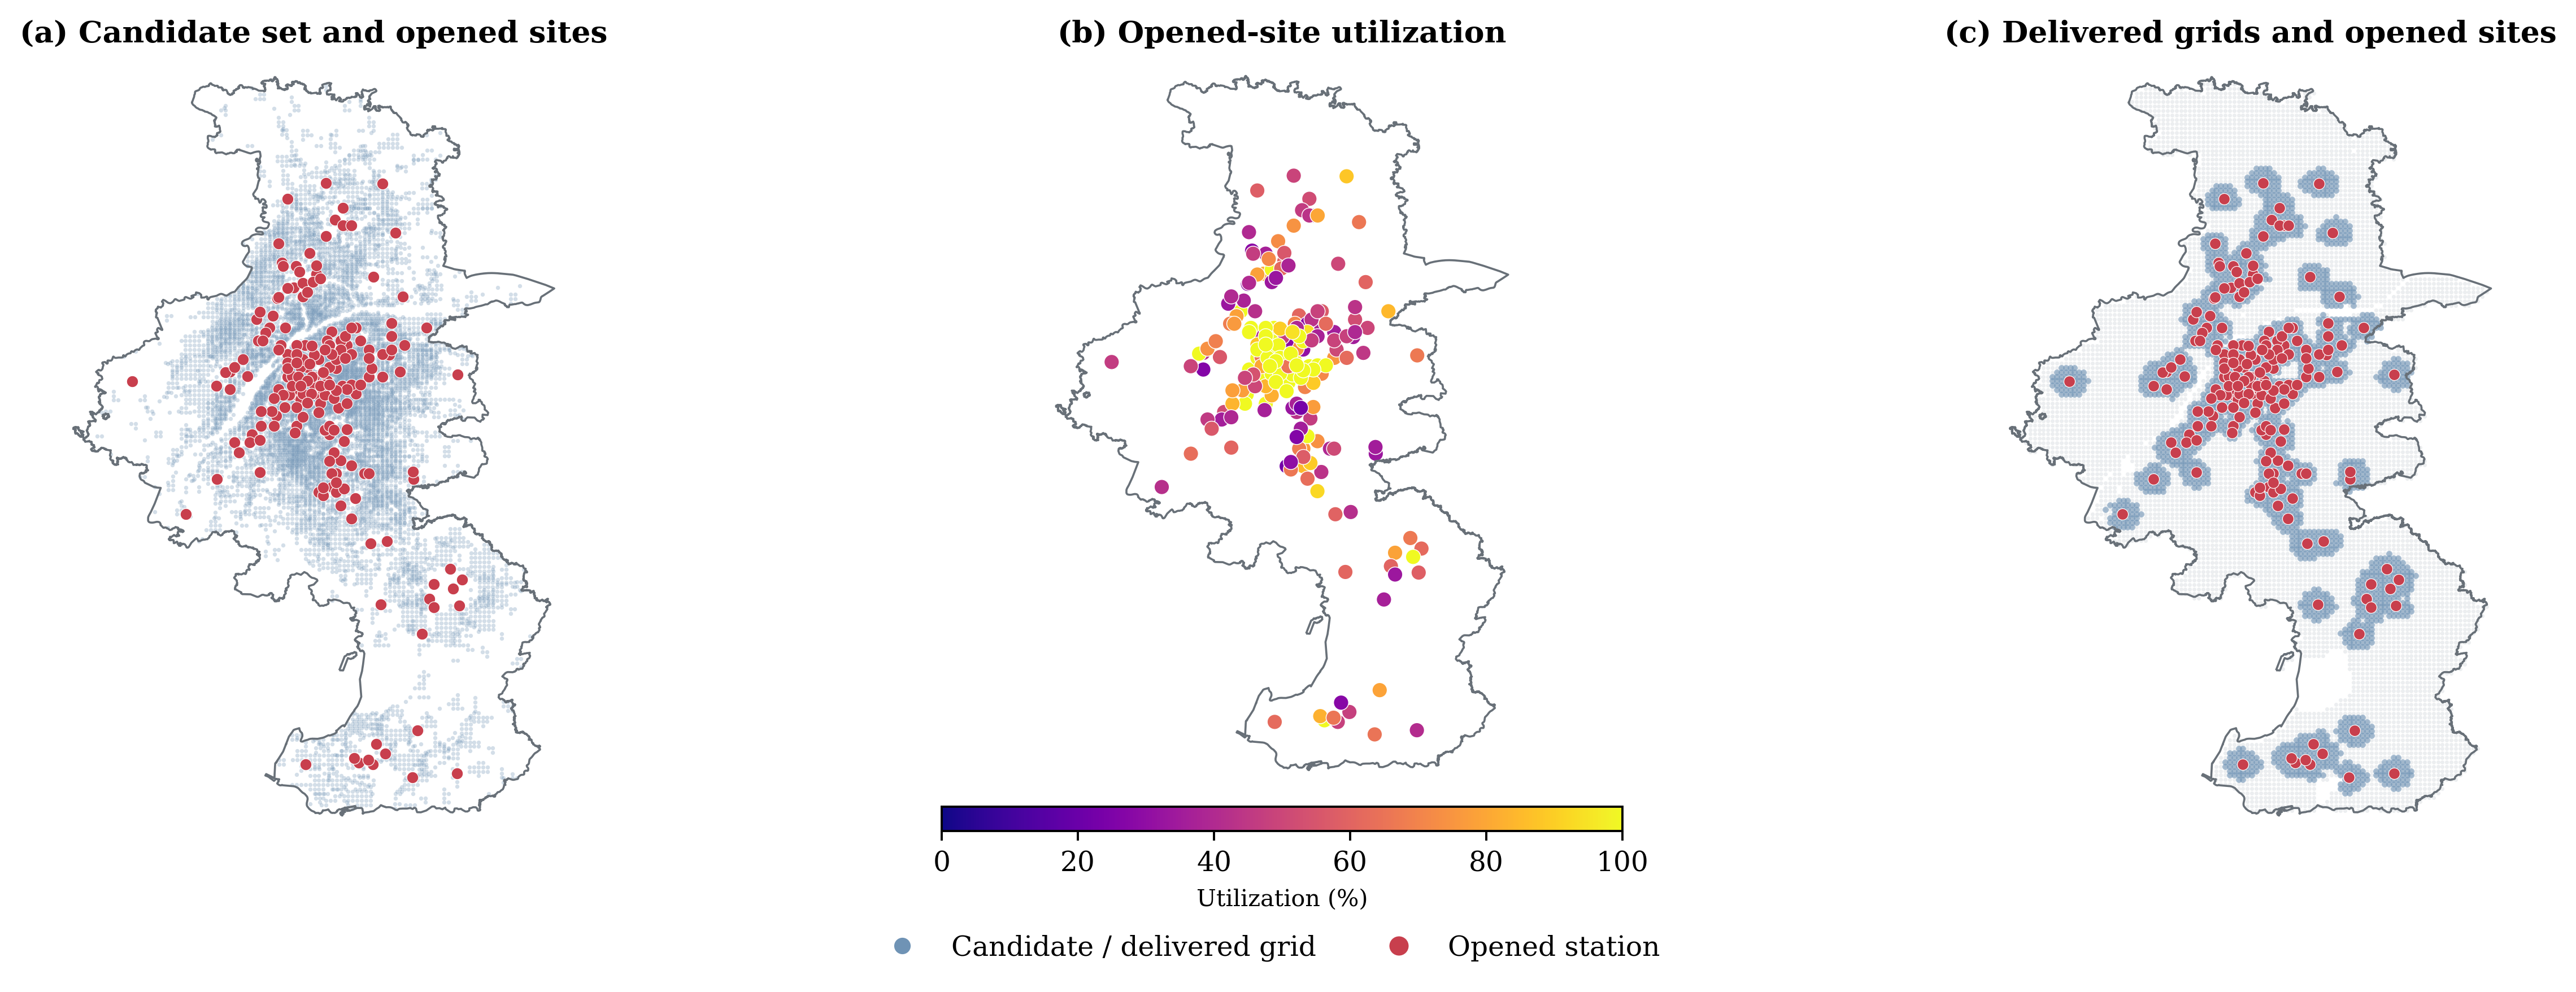
Figure 8 places the 195 opened stations within the full candidate set. Selection remains concentrated along the main urbanized corridor, with additional sites in secondary clusters where multiple grids can be aggregated within the 8 km radius. These are model-selected planning sites and have not passed building-level engineering approval.
3.3.3 Capacity crowding-out effect in the urban core
The urban core of Nanjing (Xinjiekou, Hexi central business district (CBD), Fuzimiao-old city south) exhibits high population density and commercial agglomeration, with single-grid daily demand frequently exceeding several hundred orders. Under the hard throughput ceiling C = 1,200 orders/day, this zone generates a pronounced capacity crowding-out effect: no single station can absorb the concentrated surrounding orders, compelling the model to deploy stations densely to distribute load. Each station typically serves 4-7 demand grids, with some reaching capacity while serving only 2-3 high-demand grids. This dense multi-station deployment emerges organically from the capacity constraints, without any explicit spatial density parameter, demonstrating that the model’s response to high-demand concentration is structurally demand-driven.
3.3.4 Aggregation coverage strategy in outer suburbs
In the outer suburban zones (Luhe, Gaochun, Lishui, parts of Jiangning), demand exhibits a pronounced long-tail distribution. Establishing stations at urban-core density would result in per-station volumes failing to reach the utilization floor αC, causing heavy-asset idleness. The model therefore adopts an emergent aggregation coverage strategy: sparse station deployment with extended effective coverage, integrating fragmented demand from 15-26 grids per station to accumulate total delivery volumes above αC. This contrasts sharply with the 4-7 grids-per-station pattern in the urban core, demonstrating the CFLP model’s fidelity to the “build only where commercially viable” constraint.
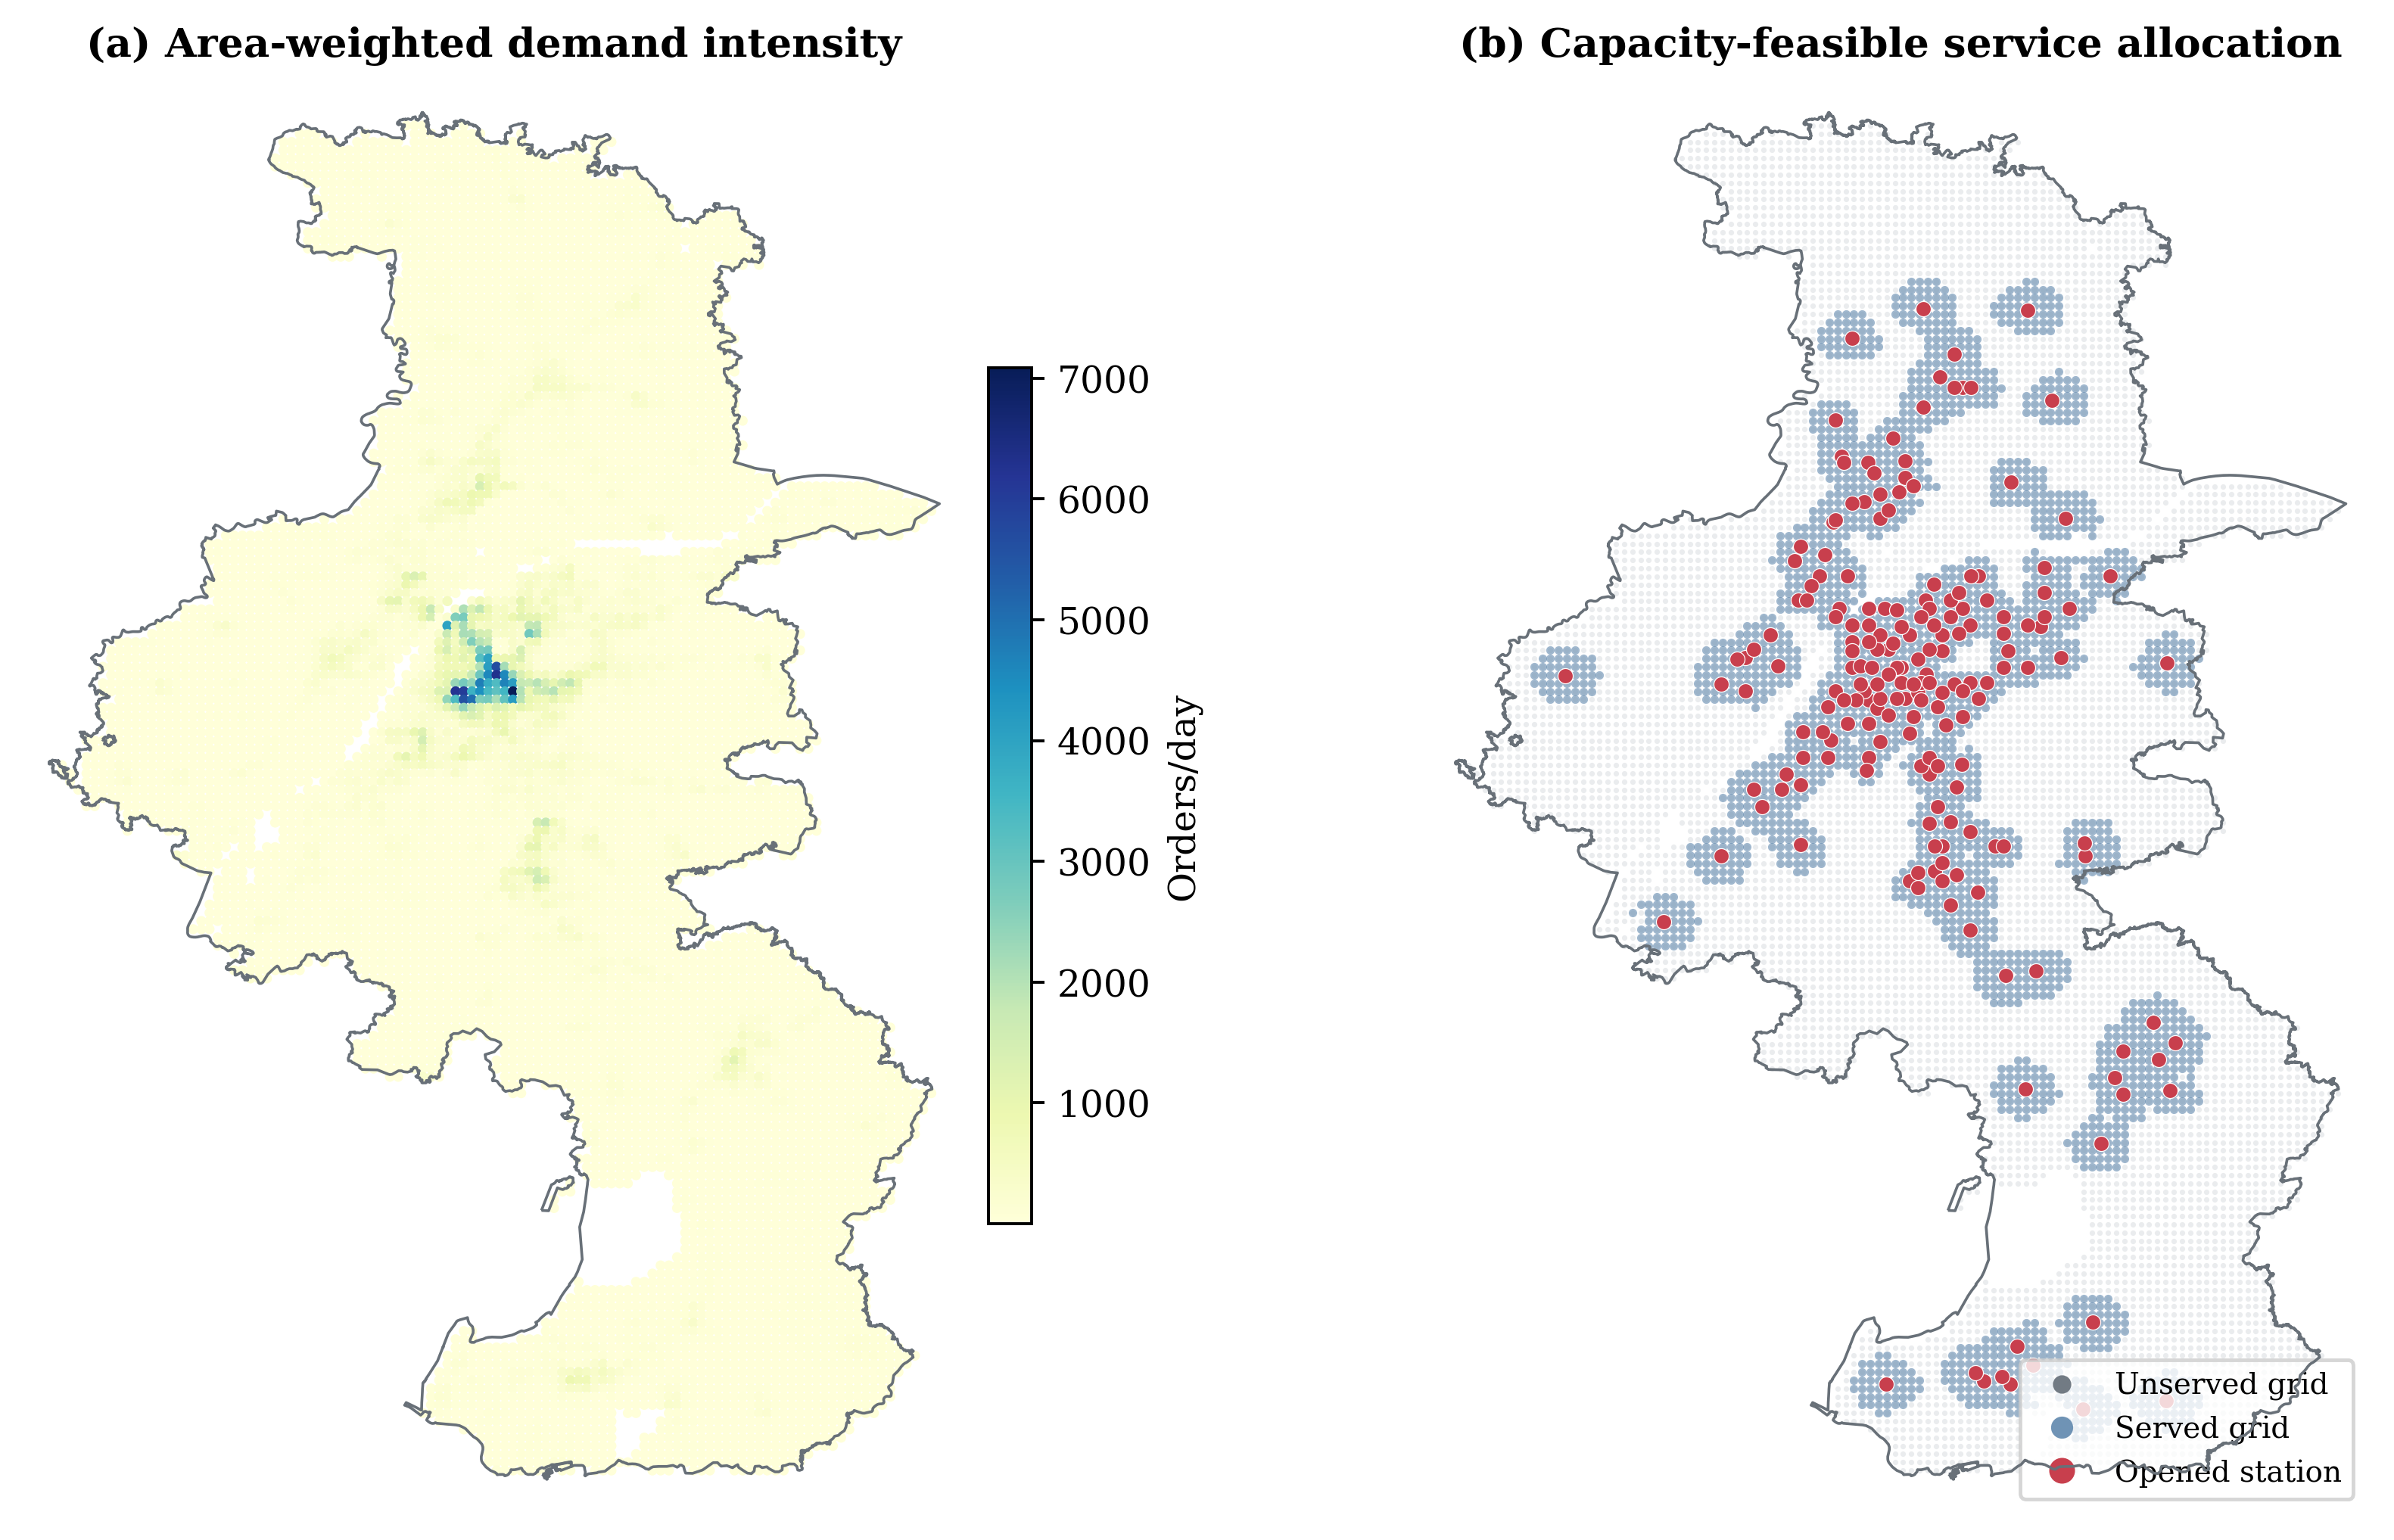
3.3.5 Spatial coupling of demand, location, and allocation
Figure 9 presents the demand distribution alongside the delivery allocation results, enabling direct visual comparison of the spatial coupling between demand, opened stations, and served grids. The overall pattern exhibits a clear dual spatial logic: dense, capacity-saturated station deployment in the high-demand urban core, contrasted with sparse, aggregation-oriented deployment in the low-demand outer suburbs. This pattern closely aligns with Nanjing’s macroscopic “main city-sub-cities-new towns” spatial hierarchy. Some high-demand grids remain unserved due to binding capacity constraints or service radius exceedance; some outer suburban grids are served as part of the aggregation strategy. These mechanisms together demonstrate the model’s ability to achieve dynamic spatial supply-demand balance across heterogeneous urban morphologies. Notably, this dual spatial logic is not an artifact of parameter tuning but an emergent structural property of the CFLP formulation itself: the capacity ceiling creates crowding-out pressure in high-demand zones, while the utilization floor forces aggregation in low-demand zones. The model thus self-organizes into a deployment pattern that mirrors the economic logic of real-world logistics operators, dense coverage where demand justifies investment, sparse coverage where only aggregated demand can sustain a facility.
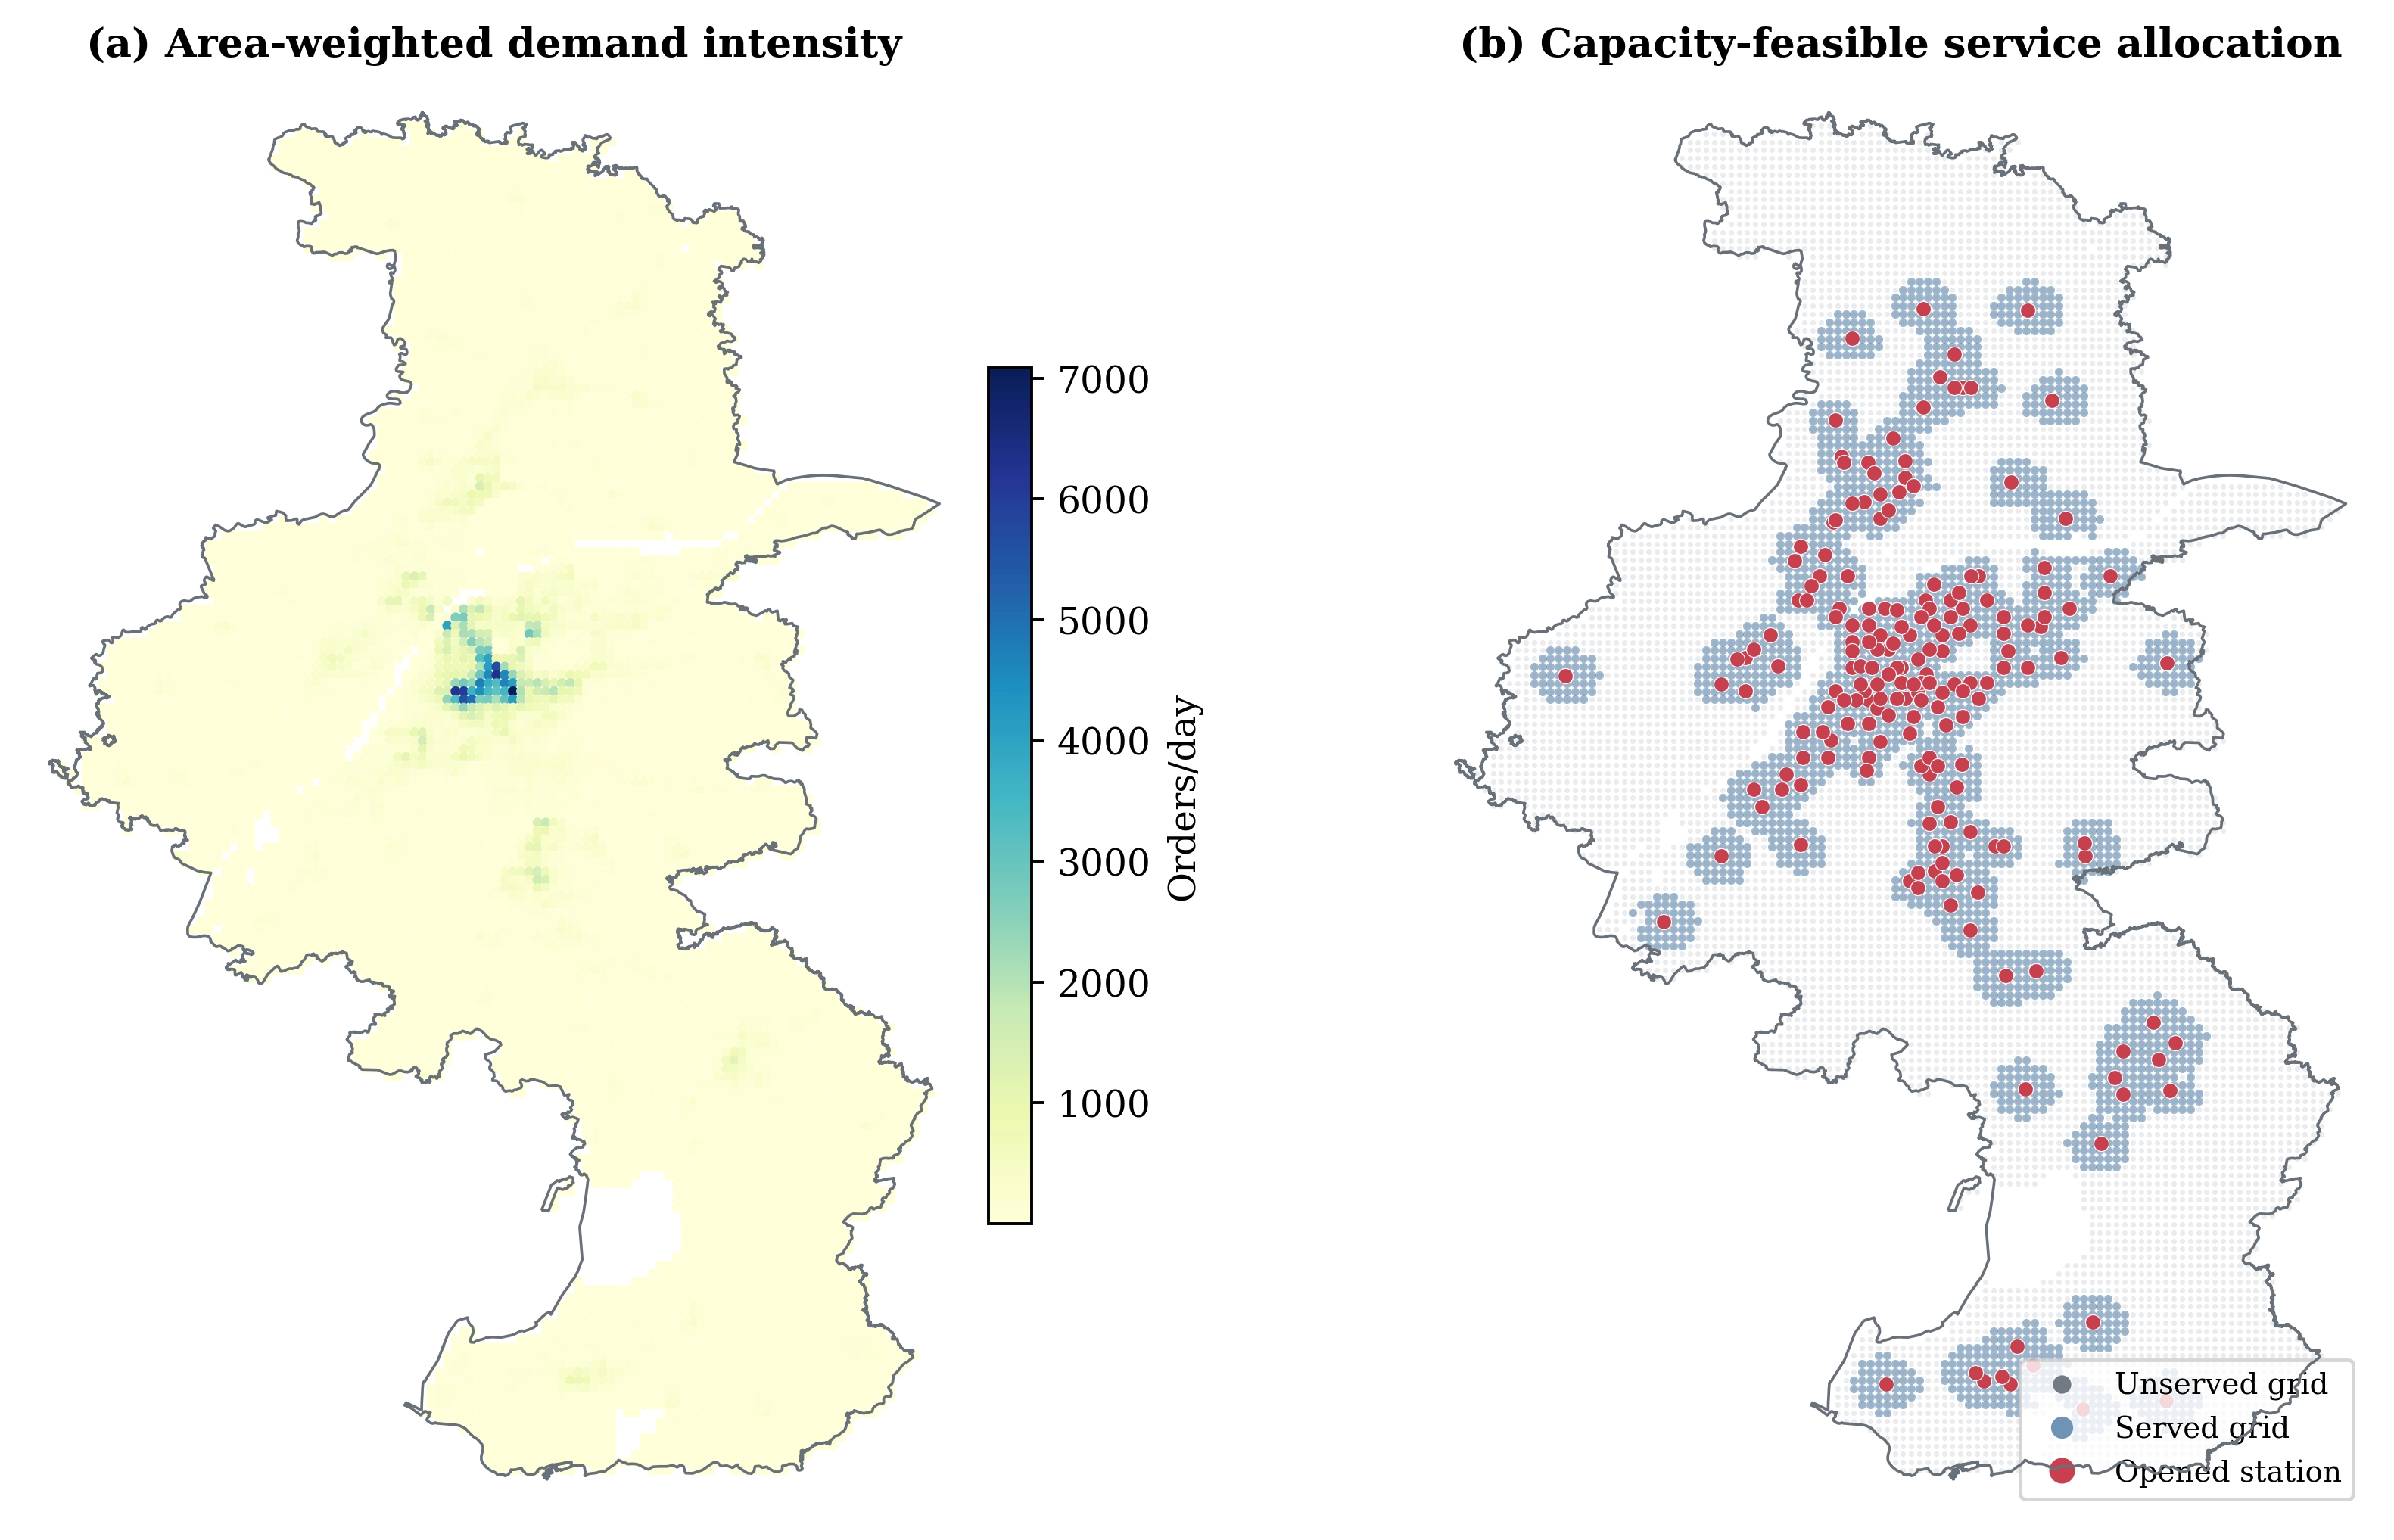
Figure 9. Demand distribution vs. delivery allocation results: spatial coupling analysis (high-coverage scenario).
3.4 Overall performance summary
Under the high-coverage scenario (αs = 200, α = 0.10): 195 stations open; total daily demand is 200,048 orders; and verified delivery is 156,300 orders (78.13%). The incumbent serves 2,578 demand grids and has a log-derived objective gap of approximately 21.9%, so it is not presented as a proven optimum.
The average delivery distance per order is 0.953 km, substantially below the 8 km service radius ceiling, indicating that the distance penalty successfully incentivizes proximate delivery assignment. The average station throughput is approximately 801 orders per day (66.79% of the ceiling C = 1,200), confirming that the network operates at high aggregate efficiency. The spatial distribution of station throughput, however, is highly bimodal: 45 stations reach full capacity, while the minimum observed utilization is 22.50%. This bimodality is a structural consequence of demand heterogeneity and validates the design logic of the CFLP framework: the capacity ceiling prevents urban-core overloading, the utilization floor prevents suburban under-utilization, and the distance penalty ensures that demand is allocated efficiently between the two regimes. Together, these constraints produce a network that is simultaneously capacity-feasible, commercially viable, and spatially responsive, properties that no single constraint could achieve in isolation.
3.5 Multi-scenario comparative analysis
Table 4 compares three scenarios spanning the realistic policy design space for urban low-altitude logistics infrastructure.
Table 4. Multi-scenario parameters and results.
| Scenario | αs | α | Coverage Bonus | Stations | Delivery | Coverage Rate | Coverage Characteristic |
| Baseline | 500 | 0.15 | 0 | 59 | 70,633 | 35.31% | Compact high-utilization network |
| High-coverage | 200 | 0.10 | 0 | 195 | 156,300 | 78.13% | Broader capacity-feasible service |
| Wide-coverage | 100 | 0.05 | 40 | 195 | 156,300 | 78.13% | Warm-start incumbent; no verified improvement |
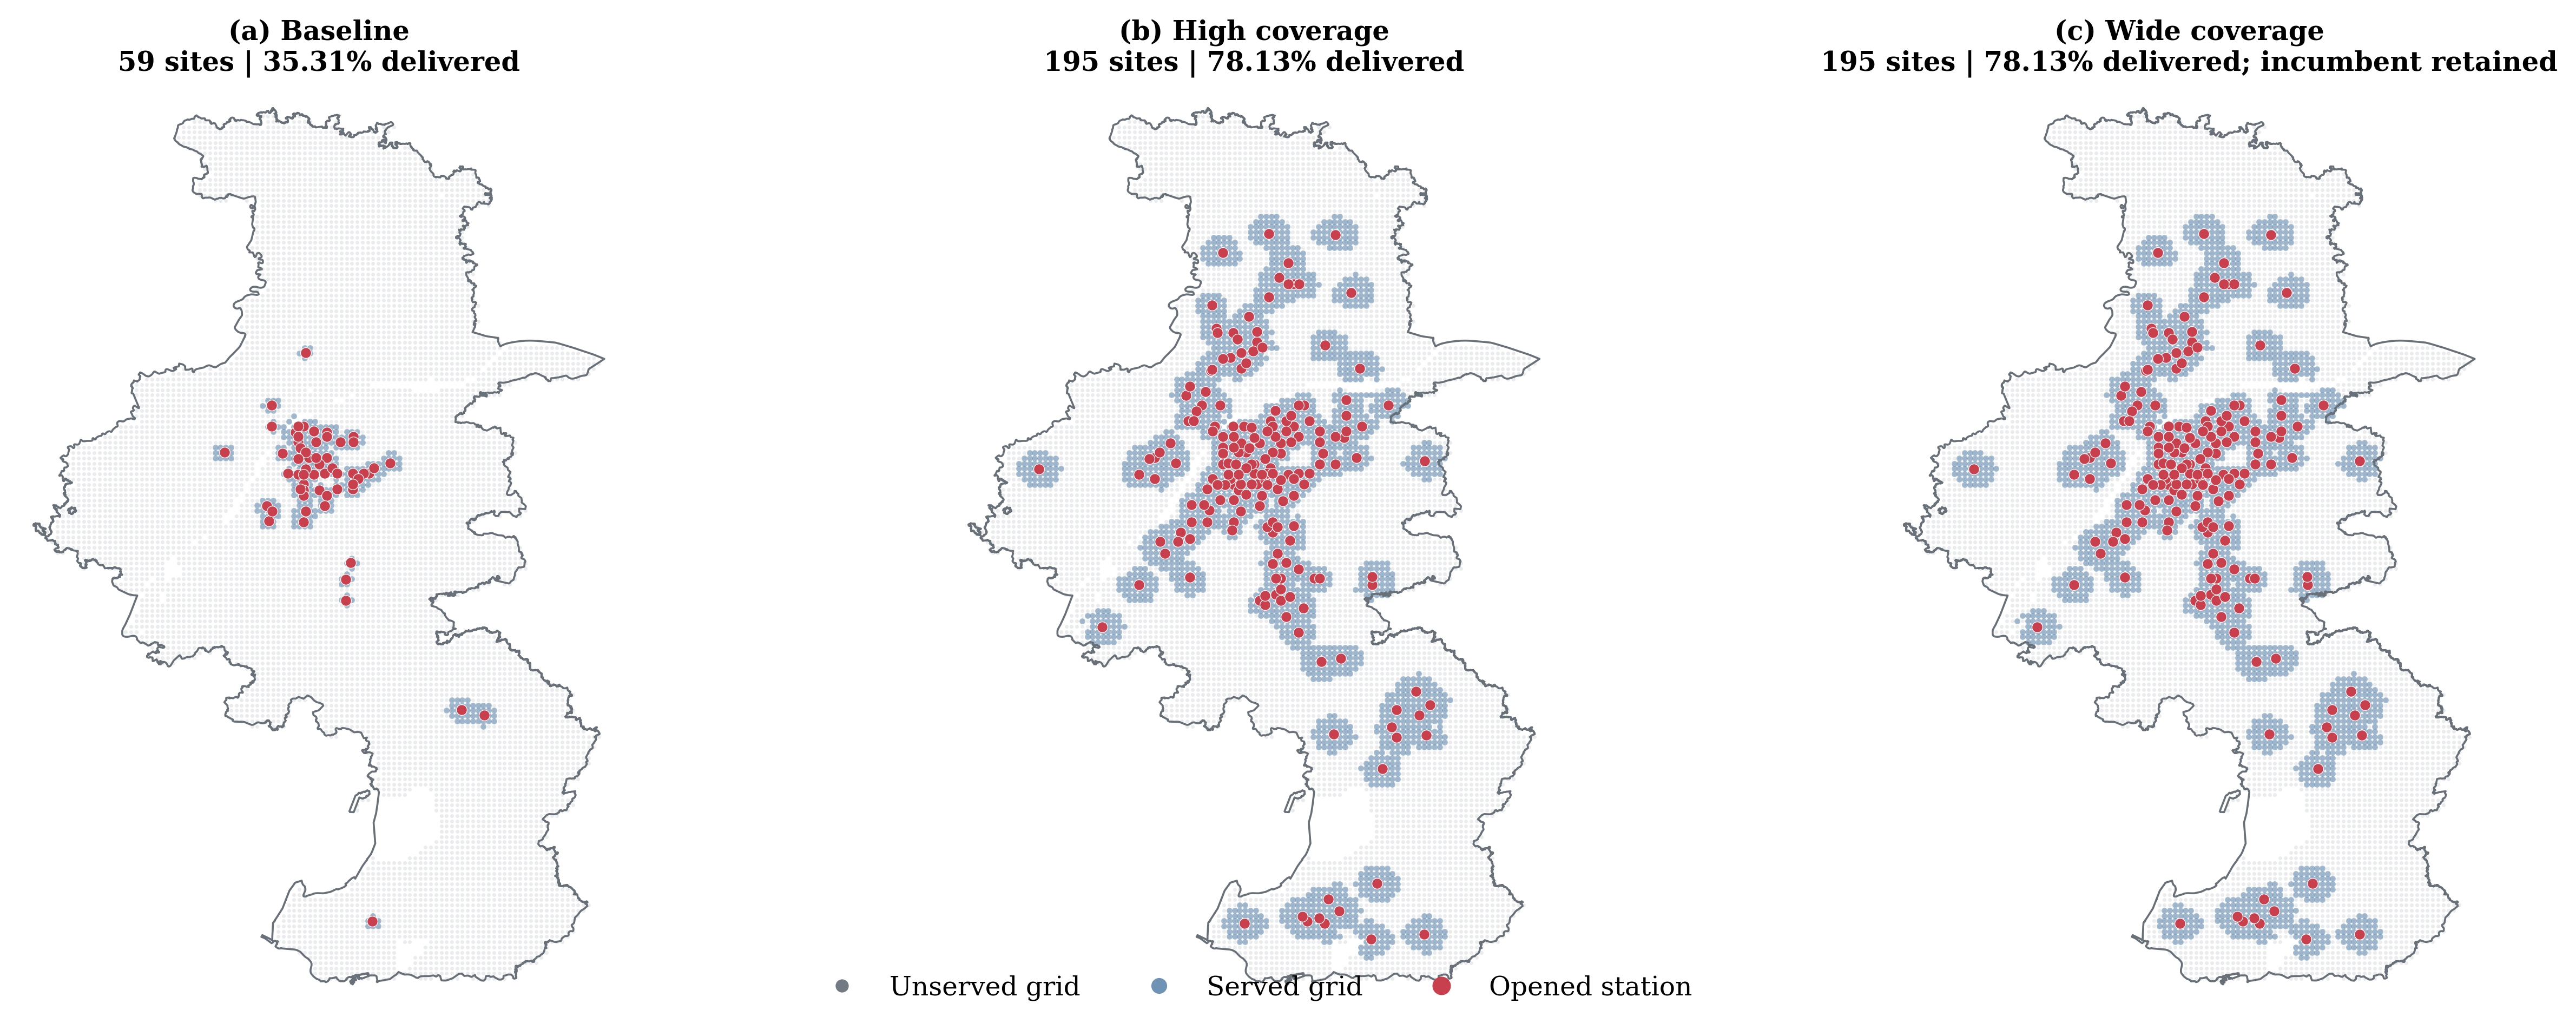
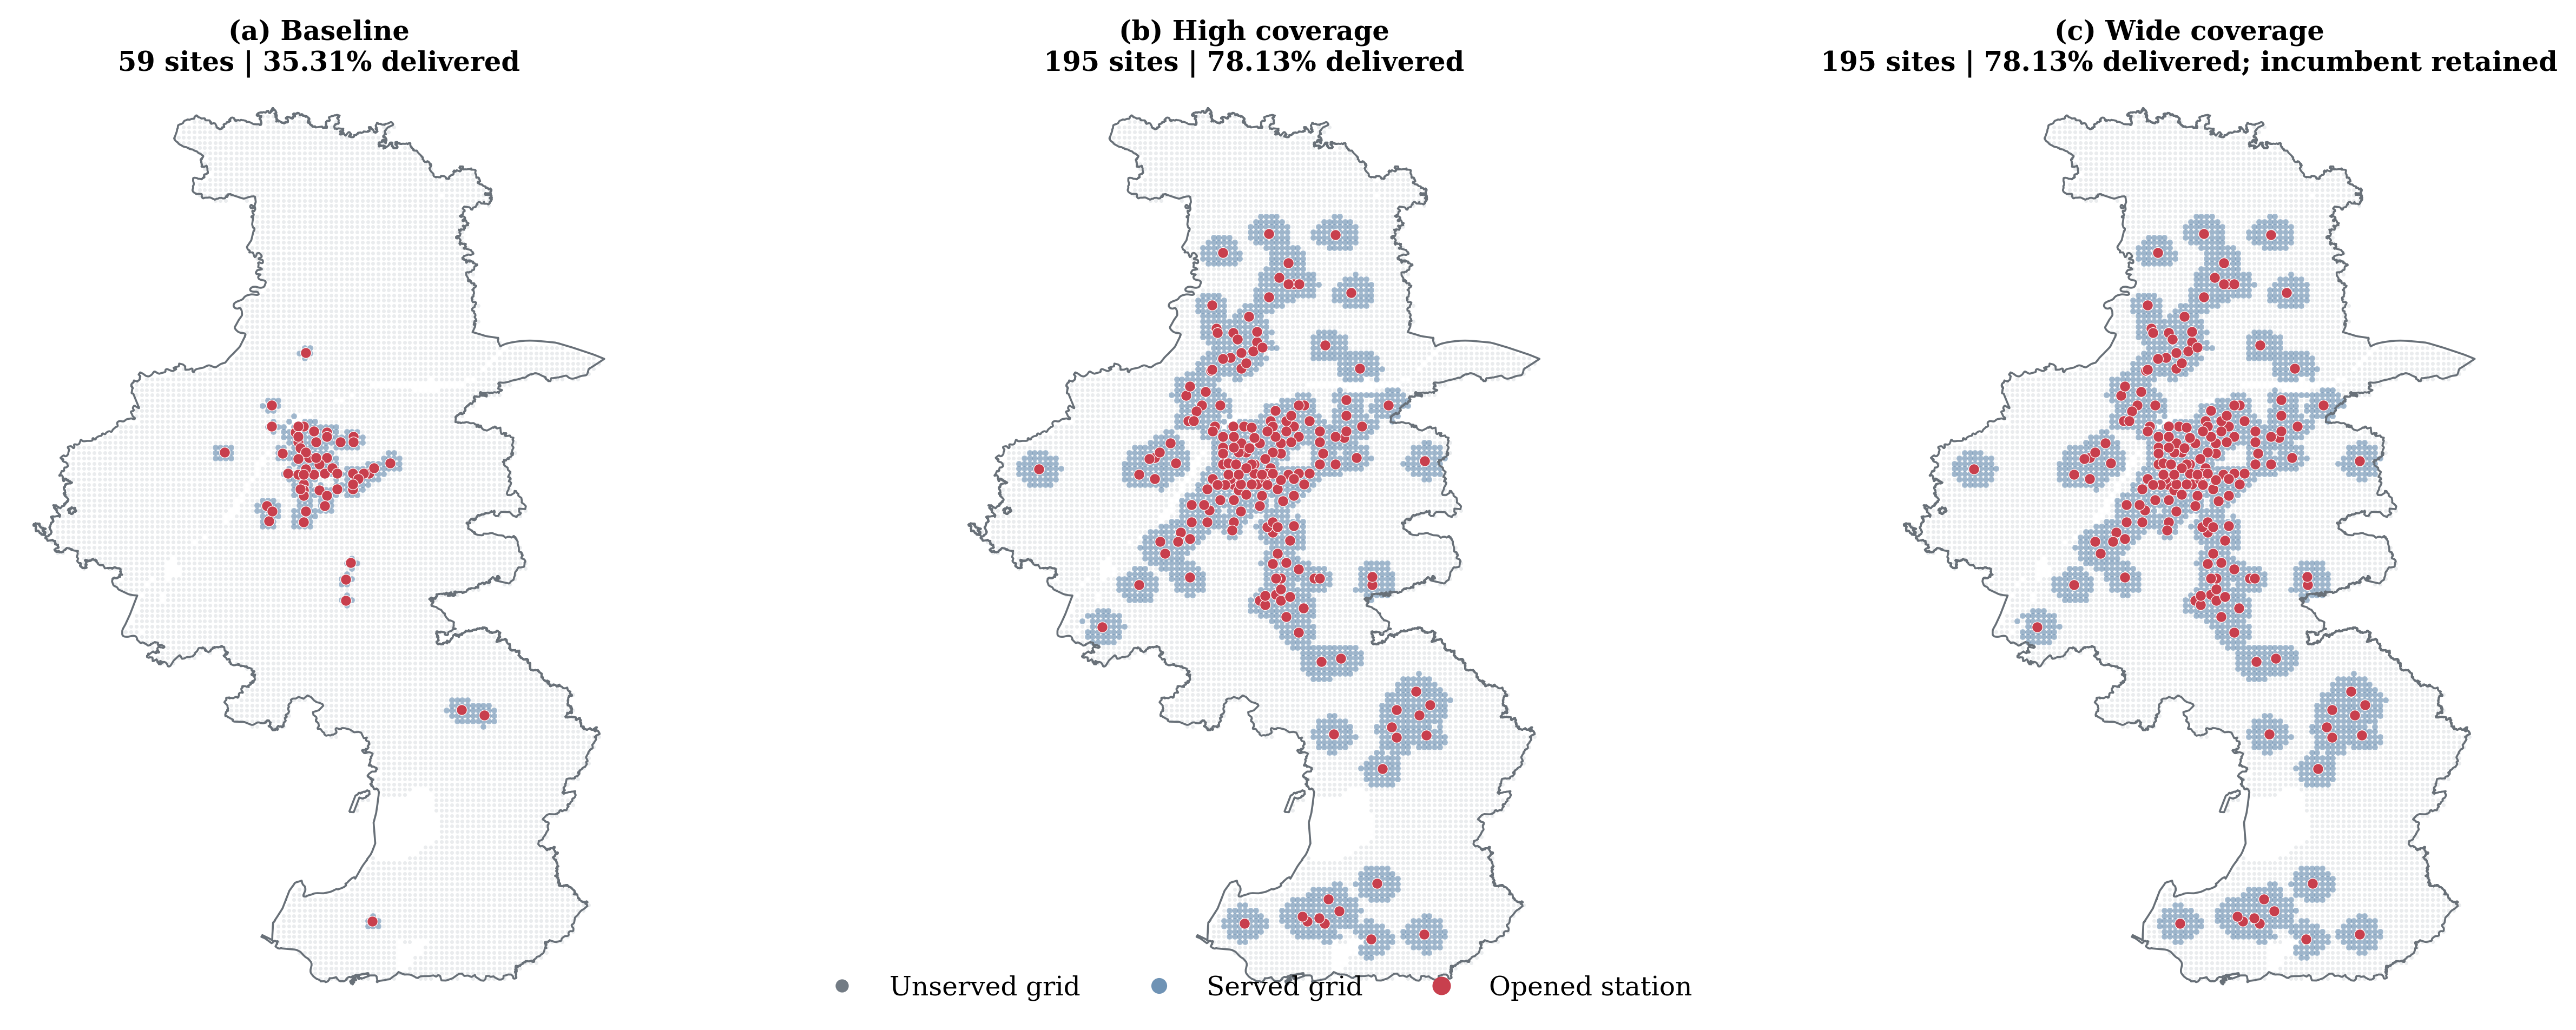
The baseline scenario (αs = 500, α = 0.15) represents a market-only equilibrium: 59 stations, all concentrated in the highest-demand zones, achieving 35.31% delivery with a total delivery volume of 70,633 orders per day. This scenario reflects a purely commercial operator’s reported feasible network when no subsidies or coverage mandates exist, the model opens stations only where the marginal revenue from deliveries exceeds the daily amortized establishment cost, producing a compact, high-utilization network confined to the urban core.
The high-coverage scenario (αs = 200, α = 0.10) relaxes both the establishment penalty and utilization floor, raising station count to 195 and delivery to 78.13%, or 156,300 orders per day. The transition from baseline to high-coverage adds 136 stations and increases delivery by 42.82 percentage points, approximately 3.18 additional stations per percentage point in this incumbent comparison. This scenario represents the effect of capital subsidies or reduced land lease costs: when daily fixed costs per station are lowered (e.g., through government co-investment in vertiport infrastructure), stations that were previously below the break-even threshold become viable. Because the objective coefficients are normalized, the subsidy interpretation requires local monetary calibration.
The wide-coverage formulation uses a station penalty of 100, a 0.05 utilization floor, and a coverage bonus linked to at least 50% delivery of a grid demand. Within the 300 s budget, CBC retained the 195-site high-coverage warm start and did not verify an improved integer solution. The manuscript therefore does not claim an additional equity gain from this run.
Critically, all three scenarios are generated by the same model with different parameter settings, no structural changes to the MILP are required, making the framework directly usable as a policy simulation tool.
Figure 10 presents the spatial allocation maps of the three scenarios side by side, enabling direct visual comparison of station density, service coverage extent, and spatial deployment strategy. Under the baseline scenario (panel a), 59 stations are concentrated in the highest-demand urban core with compact service radii, serving only 407 grids and leaving the vast suburban and exurban areas entirely unserved. The high-coverage scenario (panel b) raises the station count to 195, extending the service footprint from the core into the secondary demand belt along the Jiangbei New Area and Jiangning district, while maintaining tight capacity utilization. The wide-coverage panel (c) records the retained 195-site warm-start incumbent; no improved integer solution was verified within the 300 s budget. The panels compare verified incumbents and should not be read as a certified efficiency-equity frontier.
3.6 Baseline and sensitivity analysis
At the same 195-site budget, deterministic MCLP-greedy achieves 97.05% nominal geometric coverage, but capacity-feasible delivery is only 63.87%. Its average distance is 1.411 km, average utilization is 54.60%, and minimum utilization is 8.17%. The high-coverage CFLP delivers 78.13%, shortens average distance to 0.953 km, and raises average utilization to 66.79%. This comparison quantifies the difference between geometric coverage and deliverable service rather than treating MCLP as an incorrectly solved version of the same objective.
A no-floor CFLP delivers 78.15% and opens 199 sites, but permits minimum utilization of 1.58%; the 10% floor delivers only 29 fewer orders while using four fewer sites and raising minimum utilization to 22.50%. Separately, land-use coefficient contrast factors 0.5, 1.0, and 1.5 preserve the 195-site set and produce delivery rates of 77.98%, 78.13%, and 78.24%. These structured tests support local robustness but do not replace calibration with observed orders.
4. Discussion
4.1 Fundamental necessity of the CFLP framework
The central methodological contribution of this study is providing rigorous empirical evidence for the fundamental necessity of capacity constraints in vertiport location modeling. MCLP’s exclusive focus on “whether covered” is inadequate for heavy-asset facilities where throughput limits are physically real and commercially binding. The same-budget comparison confirms the distinction: MCLP-greedy reports 97.05% nominal geometric coverage but only 63.87% capacity-feasible delivery, whereas the high-coverage CFLP incumbent delivers 78.13%. Forty-five of its 195 stations operate at full capacity, showing that the ceiling is binding in the reported solution.
The utilization floor is not presented as an algebraically unprecedented constraint. Its application value is to make minimum viable use explicit for capital-intensive vertiports while jointly allocating demand under station ceilings. The no-floor comparison shows that the 10% floor removes four very low-load sites at a delivery loss of only 29 orders.
The theoretical significance of the utilization floor extends beyond vertiport siting. In any heavy-asset logistics infrastructure, distribution centers, cold chain hubs, intermodal terminals, the same structural tension exists between coverage ambition and commercial viability. The floor constraint formalizes the managerial intuition that “a facility that cannot cover its operating costs should not be built,” transforming it from an implicit heuristic into an explicit, tunable optimization constraint. By parameterizing the floor through α, planners can systematically explore the boundary between commercially sustainable and subsidy-dependent station networks, a capability that has direct implications for public-private partnership contract design.
4.2 Algorithmic contribution and practical scalability
The adaptive spatial dimensionality reduction algorithm addresses a scalability barrier that has limited prior CFLP applications to small or synthetic city instances. The operational premise is that the K threshold should be differentiated by local demand intensity. High-demand grids face capacity competition, requiring access to a richer candidate pool; low-demand grids are typically served by the single nearest viable station, making a smaller pool adequate. For Nanjing, the rule reduces 2,678,898 radius-feasible pairs to 374,873 pairs. This is a heuristic restriction and is not claimed to preserve the global optimum.
The algorithm’s determinism, in contrast to stochastic metaheuristics, is a significant practical advantage in infrastructure planning contexts where reproducibility and regulatory auditability are paramount. Municipal governments and regulatory agencies can verify that the same input data and parameters always yield the same station network, supporting transparent accountability in public infrastructure investment decisions.
The generalizability of this algorithmic approach deserves emphasis. While the Nanjing case study provides empirical validation, the underlying principle, demand-adaptive variable compression, is transferable to any city where demand spatial heterogeneity exists. Metropolitan areas with polycentric structures (e.g., Chengdu, Wuhan, Hangzhou in China; Jakarta, Bangkok, Mumbai in Southeast and South Asia) would benefit particularly, as their demand gradients create the same high-competition vs. low-competition spatial dichotomy that motivates adaptive thresholds. Cities with more uniform demand distributions would see less benefit from adaptive differentiation, but the algorithm would still perform at least as well as uniform truncation. The framework’s reliance on publicly available data sources, WorldPop population rasters and OpenStreetMap land use classifications, further enhances its replicability across geographic contexts without requiring proprietary datasets.
4.3 Policy implications: The efficiency–equity trade-off
Figure 11 compares the verified policy and model outcomes between economic efficiency (average station utilization) and spatial equity (coverage rate) across a grid of parameter combinations, with the three main scenarios highlighted as labeled points. Baseline combines 35.31% delivery with 99.76% average utilization, whereas the high-coverage incumbent combines 78.13% delivery with 66.79% average utilization. The scenario parameters (αs, α, coverage bonus) have direct analogs in standard regulatory instruments: a reduction in αs corresponds to a capital subsidy or discounted land lease; a reduction in α corresponds to a relaxed utilization performance standard; and the coverage bonus corresponds to a per-grid franchise obligation. The plotted outcomes are evaluated baselines or time-limited incumbents rather than a certified Pareto frontier.
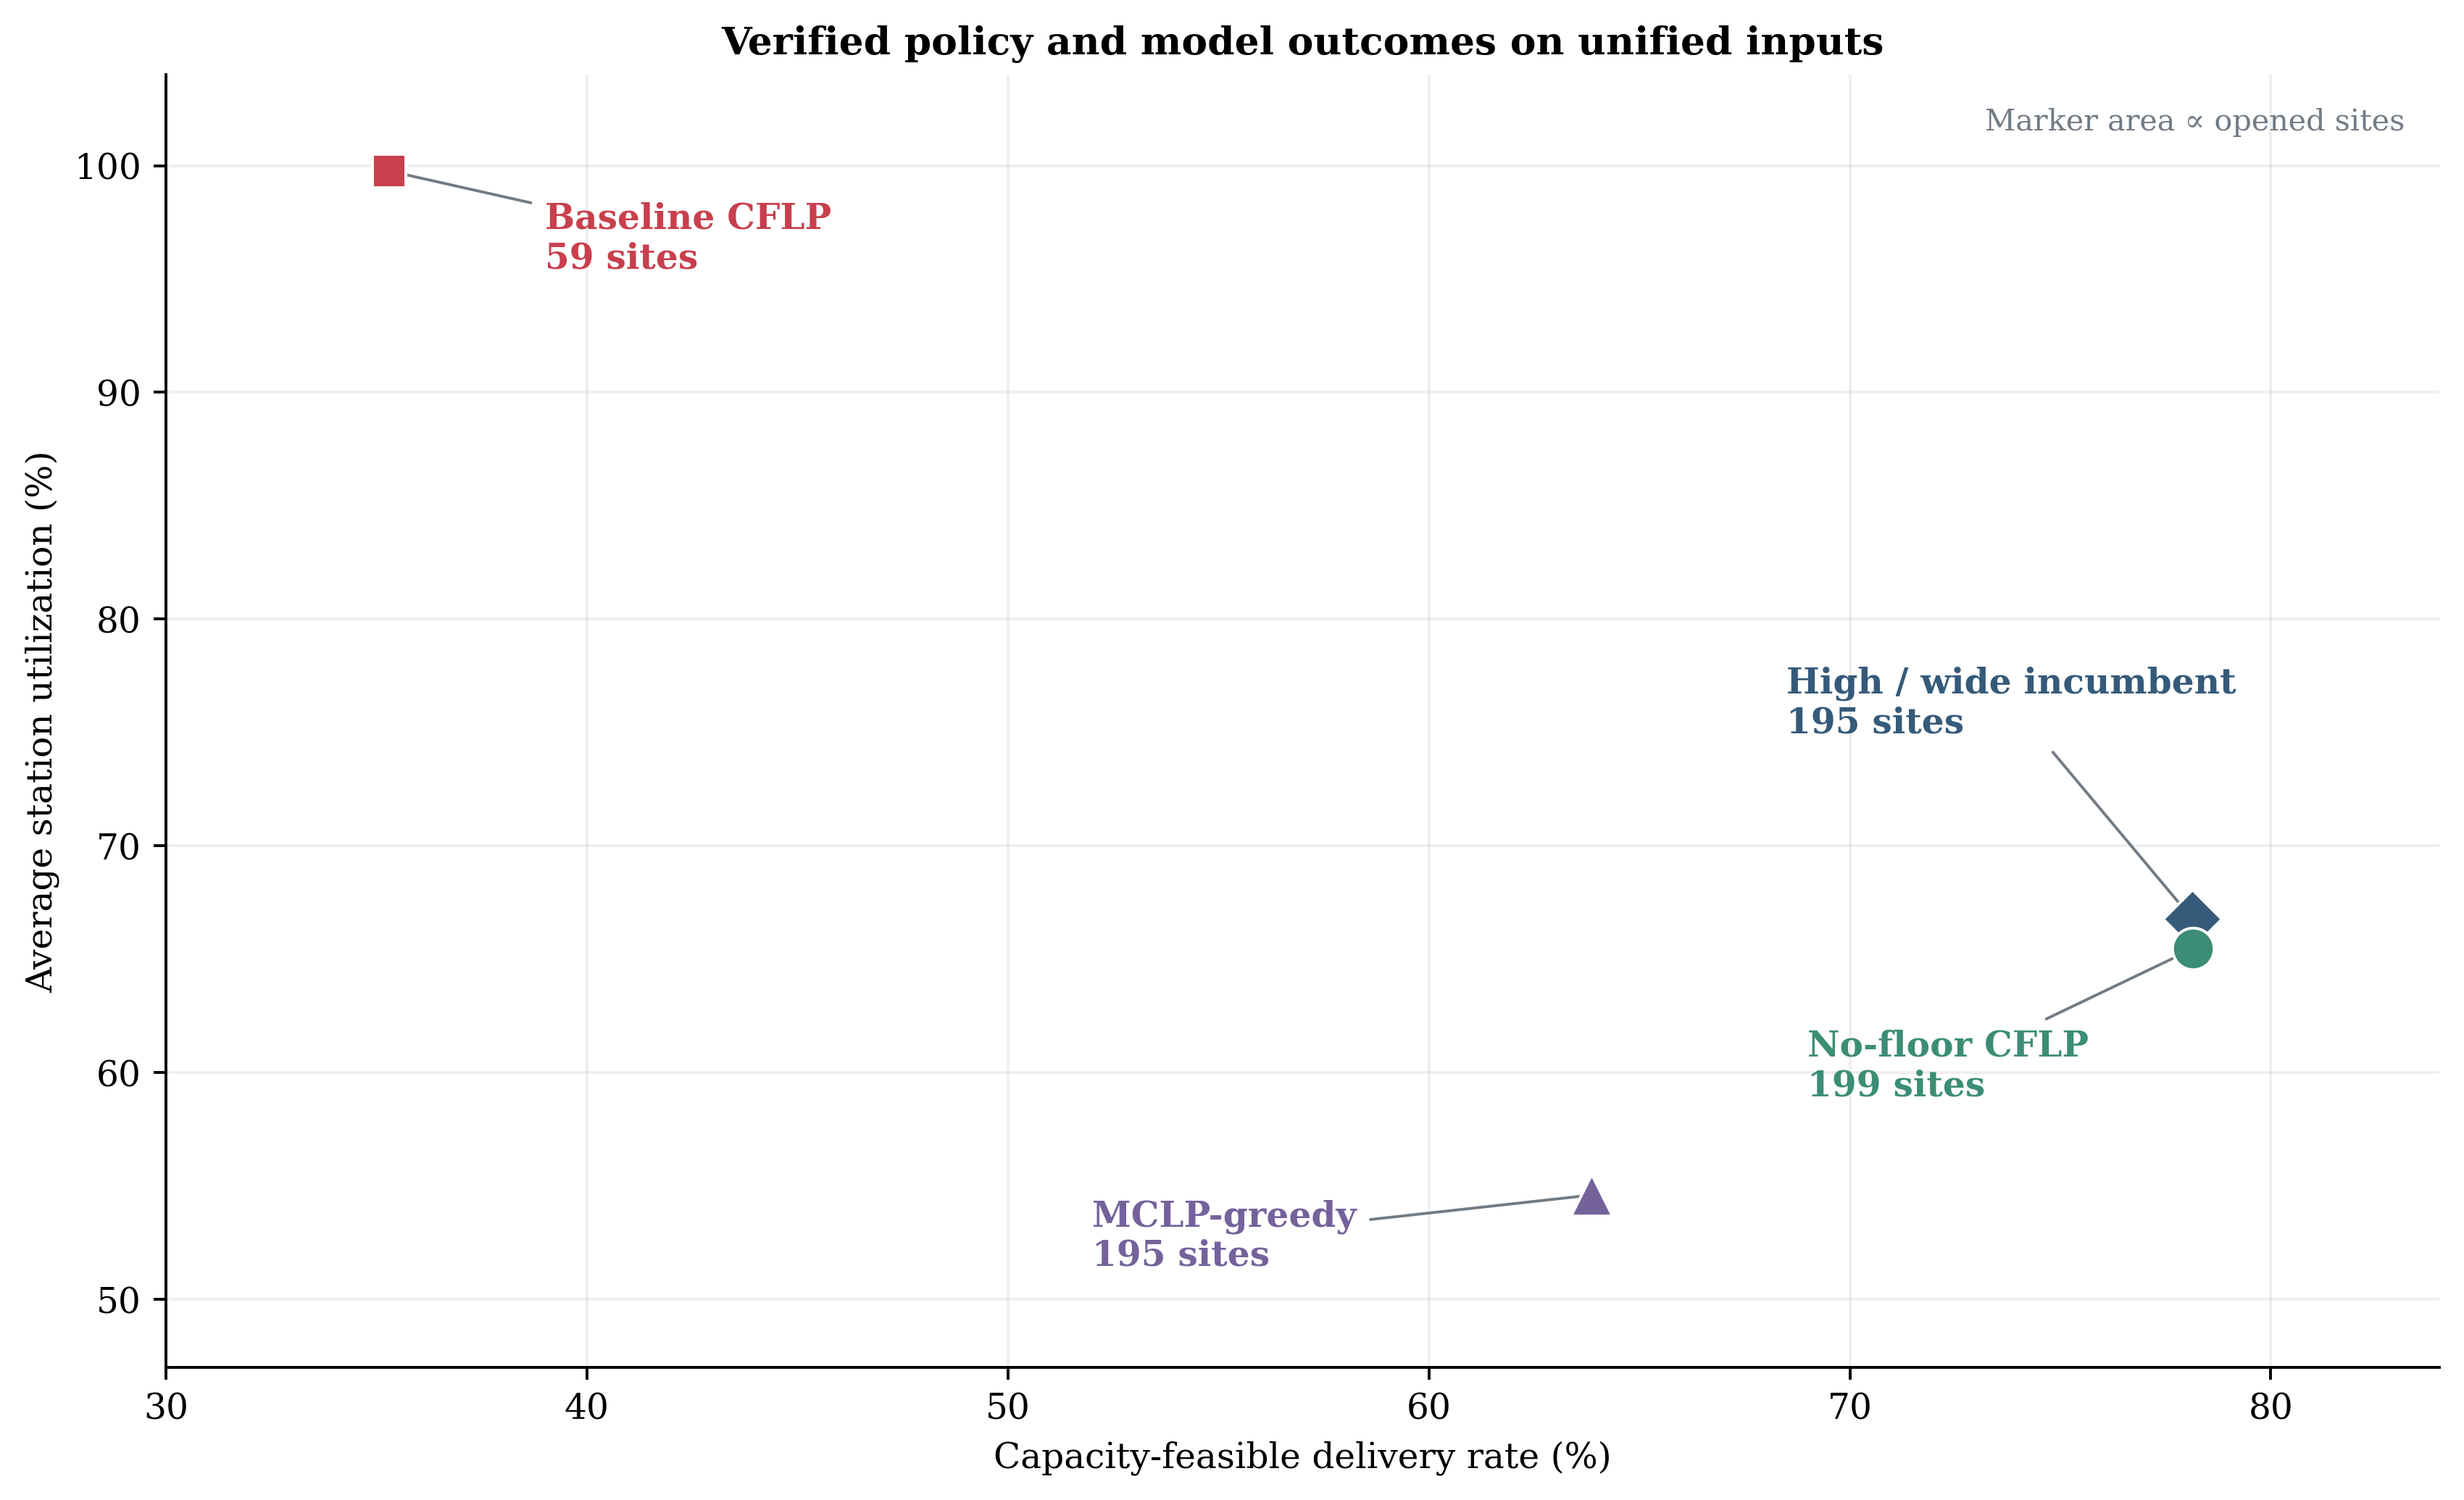
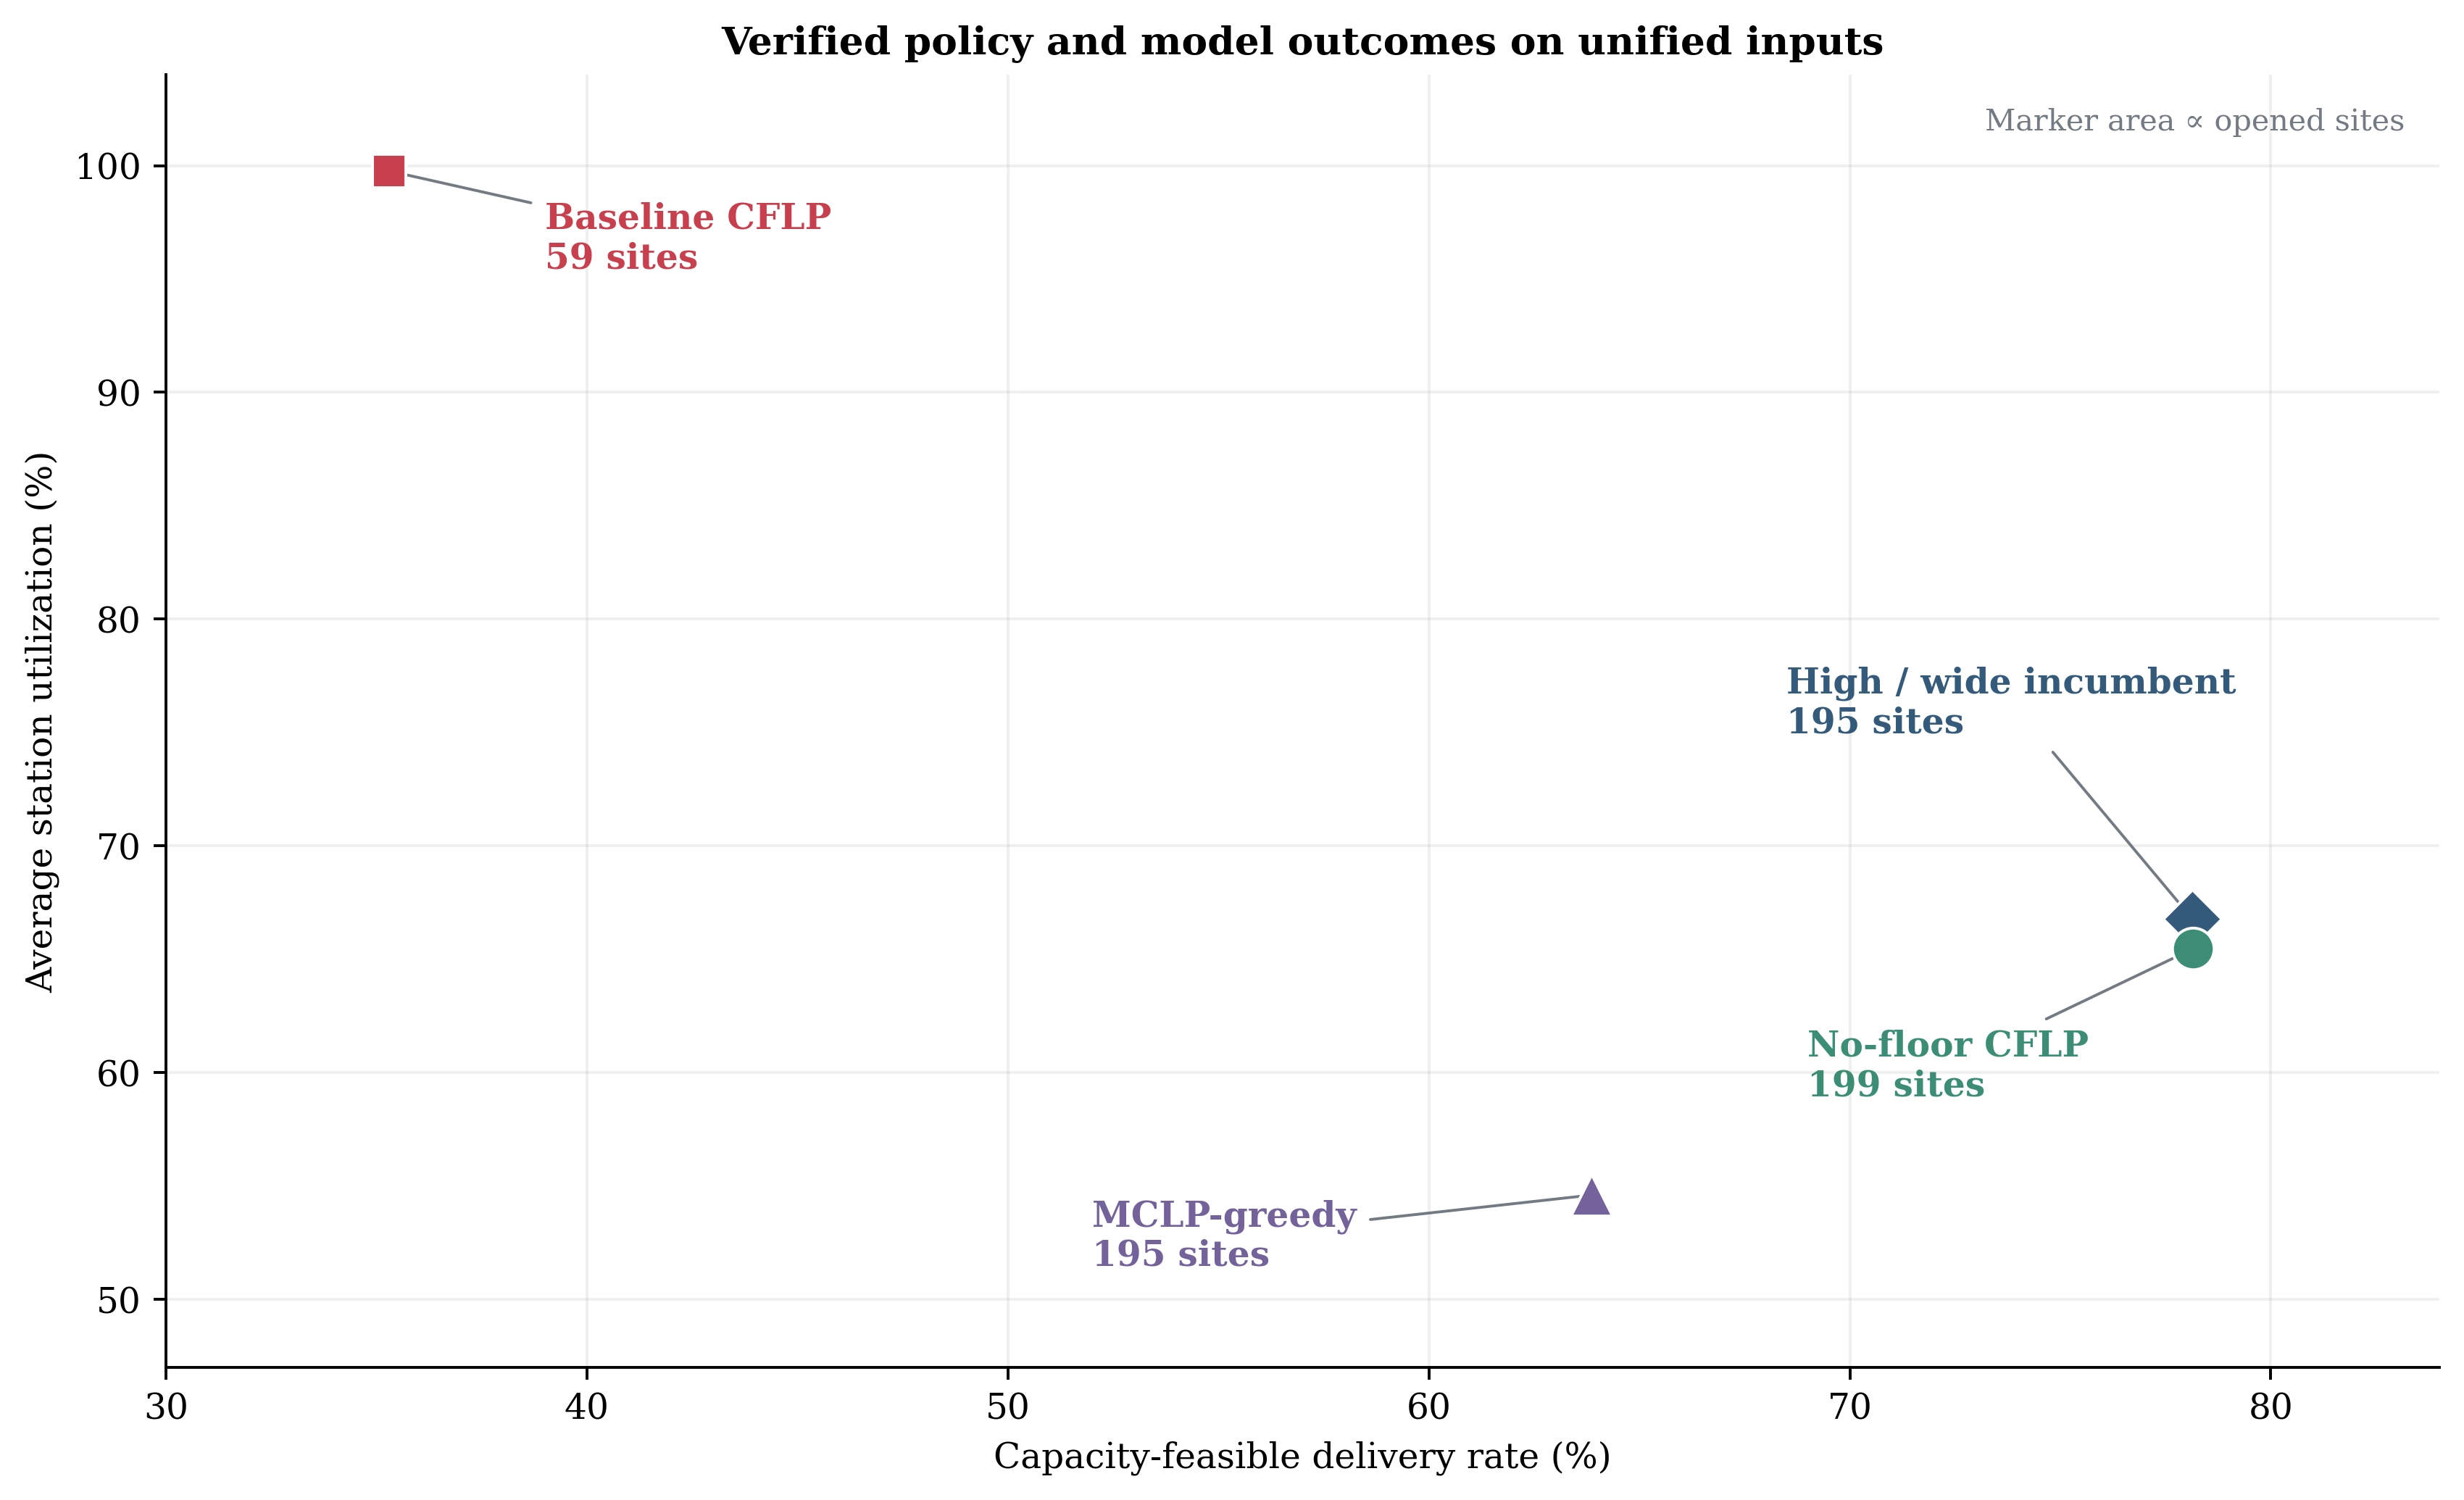
Figure 11. Policy trade-off frontier: economic efficiency vs. spatial equity. CFLP: capacitated facility location problem; MCLP: maximum coverage location problem.
This framework provides city governments with a quantitative instrument for structuring public-private partnerships. By mapping model parameters to regulatory instruments, the framework enables quantitative negotiation between regulators and operators: how much subsidy is needed to achieve a target coverage rate, and what is the resulting utilization trade-off? The finding that all scenario transitions require only parameter adjustment without model reconstruction further enhances the framework’s practical value as an iterative policy design tool.
The policy implications extend to several concrete regulatory mechanisms. First, the αs parameter directly maps to subsidy design: a government seeking to expand capacity-feasible delivery from the baseline 35.31% to the high-coverage 78.13% can estimate the required reduction in effective establishment costs and calibrate capital grants or discounted land leases accordingly. Second, the α parameter maps to franchise agreement terms: a regulator can specify a minimum utilization threshold in concession contracts, ensuring that publicly subsidized stations maintain commercial viability rather than becoming stranded assets. Third, the coverage bonus parameter enables explicit spatial equity mandates: municipalities can attach bonus payments to service in designated underserved zones, converting the social objective of spatial equity into a quantifiable incentive within the operator’s optimization problem. These parameter-to-instrument mappings transform the MILP framework from an academic model into a practical negotiation tool that speaks the language of public finance and concession management. These mappings identify possible instruments only. The experiment uses normalized objective weights, which must be calibrated with local construction, lease, energy, labor, revenue, and verified-order data before they can be expressed as monetary subsidy or contract values.
4.4 Limitations and future research directions
First, the spatial measurement remains two-dimensional. Future work should integrate oblique photogrammetry and CIM to incorporate three-dimensional airspace clearance and rooftop structural constraints into candidate generation. Real-world vertiport siting must account for building height restrictions, approach/departure corridors, and noise exposure contours, factors that a 2D model cannot capture. Second, the demand model is static and deterministic; extending toward multi-period or stochastic programming formulations would improve robustness to demand uncertainty and enable peak demand planning. The low-altitude logistics market is evolving rapidly, and demand patterns may shift substantially as technology matures and consumer adoption accelerates. A rolling-horizon formulation that periodically re-optimizes the station network as demand data accumulates would enhance practical applicability. Third, the model assumes a homogeneous drone fleet; incorporating heterogeneous aircraft types with different payload capacities, range profiles, and operating costs would enrich operational realism. Fourth, inter-station routing and relay logistics are not modeled; for very large metropolitan areas, a hub-and-spoke or multi-tier network architecture may outperform the single-tier structure assumed here. Future work could explore hierarchical facility location models that jointly optimize primary vertiports and secondary relay stations. The added engineering interface can apply roof-area, structural-load, building-height, and takeoff/landing-clearance thresholds when BIM, CIM, or survey attributes are available; the current 53,435 OSM footprints lack those fields, so the reported candidates remain planning-level. In addition, CBC leaves nonzero metropolitan optimality gaps within 300 s. Future work should therefore combine the already identified fleet and temporal extensions with stronger solvers, decomposition, obstacle-aware routes, and observed order calibration.
5. Conclusion
This study addresses the vertiport location and capacity allocation problem for urban low-altitude logistics by proposing a three-stage collaborative optimization framework and conducting an empirical study using Nanjing. Three principal conclusions emerge.
(1) Theory and modeling. Incorporating throughput ceilings and utilization floors into the location model (CFLP) is fundamentally necessary and produces qualitatively superior network designs relative to the capacity-blind MCLP. The utilization floor, used here as an application-specific minimum-throughput rule, operationalizes the commercial viability requirement for heavy-asset vertiport investment. At the same 195-site budget, capacity-feasible delivery is 78.13% for the reported CFLP incumbent and 63.87% for MCLP-greedy, confirming that geometric coverage and deliverable service are not equivalent.
(2) Algorithm and computation. The adaptive spatial dimensionality reduction algorithm addresses the scalability challenge limiting prior CFLP applications to small instances. By differentiating the neighbor pool size by local demand intensity (Khigh = 55, Kbase = 35), it reduces 2,678,898 radius-feasible pairs to 374,873. The resulting networks are deterministic, verified feasible incumbents, but the nonzero solver gaps and heuristic pruning preclude a claim of exact optimality.
(3) Spatial patterns and policy. The empirical study reveals pronounced supply-demand spatial heterogeneity: the urban core exhibits a capacity crowding-out effect, whereas outer suburbs exhibit an aggregation coverage pattern. The verified outcome comparison (Figure 11) relates delivery performance to average station utilization, providing city planners with a quantitative instrument for negotiating subsidies, franchise obligations, and utilization standards, while normalized parameters still require local monetary and contractual calibration.
Looking forward, the proposed framework is positioned to serve as a foundational planning tool as urban low-altitude logistics transitions from pilot programs to commercial-scale deployment. The modular three-stage architecture allows each component to be independently upgraded, for example, replacing the static demand model with real-time order data as it becomes available, or extending the 2D candidate generation to 3D airspace-aware siting, without restructuring the overall methodology. As cities worldwide accelerate their low-altitude economy strategies, the ability to quantitatively simulate the infrastructure consequences of different regulatory choices will be essential for evidence-based policymaking. The framework demonstrated in this study provides such a capability, bridging the gap between academic optimization models and the practical needs of urban infrastructure governance.
Acknowledgments
The authors acknowledge the use of WorldPop population raster data, OpenStreetMap geographic data (OSM Overpass API and OSMnx), the PuLP modeling library, and the CBC COIN-OR solver. OpenAI Codex (GPT-5) was used for English-language proofreading and editing; the authors retain full responsibility for scientific accuracy and integrity.
Authors contribution
Wang D: Conceptualization, methodology, software, data curation, formal analysis, visualization, writing-original draft.
Xu Z: Supervision, validation, resources, funding acquisition, writing-review & editing.
Both authors have read and approved the final version of the manuscript.
Conflicts of interest
Zhao Xu is a Youth Editorial Board Member of Journal of Building Design and Environment. The other author declares no conflicts of interest.
Ethical approval
Not applicable.
Consent to participate
Not applicable.
Consent for publication
Not applicable.
Availability of data and materials
The population density data used in this study are publicly available from the WorldPop project (https://www.worldpop.org/). Land use and administrative boundary data were retrieved from OpenStreetMap (https://www.openstreetmap.org/) via the Overpass API and OSMnx. The optimization code and processed datasets can be obtained from the corresponding author upon reasonable request.
Funding
The study was supported by the National Key Research and Development Program of China (Grant NO. 2022YFC3803600).
Copyright
© The Author(s) 2026.
References
-
1. State Council of the People’s Republic of China. Report on the Work of the Government [Internet]. 2024. Available from: https://www.ndrc.gov.cn/fzggw/jgsj/zys/sjdt/202403/t20240320_1365089.html
-
2. Federal Aviation Administration. Advanced air mobility implementation plan, Version 1.0 [Internet]. Washington, DC: Federal Aviation Administration; 2023. Available from: https://www.faa.gov/air-taxis/implementation-plan
-
3. European Commission. A drone strategy 2.0 for a smart and sustainable unmanned aircraft Eco-system in Europe. COM(2022) 652 final [Internet]. Brussels: European Commission; 2022. Available from: https://eur-lex.europa.eu/legal-content/EN/TXT/?uri=CELEX%3A52022DC0652
-
4. Civil Aviation Authority of Singapore. Asia-Pacific reference materials for regulators to facilitate advanced air mobility operations, Version 1.0 [Internet]. Singapore: CAAS; 2025. Available from: https://www.caas.gov.sg/docs/default-source/docs---cc/asia-pacific-reference-materials-for-regulators-to-facilitate-aam-operations.pdf
-
5. Ministry of Land, Infrastructure and Transport. UAM experts gather in South Korea for the UAM Grand Challenge Korea [Internet]. Sejong: Ministry of Land, Infrastructure and Transport; 2022. Available from: https://www.molit.go.kr/english/USR/BORD0201/m_28286/DTL.jsp?id=eng_mltm_new&idx=3011&mode=view
-
6. Federal Aviation Administration. Engineering brief No. 105A: Vertiport design, supplemental guidance to AC 150/5390-2D, heliport design. Washington, DC: Federal Aviation Administration; 2024. Available from: https://www.faa.gov/airports/engineering/engineering_briefs/eb_105a_vertiports?utm_source=chatgpt.com
-
7. European Union Aviation Safety Agency. Prototype technical design specifications for vertiports [Internet]. Cologne: European Union Aviation Safety Agency. 2022. Available from: https://www.easa.europa.eu/en/document-library/general-publications/prototype-technical-design-specifications-vertiports
-
8. Zhang MY, Jiang B. Comprehensive analysis and prospect of UAVs landing site selection. High Technol Commer. 2025;31(4):27-30.[DOI]
-
9. Zhang HH, Feng DK, Zhang XW, Liu H, Zhong G, Zhang LD. Urban logistics unmanned aerial vehicle vertiports layout planning. J Transp Syst Eng Inf Technol. 2022;22(3):207-214.[DOI]
-
10. Church R, ReVelle C. The maximal covering location problem. Pap Reg Sci Assoc. 1974;32(1):101-118.[DOI]
-
11. Xue Q, Jiang Y, Feng Y, Shao Y. Research on the location selection of hierarchical vertiports for UAVs in low-altitude logistics. J South China Univ Technol (Nat Sci Ed). 2026;54(6):29-41.[DOI]
-
12. Yang JT, Li ZP. Optimization of location selection for maximum coverage of urban drone landing and takeoff sites based on spatially continuous demand. Sci Technol Eng. 2025;25(11):4793-4800.[DOI]
-
13. Kim SH, Park BT, Chae M, Shim S, Kim H. Optimal vertiport locations for air taxi services in Seoul metropolitan area. Int J Aeronaut Space Sci. 2025;26(3):1293-1308.[DOI]
-
14. Liu X, Le M, Liu Y, Hu M. SPID: A deep reinforcement learning-based solution framework for siting low-altitude takeoff and landing facilities. Front Inf Technol Electron Eng. 2025;26(12):2397-2420.[DOI]
-
15. Guo Y, Yao J, Jiang J, Qiao D. Research of hierarchical vertiport location based on Lagrange relaxation. Aerospace. 2025;12(8):672.[DOI]
-
16. Li A, Hansen M, Zou B. Traffic management and resource allocation for UAV-based parcel delivery in low-altitude urban space. Transp Res Part C Emerg Technol. 2022;143:103808.[DOI]
-
17. Jiang H, Wang J, Ren X. Location-route planning for VTOL airport and UAV urban logistics network-a case study of Tianjin. Promet Traffic Transp. 2025;37(2):456-476.[DOI]
-
18. Kitthamkesorn S, Chen A. Maximum capture problem for urban air mobility network design. Transp Res Part E Logist Transp Rev. 2024;187:103569.[DOI]
-
19. Pirkul H, Jayaraman V. A multi-commodity, multi-plant, capacitated facility location problem: Formulation and efficient heuristic solution. Comput Oper Res. 1998;25(10):869-878.[DOI]
-
20. Chouksey A, Agrawal AK, Tanksale AN. A hierarchical capacitated facility location-allocation model for planning maternal healthcare facilities in India. Comput Ind Eng. 2022;167:107991.[DOI]
-
21. Gollowitzer S, Gendron B, Ljubić I. A cutting plane algorithm for the capacitated connected facility location problem. Comput Optim Appl. 2013;55(3):647-674.[DOI]
-
22. Petit V, Ribeiro M. Multi-objective vertiport location optimization for a middle-mile package delivery framework: Case study in the South Holland Region. J Air Transp Manag. 2025;125:102757.[DOI]
-
23. Yang HY, Li YF, Duan MZ. UAV landing site location and path planning for urban logistics. Sci Technol Eng. 2025;25(28):12130-12138.[DOI]
-
24. Dai L, Tian Y, Zhang N, Wan L, Hai S. Research on real-path-based UAV distribution center layout in urban environments. Aerospace. 2025;12(8):703.[DOI]
Copyright
© The Author(s) 2026. This is an Open Access article licensed under a Creative Commons Attribution 4.0 International License (https://creativecommons.org/licenses/by/4.0/), which permits unrestricted use, sharing, adaptation, distribution and reproduction in any medium or format, for any purpose, even commercially, as long as you give appropriate credit to the original author(s) and the source, provide a link to the Creative Commons license, and indicate if changes were made.
Publisher’s Note
Science Exploration remains a neutral stance on jurisdictional claims in published
maps
and institutional affiliations. The views expressed in this article are solely those
of
the author(s) and do not reflect the opinions of the Editors or the publisher.
Share And Cite


Science Exploration Style
Wang D, Xu Z. Supply-demand matching for vertiport location and capacity allocation optimization in urban low-altitude logistics: A case study of Nanjing. J Build Des Environ. 2026;4:202622. https://doi.org/10.70401/jbde.2026.0042
Tips
Copy completed.
Submit a Manuscript
Author Instructions
Cite this Article
Article Metrics
0
View
0
Download
Cited
Article Updates

 Get citation
Science Exploration Style

Wang D, Xu Z. Supply-demand matching for vertiport location and capacity allocation optimization in urban low-altitude logistics: A case study of Nanjing. J Build Des Environ. 2026;4:202622. https://doi.org/10.70401/jbde.2026.0042
copy
Share Link
copy